
Motor Joint Splitter V3 temp

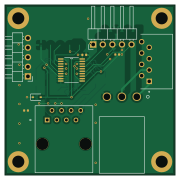
About the Motor Joint Splitter V3 temp PCB
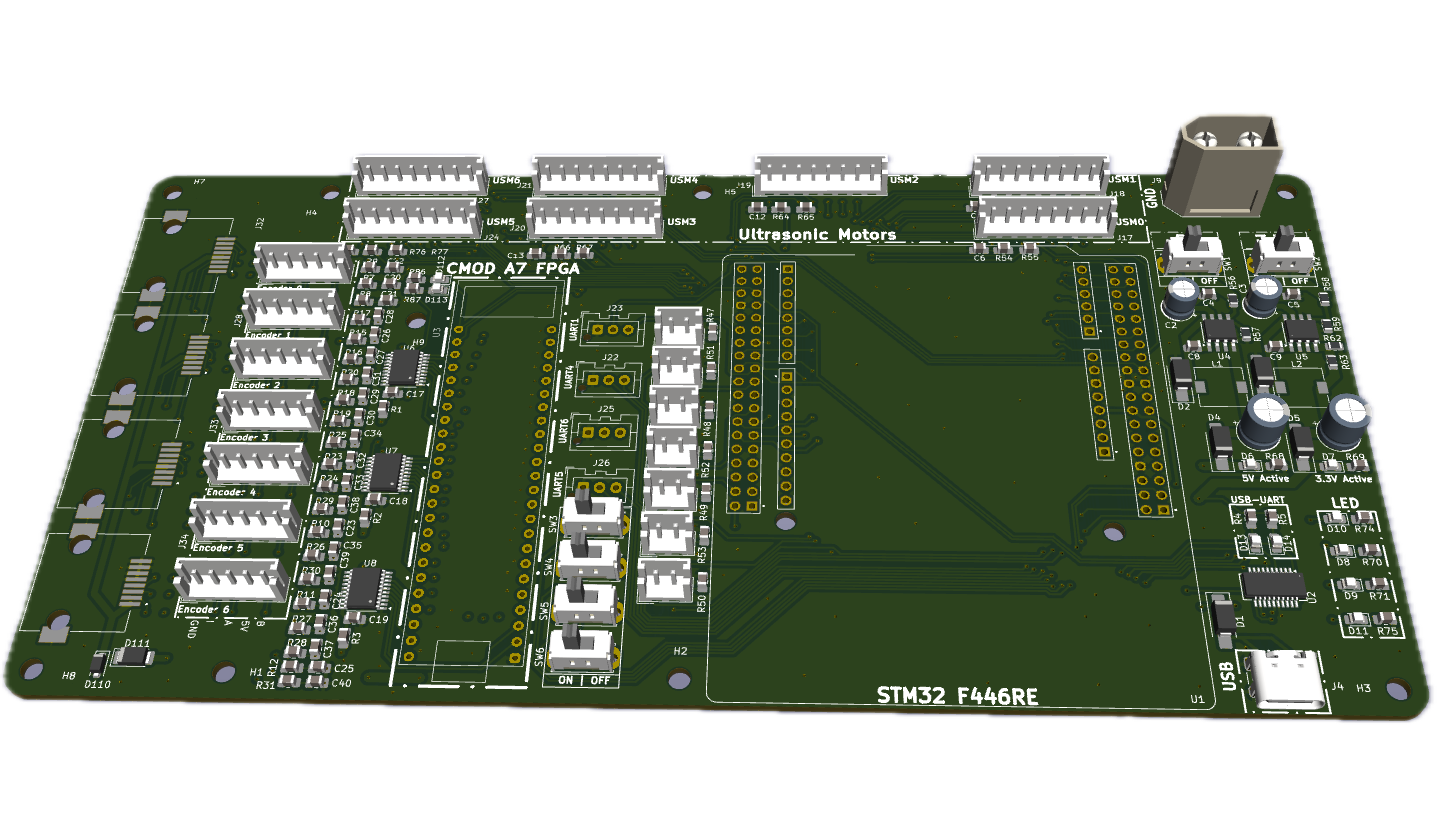
Motor Joint Splitter V3 temp is an open source PCB design by biomimetics, published on GitHub. It is a 2-layer board measuring 45 × 45 mm, with 19 components from 11 distinct parts.
Other key parts include the 74ACT244MTCX. By type, the board carries 6 resistors, 5 connectors, 4 diodes, 3 capacitors and 1 IC.
It belongs with the robotics & motion designs in this gallery.
From the project
PC boards for MRI robogt control, specifically for STM32 motherboard
MainPCB (holds STM32 Nucleo 446RE and FPGA for encoder reading)
PowerPCB (switches for enabling individual ultrasonic motors, +24V in connector, master power switch))
MotorJoint_Splitter (mounted on robot arm)
* Motor Joint Splitter V3 (mounted next to each actuator)
Motorreroute (at motor controller. Splits Tekcelo control signal to use ethernet for a pair of encoders, and 3 wire sin/cos/gnd cable for 250V )
Main components on the Motor Joint Splitter V3 temp
Motor Joint Splitter V3 temp bill of materials (BOM)
19 components, 11 distinct parts — part numbers from the project's BOM.
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 1 | 74ACT244MTCX | line_driver_SOP65P640X120-20N | U2 |
| 1 | Conn_01x05 | PinHeader_1x05_P2.54mm_Horizontal | J1 |
| 1 | 26605030 | CONN_SDA-41792_M450_03_MOL | J2 |
| 1 | motor_connector_292206-8 | TE_292206-8 | J4 |
| 1 | ETHERNET_54602-908LF ethernet_54602-908LF | AMPHENOL_54602-908LF | J7 |
| 1 | CONN_01X05 Conn_01x05 | PinHeader_1x05_P2.54mm_Horizontal | J9 |
| 1 | H5VHD3BC hongjiacheng | D_SOD-323 | D4 |
| 3 | BAT54SDW | SOT-363_SC-70-6 | D5, D6, D7 |
| 1 | 1uF Samsung Electro-Mechanics | C_0402 | C1 |
| 2 | 1UF 1uF Samsung Electro-Mechanics | C_0402 | C3, C4 |
| 6 | 120Ω UNI-ROYAL(Uniroyal Elec) | R_0805 | R13, R14, R15, R16, R17, R19 |
Motor Joint Splitter V3 temp design files
The KiCad project lives in the biomimetics/MRIRobot_PCB repository on GitHub; these links point at the commit this page was built from.
Motor Joint Splitter V3 temp: common questions
How big is the Motor Joint Splitter V3 temp PCB?
The Motor Joint Splitter V3 temp measures 45 × 45 mm, has 2 copper layers and is 1.6 mm thick.
How many components are on the Motor Joint Splitter V3 temp?
19 components, from 11 distinct parts, with part numbers taken from the project's own BOM. The full bill of materials is listed on this page.
Where can I download the Motor Joint Splitter V3 temp design files?
From the biomimetics/MRIRobot_PCB repository on GitHub, which has the KiCad layout and the BOM; the links under Design files point to each one.
Can I use the Motor Joint Splitter V3 temp design in my own project?
The repository has no license, so all rights stay with biomimetics. Use it as a reference, and ask the author before reusing the design.
More boards in MRIRobot_PCB
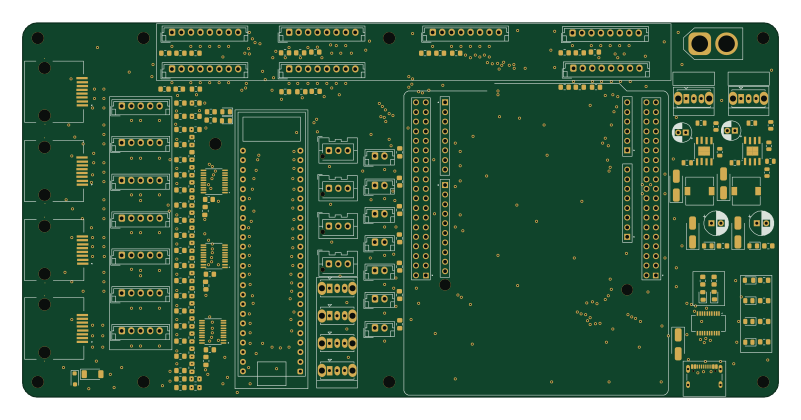
MRIRobot
200 × 99 mm330 parts4LNo license2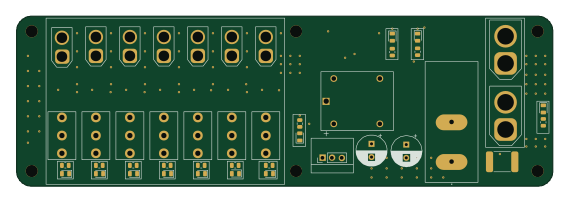
Power
142 × 45 mm58 parts2LNo license2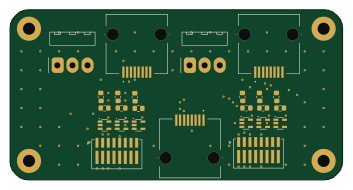
Motor reroute
88 × 45 mm31 parts2LNo license2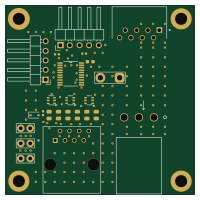
Motor Joint Splitter V3
50 × 50 mm24 parts2LNo license2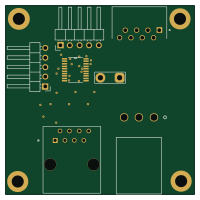
Motor Joint Splitter V3 two side
50 × 50 mm20 parts2LNo license2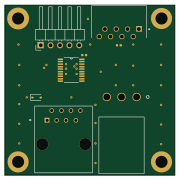
Motor Joint Splitter V2 Set
45 × 45 mm17 parts2LNo license2
Motor Joint Splitter V2 pre tracks
40 × 40 mm15 parts2LNo license2
Motor Joint Splitter V2 backup
40 × 40 mm15 parts2LNo license2
Motor Adapt C
34.5 × 41 mm15 parts2LNo license2
Motor quick connect
42.8 × 46.3 mm4 parts2LNo license2
Motor Adapt M
34.5 × 32.5 mm3 parts2LNo license2
Similar boards
Stack chan
stack-chan
50 × 50 mm33 parts2LApache-2.01.7k
Cube batteryboard
willem-pennings
95 × 95 mm4 parts2LGPL-3.01.1k
Mesabob
rene-dev
87.5 × 50 mm44 parts2LGPL-3.0979
Bob
100 × 100 mm140 parts2LGPL-3.0979
Triple adapter
57 × 75 mm26 parts2LGPL-3.0979
Trollerv2
100 × 75 mm33 parts4LGPL-3.0979