
LSwarm-Drone-Launcher

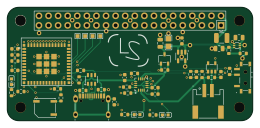
About the LSwarm-Drone-Launcher PCB
LSwarm-Drone-Launcher is an open source ESP32 PCB design by DerpyDoggo11, published on GitHub. It is a 4-layer board measuring 65 × 30 mm, with 51 components from 32 distinct parts.
Its main chip is the ESP32-C3-MINI-1U-N4, from the ESP32 family. Other key parts include the BQ24075RGTR, ZX-PH2.0-WT2P, TPS61023DRLR, DW03C and AP2112K-3.3. By type, the board carries 21 resistors, 14 capacitors, 6 ICs, 3 LEDs, 1 module and 1 transistor.
It belongs with the robotics & motion, power & battery and iot & wireless designs in this gallery.
From the project
For calculating and planning the trajectory of the drones, this launcher uses a Raspbbery Pi Zero 2 W along with a custom Pi hat. The custom Pi hat extends the wifi range of the Raspberry Pi Zero 2 W to communicate with the LS Anchors and adds a battery for independent usage from
For calculating and planning the trajectory of the drones, this launcher uses a Raspbbery Pi Zero 2 W along with a custom Pi hat. The custom Pi hat extends the wifi range of the Raspberry Pi Zero 2 W to communicate with the LS Anchors and adds a battery for independent usage from wall outlets. Only 1 compute module should be necessary per batch of launcher units.
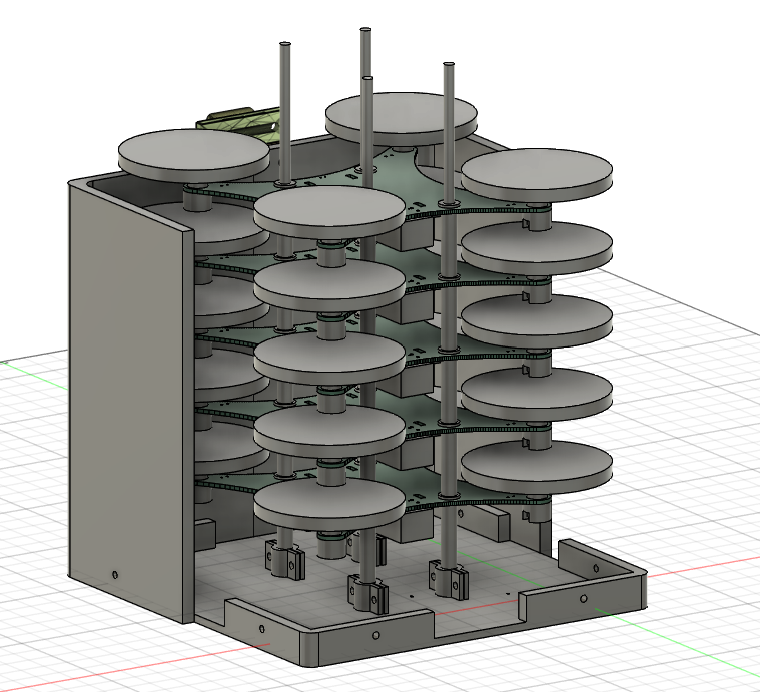
Main components on the LSwarm-Drone-Launcher
LSwarm-Drone-Launcher bill of materials (BOM)
51 components, 32 distinct parts — part numbers from the project's BOM.
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 1 | BQ24075RGTR TI(德州仪器) | QFN-16_L3.0-W3.0-P0.50-TL-EP1.7 | U1 |
| 1 | ZX-PH2.0-WT2P Megastar(兆星) | CONN-SMD_ZX-PH2.0-WT2P | U2 |
| 1 | TPS61023DRLR TI(德州仪器) | SOT-563_L1.6-W1.2-P0.50-LS1.6-BR | U3 |
| 1 | DW03C DW03C_C41367942 PJSEMI(平晶微) | SOT-23-5_L2.9-W1.6-P0.95-LS2.9-BL | U4 |
| 1 | ESP32-C3-MINI-1U-N4 ESPRESSIF(乐鑫) | WIFIM-SMD_61P-L13.2-W12.5-P0.80 | U6 |
| 1 | AP2112K-3.3 | SOT-23-5 | U12 |
| 1 | Raspberry Pi Zero v1.3 | RASPI_ZERO_FULL | A1 |
| 1 | AO3407A AOS | SOT-23-3_L2.9-W1.6-P1.90-LS2.8-BR | Q7 |
| 1 | MLT-5020 华能 | BUZ-SMD_L5.0-W5.5-P4.60 | BUZZER2 |
| 1 | MSK12C02 SHOU HAN(首韩) | SW-TH_MSK12C02 | SW1 |
| 1 | USB-TYPE-C-018 DEALON(德艺隆) | USB-C_SMD-TYPE-C-31-M-12 | USB1 |
| 3 | KT-0603R KENTO | LED-SMD_L1.6-W0.8-R-RD | LED4, LED5, LED6 |
| 1 | USBLC6-2SC6 USBLC6-2SC6_C2687116 UMW(友台半导体) | SOT-23-6_L2.9-W1.6-P0.95-LS2.8-BL | D5 |
| 1 | 2.2UH 2.2uH | L_1210_3225Metric | L5 |
| 1 | CL21A226MAQNNNE SAMSUNG(三星) | C0805 | C1 |
| 1 | 10NF 10nF | C_0603_1608Metric | C27 |
| 5 | 1UF 1uF | C_0603_1608Metric | C31, C32, C41, C52, C65 |
| 2 | 10UF 10uF | C_0603_1608Metric | C40, C55 |
| 1 | 10UF 10uF | C_0805_2012Metric | C42 |
| 1 | 22UF 22uF | C_0805_2012Metric | C43 |
Show 12 more
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 2 | 100NF 100nf | C_0603_1608Metric | C56, C71 |
| 1 | 10uF | C_0805_2012Metric | C71C1 |
| 4 | 1k | R_0603_1608Metric | R9, R21, R24, R29 |
| 1 | 1.5K 1.5k | R_0603_1608Metric | R11 |
| 5 | 10K 10k | R_0603_1608Metric | R12, R18, R23, R32, R33 |
| 1 | 470 | R_0603_1608Metric | R16 |
| 2 | 220K 220k | R_0603_1608Metric | R25, R26 |
| 1 | 100 | R_0603_1608Metric | R27 |
| 2 | 100K 100k | R_0603_1608Metric | R28, R38 |
| 2 | 5.1K 5.1k | R_0603_1608Metric | R34, R37 |
| 2 | 27 | R_0603_1608Metric | R35, R36 |
| 1 | 820K 820k | R_0603_1608Metric | R39 |
LSwarm-Drone-Launcher design files
The KiCad project lives in the DerpyDoggo11/LSwarm-Drone-Launcher repository on GitHub; these links point at the commit this page was built from.
LSwarm-Drone-Launcher: common questions
What microcontroller does the LSwarm-Drone-Launcher use?
The LSwarm-Drone-Launcher is built around the ESP32-C3-MINI-1U-N4, from the ESP32 family.
How big is the LSwarm-Drone-Launcher PCB?
The LSwarm-Drone-Launcher measures 65 × 30 mm, has 4 copper layers and is 1.6 mm thick.
How many components are on the LSwarm-Drone-Launcher?
51 components, from 32 distinct parts, with part numbers taken from the project's own BOM. The full bill of materials is listed on this page.
Where can I download the LSwarm-Drone-Launcher design files?
From the DerpyDoggo11/LSwarm-Drone-Launcher repository on GitHub, which has the KiCad layout, the schematic and the BOM; the links under Design files point to each one.
Can I use the LSwarm-Drone-Launcher design in my own project?
The repository has no license, so all rights stay with DerpyDoggo11. Use it as a reference, and ask the author before reusing the design.
Can I test firmware for the LSwarm-Drone-Launcher without the hardware?
Yes. HardLabs builds a simulation of the board from its netlist and BOM, so you can run and debug ESP32 firmware against it before you order a PCB.
Similar boards
 ESP32
Open Book Abridged Edition
joeycastillo
85 × 115 mm65 parts2LCC-BY-SA-4.08.1k ESP32
Badge
atopile
56.3 × 39 mm239 parts4LMIT4.0k ESP32
Esp32 minimal
36.2 × 26.8 mm20 parts2LMIT4.0k ESP32
Racer
StuckAtPrototype
36 × 50.2 mm70 parts4LApache-2.03.8k ESP32
Controller
29 × 74 mm58 parts4LApache-2.03.8k ESP32
Bitaxe
skot
56.5 × 99.8 mm86 parts4LCERN-OHL-S-2.01.4k