
Hybrid-Controller HC-1

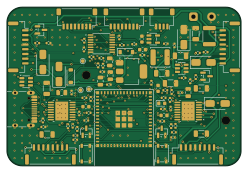
About the Hybrid-Controller HC-1 PCB
Hybrid-Controller HC-1 is an open source ESP32 PCB design by DesignStraub, published on GitHub under the CC-BY-NC-4.0 license. It is a 4-layer board measuring 62 × 42 mm, with 97 components from 42 distinct parts.
Its main chip is the ESP32-S3-MINI-1-N8, from the ESP32 family. Other key parts include the C2071868, AMS1117-3.3, AP2112K-3.3, USBLC6-2SC6 and SN74CBTLV3257PW. By type, the board carries 37 resistors, 28 capacitors, 8 ICs, 8 connectors, 7 diodes and 4 transistors.
It belongs with the robotics & motion and power & battery designs in this gallery.
From the project
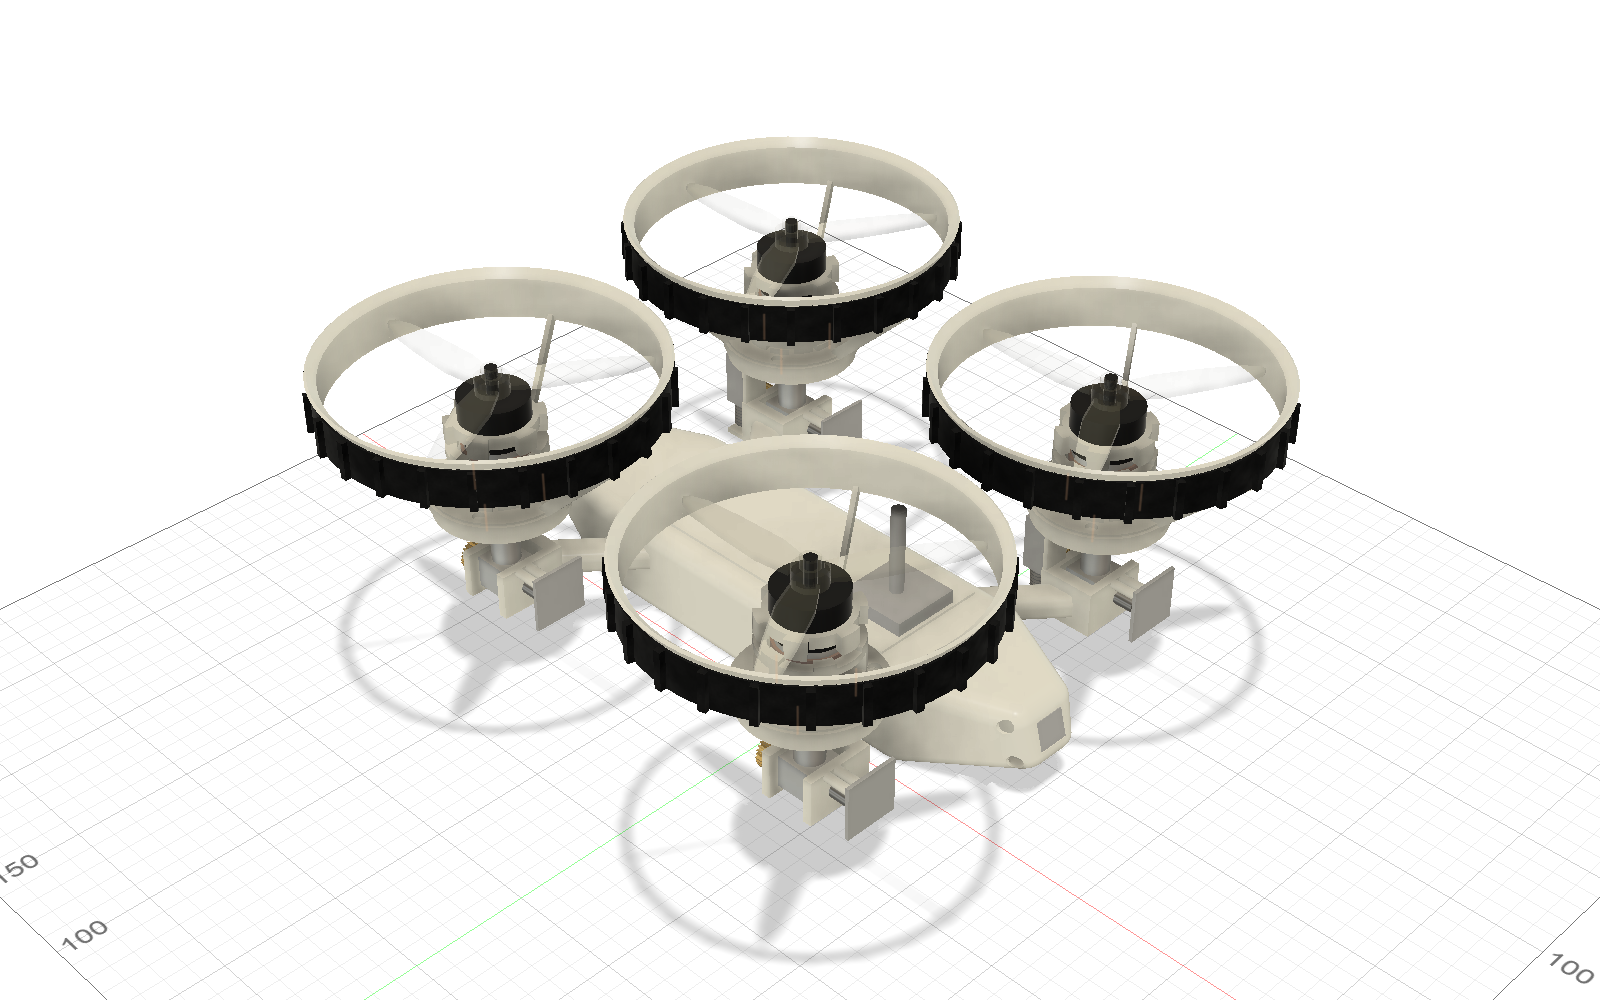
A 5-inch FPV drone whose prop ducts fold down and become wheels. Design study in Fusion 360 and KiCad, CC BY-NC-SA 4.0.
A 5-inch FPV quadcopter that lands, folds its four ducts down by 90° and drives away on them. Each duct ring has a tread and turns into a wheel. The same four motors fly the drone and drive the wheels.
Video: Watch the 55-second walkthrough on YouTube or download it in 16:9 as MP4 (17 MB)
- Folding: Each arm ends in a hinge. A small N20 gear motor turns it through a self-locking brass worm drive (1:30). An AS5600 magnetic sensor reads the angle, and fixed end stops limit the travel to 0° (flight) and 90° (drive). - Ring = wheel: The duct around each 5.1" propeller has a TPU tread and runs…
Main components on the Hybrid-Controller HC-1
Hybrid-Controller HC-1 bill of materials (BOM)
97 components, 42 distinct parts — part numbers from the project's BOM.
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 1 | C2071868 AP63200WU (6,0 V / 2 A) | TSOT-23-6 | U1 |
| 1 | AMS1117-3.3 | SOT-223-3_TabPin2 | U2 |
| 1 | AP2112K-3.3 | SOT-23-5 | U3 |
| 1 | ESP32-S3-MINI-1-N8 | ESP32-S2-MINI-1 | U4 |
| 1 | USBLC6-2SC6 | SOT-23-6 | U5 |
| 1 | SN74CBTLV3257PW | TSSOP-16_4.4x5mm_P0.65mm | U6 |
| 2 | DRV8833PWPR | HTSSOP-16-1EP_4.4x5mm_P0.65mm_EP3.4x5mm_Mask2.46x2.31mm_ThermalVias | U7, U8 |
| 4 | AO3400A | SOT-23 | Q1, Q2, Q3, Q4 |
| 1 | USB-C | USB_C_Receptacle_HRO_TYPE-C-31-M-12 | J2 |
| 1 | C160407 vom FC (ESC-Port) | JST_SH_SM08B-SRSS-TB_1x08-1MP_P1.00mm_Horizontal | J3 |
| 1 | C160407 zum 4-in-1-ESC | JST_SH_SM08B-SRSS-TB_1x08-1MP_P1.00mm_Horizontal | J4 |
| 1 | C160404 FC UART (MSP) | JST_SH_SM04B-SRSS-TB_1x04-1MP_P1.00mm_Horizontal | J5 |
| 1 | C265111 Ecke VL | JST_GH_SM08B-GHS-TB_1x08-1MP_P1.25mm_Horizontal | J6 |
| 1 | C265111 Ecke VR | JST_GH_SM08B-GHS-TB_1x08-1MP_P1.25mm_Horizontal | J7 |
| 1 | C265111 Ecke HL | JST_GH_SM08B-GHS-TB_1x08-1MP_P1.25mm_Horizontal | J8 |
| 1 | C265111 Ecke HR | JST_GH_SM08B-GHS-TB_1x08-1MP_P1.25mm_Horizontal | J9 |
| 1 | 2A hold (Hubmagnete) | Fuse_1812_4532Metric | F1 |
| 1 | RESET | SW_SPST_PTS810 | SW1 |
| 1 | BOOT | SW_SPST_PTS810 | SW2 |
| 1 | gruen | LED_0603_1608Metric | LED1 |
Show 22 more
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 1 | SMAJ20CA | D_SMA | D1 |
| 2 | B5819W | D_SOD-123 | D2, D3 |
| 4 | SS34 | D_SMA | D4, D5, D6, D7 |
| 1 | 10uH 3A (FNR5040S100MT) | L_Changjiang_FNR5040S | L1 |
| 2 | 10uF 35V | C_1206_3216Metric | C1, C2 |
| 1 | 100nF 50V | C_0402_1005Metric | C3 |
| 11 | 100NF 100nF | C_0402_1005Metric | C4, C12, C13, C15, C19, C23, C24, C25 +3 |
| 2 | 22uF 16V | C_1206_3216Metric | C5, C6 |
| 3 | 10uF 16V | C_0805_2012Metric | C7, C18, C22 |
| 1 | 22uF 10V | C_0805_2012Metric | C8 |
| 3 | 1UF 1uF | C_0603_1608Metric | C9, C10, C14 |
| 1 | 10UF 10uF | C_0805_2012Metric | C11 |
| 2 | 10nF 16V | C_0402_1005Metric | C16, C20 |
| 2 | 2.2UF 2.2uF | C_0603_1608Metric | C17, C21 |
| 1 | 64.9k 1% | R_0402_1005Metric | R1 |
| 2 | 10k 1% | R_0402_1005Metric | R2, R37 |
| 13 | 10K 10k | R_0402_1005Metric | R3, R4, R9, R18, R19, R21, R23, R25 +5 |
| 10 | 1k | R_0402_1005Metric | R5, R8, R10, R11, R12, R13, R29, R31 +2 |
| 2 | 5.1K 5.1k | R_0402_1005Metric | R6, R7 |
| 4 | 0.2R 1/4W | R_1206_3216Metric | R14, R15, R16, R17 |
| 4 | 100R | R_0402_1005Metric | R20, R22, R24, R26 |
| 1 | 100k 1% | R_0402_1005Metric | R36 |
Hybrid-Controller HC-1 design files
The KiCad project lives in the DesignStraub/ringwheel-hybrid-drone repository on GitHub; these links point at the commit this page was built from.
Hybrid-Controller HC-1: common questions
What microcontroller does the Hybrid-Controller HC-1 use?
The Hybrid-Controller HC-1 is built around the ESP32-S3-MINI-1-N8, from the ESP32 family.
How big is the Hybrid-Controller HC-1 PCB?
The Hybrid-Controller HC-1 measures 62 × 42 mm, has 4 copper layers and is 1.6 mm thick.
How many components are on the Hybrid-Controller HC-1?
97 components, from 42 distinct parts, with part numbers taken from the project's own BOM. The full bill of materials is listed on this page.
Where can I download the Hybrid-Controller HC-1 design files?
From the DesignStraub/ringwheel-hybrid-drone repository on GitHub, which has the KiCad layout, the schematic and the BOM; the links under Design files point to each one.
Can I use the Hybrid-Controller HC-1 design in my own project?
It is published under CC-BY-NC-4.0, which limits how it may be reused; read the license before building on it.
Can I test firmware for the Hybrid-Controller HC-1 without the hardware?
Yes. HardLabs builds a simulation of the board from its netlist and BOM, so you can run and debug ESP32 firmware against it before you order a PCB.
More boards in ringwheel-hybrid-drone

Similar boards
 ESP32
OSO-BOOK-B1
joeycastillo
85 × 115 mm65 parts2LCC-BY-SA-4.08.1k ESP32
Powertrain
byrantech
64 × 45.4 mm171 parts4LMIT4.3k ESP32
Badge
atopile
56.3 × 39 mm239 parts4LMIT4.0k ESP32
Esp32 minimal
36.2 × 26.8 mm20 parts2LMIT4.0k ESP32
Controller
StuckAtPrototype
29 × 74 mm58 parts4LApache-2.03.8k ESP32
Racer
36 × 50.2 mm70 parts4LApache-2.03.8k