
Unflying-Fish

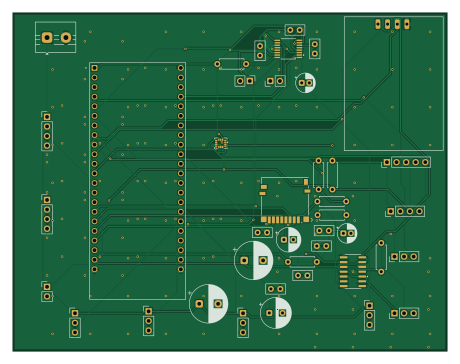
About the Unflying-Fish PCB
Unflying-Fish is an open source ESP32 PCB design by DinosaurPotato534, published on GitHub. It is a 2-layer board measuring 114.9 × 89.5 mm, with 41 components from 29 distinct parts.
Its main chip is the ESP32-S3-DEVKITC-1-N16R8V, from the ESP32 family. Other key parts include the LSM6DSOTR, 74AHCT125S14-13 and DRV8833PW. By type, the board carries 15 connectors, 14 capacitors, 7 resistors, 4 ICs and 1 battery holder.
It belongs with the robotics & motion, rf & radio and iot & wireless designs in this gallery.
From the project
A flying fish that doesn't fly
The main goal of the project was to create a full autonomous underwater vehicle capable of traveling below the surface with no signal. Water completely blocks out both GPS and WIFI, so we will have no connection at all once it submerges below the surface. Thus, the submarine can use gps to navigate above water to various waypoints and use dead-reckoning when navigating underwater.
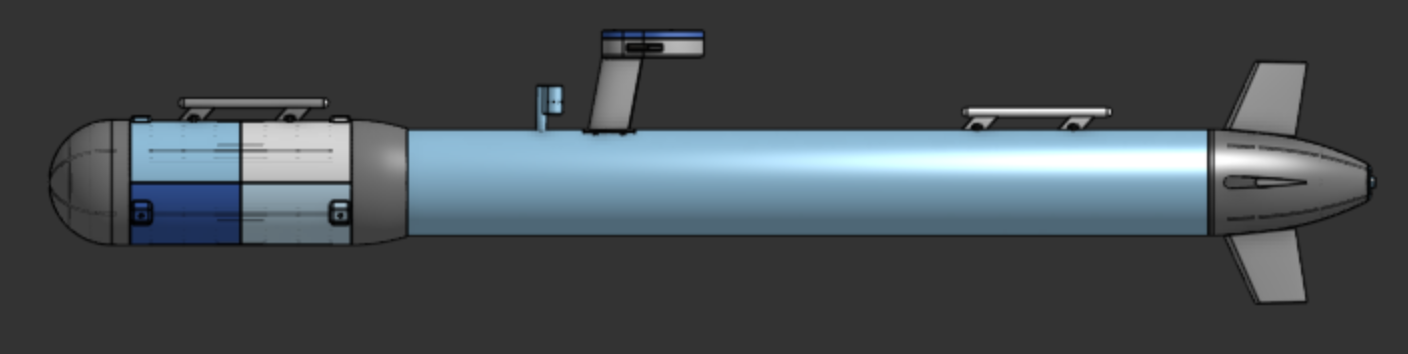
Main components on the Unflying-Fish
Unflying-Fish bill of materials (BOM)
41 components, 29 distinct parts — part numbers from the project's BOM.
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 1 | ESP32-S3-DEVKITC-1-N16R8V | ESP32-S3-DEVKITC-1-N16R8V | U1 |
| 1 | LSM6DSOTR | LSM6DSOTR | U2 |
| 1 | 74AHCT125S14-13 | 74AHCT125S14-13 | U3 |
| 1 | DRV8833PW | PW16_TEX | U4 |
| 1 | GY-NEO6MV2 (GPS) | GY-GPS6MV2 | J1 |
| 1 | SS49E (Hall Effect Sensor) | PinHeader_1x03_P2.54mm_Vertical | J2 |
| 1 | MMC5603 (IMU) | PinHeader_1x05_P2.54mm_Vertical | J3 |
| 1 | GY-MS5837 (MAGENTOMETER) | PinHeader_1x04_P2.54mm_Vertical | J4 |
| 1 | ESC CAN | PinHeader_1x02_P2.54mm_Vertical | J5 |
| 1 | motor2 | PinHeader_1x02_P2.54mm_Vertical | J6 |
| 1 | motor1 | PinHeader_1x02_P2.54mm_Vertical | J7 |
| 4 | SERVO | PinHeader_1x03_P2.54mm_Vertical | J8, J9, J10, J11 |
| 1 | NEOPIXEL | PinHeader_1x03_P2.54mm_Vertical | J12 |
| 1 | DM3D-SF | CONN8_DM3D-SF_HIR | J13 |
| 1 | LM2596S (buck converter) | PinHeader_1x04_P2.54mm_Vertical | J14 |
| 1 | XL4016 (Buck Converter for Servos) | PinHeader_1x04_P2.54mm_Vertical | J15 |
| 1 | Battery | TerminalBlock_MaiXu_MX126-5.0-02P_1x02_P5.00mm | BT2 |
| 1 | 100uF | CP_Radial_D6.3mm_P2.50mm | C1 |
| 5 | 100nF | C_Disc_D5.0mm_W2.5mm_P2.50mm | C2, C5, C6, C7, C9 |
| 1 | 470uF C | CP_Radial_D8.0mm_P3.50mm | C3 |
Show 9 more
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 2 | 1000uF | CP_Radial_D10.0mm_P5.00mm | C4, C10 |
| 1 | 4.7uF | CP_Radial_D5.0mm_P2.00mm | C8 |
| 1 | 0.1uF | C_Disc_D5.0mm_W2.5mm_P2.50mm | C11 |
| 1 | 10nF | C_Disc_D5.0mm_W2.5mm_P2.50mm | C12 |
| 1 | 2.2uF | C_Disc_D5.0mm_W2.5mm_P2.50mm | C13 |
| 1 | 10uF | CP_Radial_D5.0mm_P2.00mm | C14 |
| 2 | 4.7K | R_Axial_DIN0207_L6.3mm_D2.5mm_P7.62mm_Horizontal | R1, R2 |
| 4 | 10k | R_Axial_DIN0207_L6.3mm_D2.5mm_P7.62mm_Horizontal | R3, R4, R5, R8 |
| 1 | 330 | R_Axial_DIN0207_L6.3mm_D2.5mm_P7.62mm_Horizontal | R6 |
Unflying-Fish design files
The KiCad project lives in the DinosaurPotato534/Unflying-Fish repository on GitHub; these links point at the commit this page was built from.
Unflying-Fish: common questions
What microcontroller does the Unflying-Fish use?
The Unflying-Fish is built around the ESP32-S3-DEVKITC-1-N16R8V, from the ESP32 family.
How big is the Unflying-Fish PCB?
The Unflying-Fish measures 114.9 × 89.5 mm, has 2 copper layers and is 1.6 mm thick.
How many components are on the Unflying-Fish?
41 components, from 29 distinct parts, with part numbers taken from the project's own BOM. The full bill of materials is listed on this page.
Where can I download the Unflying-Fish design files?
From the DinosaurPotato534/Unflying-Fish repository on GitHub, which has the KiCad layout, the schematic and the BOM; the links under Design files point to each one.
Can I use the Unflying-Fish design in my own project?
The repository has no license, so all rights stay with DinosaurPotato534. Use it as a reference, and ask the author before reusing the design.
Can I test firmware for the Unflying-Fish without the hardware?
Yes. HardLabs builds a simulation of the board from its netlist and BOM, so you can run and debug ESP32 firmware against it before you order a PCB.
Similar boards
 ESP32
Open Book Abridged Edition
joeycastillo
85 × 115 mm65 parts2LCC-BY-SA-4.08.1k ESP32
Badge
atopile
56.3 × 39 mm239 parts4LMIT4.0k ESP32
Esp32 minimal
36.2 × 26.8 mm20 parts2LMIT4.0k ESP32
Racer
StuckAtPrototype
36 × 50.2 mm70 parts4LApache-2.03.8k ESP32
Controller
29 × 74 mm58 parts4LApache-2.03.8k ESP32
Bitaxe
skot
56.5 × 99.8 mm86 parts4LCERN-OHL-S-2.01.4k