
Payload gimbal

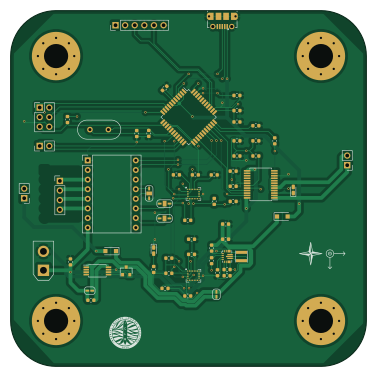
About the Payload gimbal PCB
Payload gimbal is an open source AVR/Arduino PCB design by icl-rocketry, published on GitHub under the MIT license. It is a 2-layer board measuring 94 × 94 mm, with 59 components from 33 distinct parts.
Its main chip is the ATMEGA32U4-AU, from the AVR/Arduino family. Other key parts include the TB6612FNG, TPS2412PW, TPS63070, LSM9DS1 and Pololu_Breakout_A4988. By type, the board carries 22 capacitors, 15 resistors, 8 connectors, 6 ICs, 4 diodes and 1 module.
From the project
the ReAL payload
Main components on the Payload gimbal
Payload gimbal bill of materials (BOM)
59 components, 33 distinct parts — part numbers from the project's BOM.
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 1 | TB6612FNG | SSOP-24_5.3x8.2mm_P0.65mm | U1 |
| 1 | ATMEGA32U4-AU ATmega32U4-AU | TQFP-44_10x10mm_P0.8mm | U2 |
| 1 | TPS2412PW | TSSOP-8_4.4x3mm_P0.65mm | U3 |
| 1 | TPS63070 | Texas_PowerVFQFN_15 | U4 |
| 2 | LSM9DS1 | LGA-24L_3x3.5mm_P0.43mm | U5, U6 |
| 1 | Pololu_Breakout_A4988 | Pololu_Breakout-16_15.2x20.3mm | A1 |
| 1 | PMV20ENR | SOT-23 | Q1 |
| 1 | 8MHZ 8MHz | Crystal_HC49-4H_Vertical | Y1 |
| 1 | Stepper | PinHeader_1x04_P2.54mm_Vertical | J1 |
| 1 | USB_B_Micro | USB_Micro-B_Molex-105017-0001 | J2 |
| 1 | DC Motor | PinHeader_1x02_P2.54mm_Vertical | J3 |
| 1 | LiPo | AMASS_XT30UPB-F_1x02_P5.0mm_Vertical | J4 |
| 1 | UART | PinHeader_1x02_P2.54mm_Vertical | J5 |
| 1 | Encoders | PinHeader_1x06_P2.54mm_Vertical | J6 |
| 1 | ICSP | PinHeader_2x03_P2.54mm_Vertical | J7 |
| 1 | Separate LiPo | PinHeader_1x02_P2.54mm_Vertical | J8 |
| 1 | POWER LED | D_0603_1608Metric_Castellated | D1 |
| 1 | BLINK LED | D_0603_1608Metric_Castellated | D2 |
| 2 | D_Schottky | D_SOD-123F | D3, D4 |
| 1 | 1U5 1u5 | L_Taiyo-Yuden_NR-30xx | L1 |
Show 13 more
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 7 | 10U 10u | C_0603_1608Metric | C1, C8, C9, C11, C12, C15, C20 |
| 1 | 47U 47u | C_0603_1608Metric | C2 |
| 2 | 22P 22p | C_0603_1608Metric | C3, C4 |
| 8 | 100N 100n | C_0603_1608Metric | C5, C10, C14, C16, C17, C19, C21, C22 |
| 1 | 1u | C_0603_1608Metric | C6 |
| 1 | 2.2N 2.2n | C_0603_1608Metric | C7 |
| 2 | 10N 10n | C_0603_1608Metric | C13, C18 |
| 8 | 10K 10k | R_0603_1608Metric | R1, R4, R5, R8, R12, R13, R14, R15 |
| 2 | 4K7 4k7 | R_0603_1608Metric | R2, R3 |
| 2 | 470R | R_0603_1608Metric | R6, R7 |
| 1 | 100K 100k | R_0603_1608Metric | R9 |
| 1 | 470K 470k | R_0603_1608Metric | R10 |
| 1 | 150K 150k | R_0603_1608Metric | R11 |
Payload gimbal design files
The KiCad project lives in the icl-rocketry/payload_gimbal repository on GitHub; these links point at the commit this page was built from.
Payload gimbal: common questions
What microcontroller does the Payload gimbal use?
The Payload gimbal is built around the ATMEGA32U4-AU, from the AVR/Arduino family.
How big is the Payload gimbal PCB?
The Payload gimbal measures 94 × 94 mm, has 2 copper layers and is 1.6 mm thick.
How many components are on the Payload gimbal?
59 components, from 33 distinct parts, with part numbers taken from the project's own BOM. The full bill of materials is listed on this page.
Where can I download the Payload gimbal design files?
From the icl-rocketry/payload_gimbal repository on GitHub, which has the KiCad layout and the BOM; the links under Design files point to each one.
Can I use the Payload gimbal design in my own project?
Yes, under the terms of its MIT license, which icl-rocketry chose for the repository.
Can I test firmware for the Payload gimbal without the hardware?
Yes. HardLabs builds a simulation of the board from its netlist and BOM, so you can run and debug AVR/Arduino firmware against it before you order a PCB.
Similar boards
 AVR/Arduino
Magspoof
samyk
35 × 29 mm11 parts2LNo license4.2k AVR/Arduino
Redox keyboard
mattdibi
162.2 × 126.5 mm77 parts2LMIT2.0k AVR/Arduino
Labrador
espotek-org
36.8 × 34.7 mm75 parts2LNo license1.2k AVR/Arduino
V4
stuartpittaway
30 × 50 mm38 parts2LCC-BY-NC-4.01.1k AVR/Arduino
ModuleV450
30 × 61.4 mm39 parts2LCC-BY-NC-4.01.1k AVR/Arduino
Discipline
coseyfannitutti
304.9 × 122.8 mm170 parts2LCC-BY-NC-4.01.0k