
SCARA-Robot-Based on-ESP32-C6

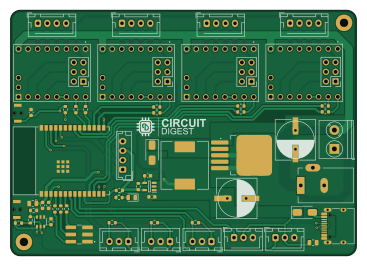
About the SCARA-Robot-Based on-ESP32-C6 PCB
SCARA-Robot-Based on-ESP32-C6 is an open source ESP32 PCB design by jobitjoseph, published on GitHub. It is a 2-layer board measuring 91.6 × 65 mm, with 63 components from 27 distinct parts.
Its main chip is the ESP32-C6-WROOM-1, from the ESP32 family. Other key parts include the ADP7118AUJZ-3.3-R7, LM2596S-5, MAX6899AAZT+T and TMC2209_SILENTSTEPSTICK. By type, the board carries 21 resistors, 17 connectors, 10 capacitors, 8 ICs, 3 diodes and 2 switches.
It belongs with the robotics & motion and iot & wireless designs in this gallery.
From the project
SCARA Robot Based on ESP32-C6
Main components on the SCARA-Robot-Based on-ESP32-C6
SCARA-Robot-Based on-ESP32-C6 bill of materials (BOM)
63 components, 27 distinct parts — part numbers from the project's BOM.
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 1 | ADP7118AUJZ-3.3-R7 | SOT95P280X100-5N | IC1 |
| 1 | LM2596S-5 | TO-263-5_TabPin3 | U1 |
| 1 | MAX6899AAZT+T | MAX6899AAZT+T | U2 |
| 1 | ESP32-C6-WROOM-1 | ESP32-C6-WROOM-1 | U3 |
| 4 | TMC2209_SILENTSTEPSTICK | MODULE_TMC2209_SILENTSTEPSTICK | U4, U5, U6, U7 |
| 1 | SCREW_TERMINAL_2_P5.00MM Screw_Terminal_2_P5.00mm | TerminalBlock_Phoenix_PT-1,5-2-5.0-H_1x02_P5.00mm_Horizontal | J1 |
| 1 | Barrel_Jack_Switch | BarrelJack_Kycon_KLDX-0202-xC_Horizontal | J2 |
| 1 | USB_C_RECEPTACLE_USB2.0 USB_C_Receptacle_USB2.0 | USB_C_Receptacle_HRO_TYPE-C-31-M-12 | J3 |
| 4 | CONN_02X03_TOP_BOTTOM Conn_02x03_Top_Bottom | PinHeader_2x03_P2.54mm_Vertical | J4, J6, J8, J10 |
| 4 | CONN_01X04 Conn_01x04 | JST_XH_B4B-XH-AM_1x04_P2.50mm_Vertical | J5, J7, J9, J11 |
| 5 | CONN_01X03 Conn_01x03 | JST_XH_B3B-XH-AM_1x03_P2.50mm_Vertical | J12, J13, J14, J15, J16 |
| 1 | CONN_01X04 Conn_01x04 | JST_EH_B4B-EH-A_1x04_P2.50mm_Vertical | J17 |
| 1 | RST | Tactile 3x4x2mm TS-A010 | SW1 |
| 1 | BOOT | Tactile 3x4x2mm TS-A010 | SW2 |
| 1 | 150505M173300 | 150505M173300 | LED1 |
| 2 | SS34 | D_SMA | D1, D3 |
| 1 | LED | LED_0805_2012Metric | D2 |
| 1 | 47UH 47uH | L_12x12mm_H8mm | L1 |
| 2 | 330UF 330uF | CAP_J-V_10X10P5_RUB | C1, C2 |
| 1 | 2.2UF 2.2uF | C_0603_1608Metric | C3 |
Show 7 more
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 1 | NC | C_0603_1608Metric | C4 |
| 2 | 10UF 10uF | C_0805_2012Metric | C5, C10 |
| 4 | 0.1UF 0.1uF | C_0603_1608Metric | C7, C8, C9, C11 |
| 1 | 0 | R_0603_1608Metric | R1 |
| 8 | 10K | R_0603_1608Metric | R2, R4, R5, R9, R18, R19, R20, R21 |
| 1 | 47K | R_0603_1608Metric | R3 |
| 11 | 1K | R_0603_1608Metric | R6, R7, R8, R10, R11, R12, R13, R14 +3 |
SCARA-Robot-Based on-ESP32-C6 design files
The KiCad project lives in the jobitjoseph/SCARA-Robot-Based-on-ESP32-C6 repository on GitHub; these links point at the commit this page was built from.
SCARA-Robot-Based on-ESP32-C6: common questions
What microcontroller does the SCARA-Robot-Based on-ESP32-C6 use?
The SCARA-Robot-Based on-ESP32-C6 is built around the ESP32-C6-WROOM-1, from the ESP32 family.
How big is the SCARA-Robot-Based on-ESP32-C6 PCB?
The SCARA-Robot-Based on-ESP32-C6 measures 91.6 × 65 mm, has 2 copper layers and is 1.6 mm thick.
How many components are on the SCARA-Robot-Based on-ESP32-C6?
63 components, from 27 distinct parts, with part numbers taken from the project's own BOM. The full bill of materials is listed on this page.
Where can I download the SCARA-Robot-Based on-ESP32-C6 design files?
From the jobitjoseph/SCARA-Robot-Based-on-ESP32-C6 repository on GitHub, which has the KiCad layout, the schematic and the BOM; the links under Design files point to each one.
Can I use the SCARA-Robot-Based on-ESP32-C6 design in my own project?
The repository has no license, so all rights stay with jobitjoseph. Use it as a reference, and ask the author before reusing the design.
Can I test firmware for the SCARA-Robot-Based on-ESP32-C6 without the hardware?
Yes. HardLabs builds a simulation of the board from its netlist and BOM, so you can run and debug ESP32 firmware against it before you order a PCB.
Similar boards
 ESP32
Open Book Abridged Edition
joeycastillo
85 × 115 mm65 parts2LCC-BY-SA-4.08.1k ESP32
Badge
atopile
56.3 × 39 mm239 parts4LMIT4.0k ESP32
Esp32 minimal
36.2 × 26.8 mm20 parts2LMIT4.0k ESP32
Racer
StuckAtPrototype
36 × 50.2 mm70 parts4LApache-2.03.8k ESP32
Controller
29 × 74 mm58 parts4LApache-2.03.8k ESP32
Bitaxe
skot
56.5 × 99.8 mm86 parts4LCERN-OHL-S-2.01.4k