
MiniRobots

About the MiniRobots PCB
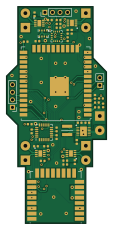
MiniRobots is an open source ESP32 PCB design by Kmshanley, published on GitHub. It is a 4-layer board measuring 26.5 × 57.4 mm, with 42 components from 22 distinct parts.
Its main chip is the ESP32-WROVER-I, from the ESP32 family. Other key parts include the DRV8837CDSGR, ISL9110IRT7Z-T7A, HMC5883L, BMP280 and MPU-6050. By type, the board carries 22 capacitors, 8 ICs, 6 resistors, 3 connectors, 1 module and 1 inductor.
It belongs with the robotics & motion designs in this gallery.
From the project
Firmware and PCB desgin for mini robots with UWB localization and lidar mapping
Main components on the MiniRobots
MiniRobots bill of materials (BOM)
42 components, 22 distinct parts.
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 4 | DRV8837CDSGR | SON50P200X200X80-9N | IC1, IC2, IC3, IC4 |
| 1 | ISL9110IRT7Z-T7A | SON40P300X300X75-13N | IC5 |
| 1 | HMC5883L | HMC5883L | U1 |
| 1 | BMP280 | Bosch_LGA-8_2x2.5mm_P0.65mm_ClockwisePinNumbering | U2 |
| 1 | MPU-6050 | InvenSense_QFN-24_4x4mm_P0.5mm | U3 |
| 1 | ESP32-WROVER-I | ESP32-WROOM-32U | A1 |
| 1 | I2C | PinHeader_1x04_P2.00mm_Vertical | J5 |
| 1 | Uart | PinHeader_1x04_P2.00mm_Vertical | J9 |
| 1 | IO | PinHeader_1x02_P2.00mm_Vertical | J10 |
| 1 | DWM1000 | DWM1000 | DWM1 |
| 1 | 2.2 uH | LQH3NPN100MMEL | L1 |
| 1 | 0.22uf | C_0402_1005Metric | C1 |
| 6 | 10uF | C_0402_1005Metric | C2, C3, C5, C6, C18, C38 |
| 1 | 4.7uf | C_0402_1005Metric | C4 |
| 12 | 0.1uf | C_0402_1005Metric | C7, C8, C9, C10, C11, C12, C14, C15 +4 |
| 1 | 10nf | C_0402_1005Metric | C13 |
| 1 | 2.2nf | C_0402_1005Metric | C28 |
| 1 | 128k | R_0402_1005Metric | R1 |
| 1 | 470k | R_0402_1005Metric | R2 |
| 2 | 4.7k | R_0402_1005Metric | R3, R4 |
Show 2 more
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 1 | 10k | R_0402_1005Metric | R10 |
| 1 | 100k | R_0402_1005Metric | R22 |
MiniRobots design files
The KiCad project lives in the Kmshanley/MiniRobots repository on GitHub; these links point at the commit this page was built from.
MiniRobots: common questions
What microcontroller does the MiniRobots use?
The MiniRobots is built around the ESP32-WROVER-I, from the ESP32 family.
How big is the MiniRobots PCB?
The MiniRobots measures 26.5 × 57.4 mm, has 4 copper layers and is 1.6 mm thick.
How many components are on the MiniRobots?
42 components, from 22 distinct parts. The full bill of materials is listed on this page.
Where can I download the MiniRobots design files?
From the Kmshanley/MiniRobots repository on GitHub, which has the KiCad layout; the links under Design files point to each one.
Can I use the MiniRobots design in my own project?
The repository has no license, so all rights stay with Kmshanley. Use it as a reference, and ask the author before reusing the design.
Can I test firmware for the MiniRobots without the hardware?
Yes. HardLabs builds a simulation of the board from its netlist and BOM, so you can run and debug ESP32 firmware against it before you order a PCB.
Similar boards
 ESP32
Open Book Abridged Edition
joeycastillo
85 × 115 mm65 parts2LCC-BY-SA-4.08.1k ESP32
Badge
atopile
56.3 × 39 mm239 parts4LMIT4.0k ESP32
Esp32 minimal
36.2 × 26.8 mm20 parts2LMIT4.0k ESP32
Racer
StuckAtPrototype
36 × 50.2 mm70 parts4LApache-2.03.8k ESP32
Controller
29 × 74 mm58 parts4LApache-2.03.8k ESP32
Bitaxe
skot
56.5 × 99.8 mm86 parts4LCERN-OHL-S-2.01.4k