
X drone controller

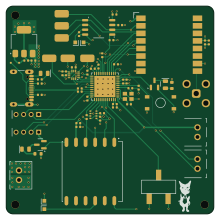
About the X drone controller PCB
X drone controller is an open source STM32 PCB design by Monacrylic, published on GitHub. It is a 4-layer board measuring 55 × 55 mm, with 65 components from 30 distinct parts.
Its main chip is the STM32F411, from the STM32 family. Other key parts include the ICM-42605, W25Q16JVSS, BMP280, L86-M33 and 915MHz. By type, the board carries 22 capacitors, 14 resistors, 7 ICs, 4 diodes, 2 transistors and 1 crystal.
It belongs with the robotics & motion and dev boards & breakouts designs in this gallery.
From the project
This repository contains a suite of sample KiCad circuits used as benchmarks for Pinscope.
This repository contains a suite of sample KiCad circuits used as benchmarks for Pinscope.
The suite is designed to test, validate, and evaluate Pinscope's capabilities in circuit analysis, fault coverage, and netlist validation.
The repository represents four distinct projects. For each project, there are two versions: 1. Original Version: The clean, reference KiCad design, located under Original-schematics/. 2. Fault-Injected Version: A modified version of the reference circuit with simulated hardware, netlist, or schematic faults, in a top-level folder prefixed with x-.
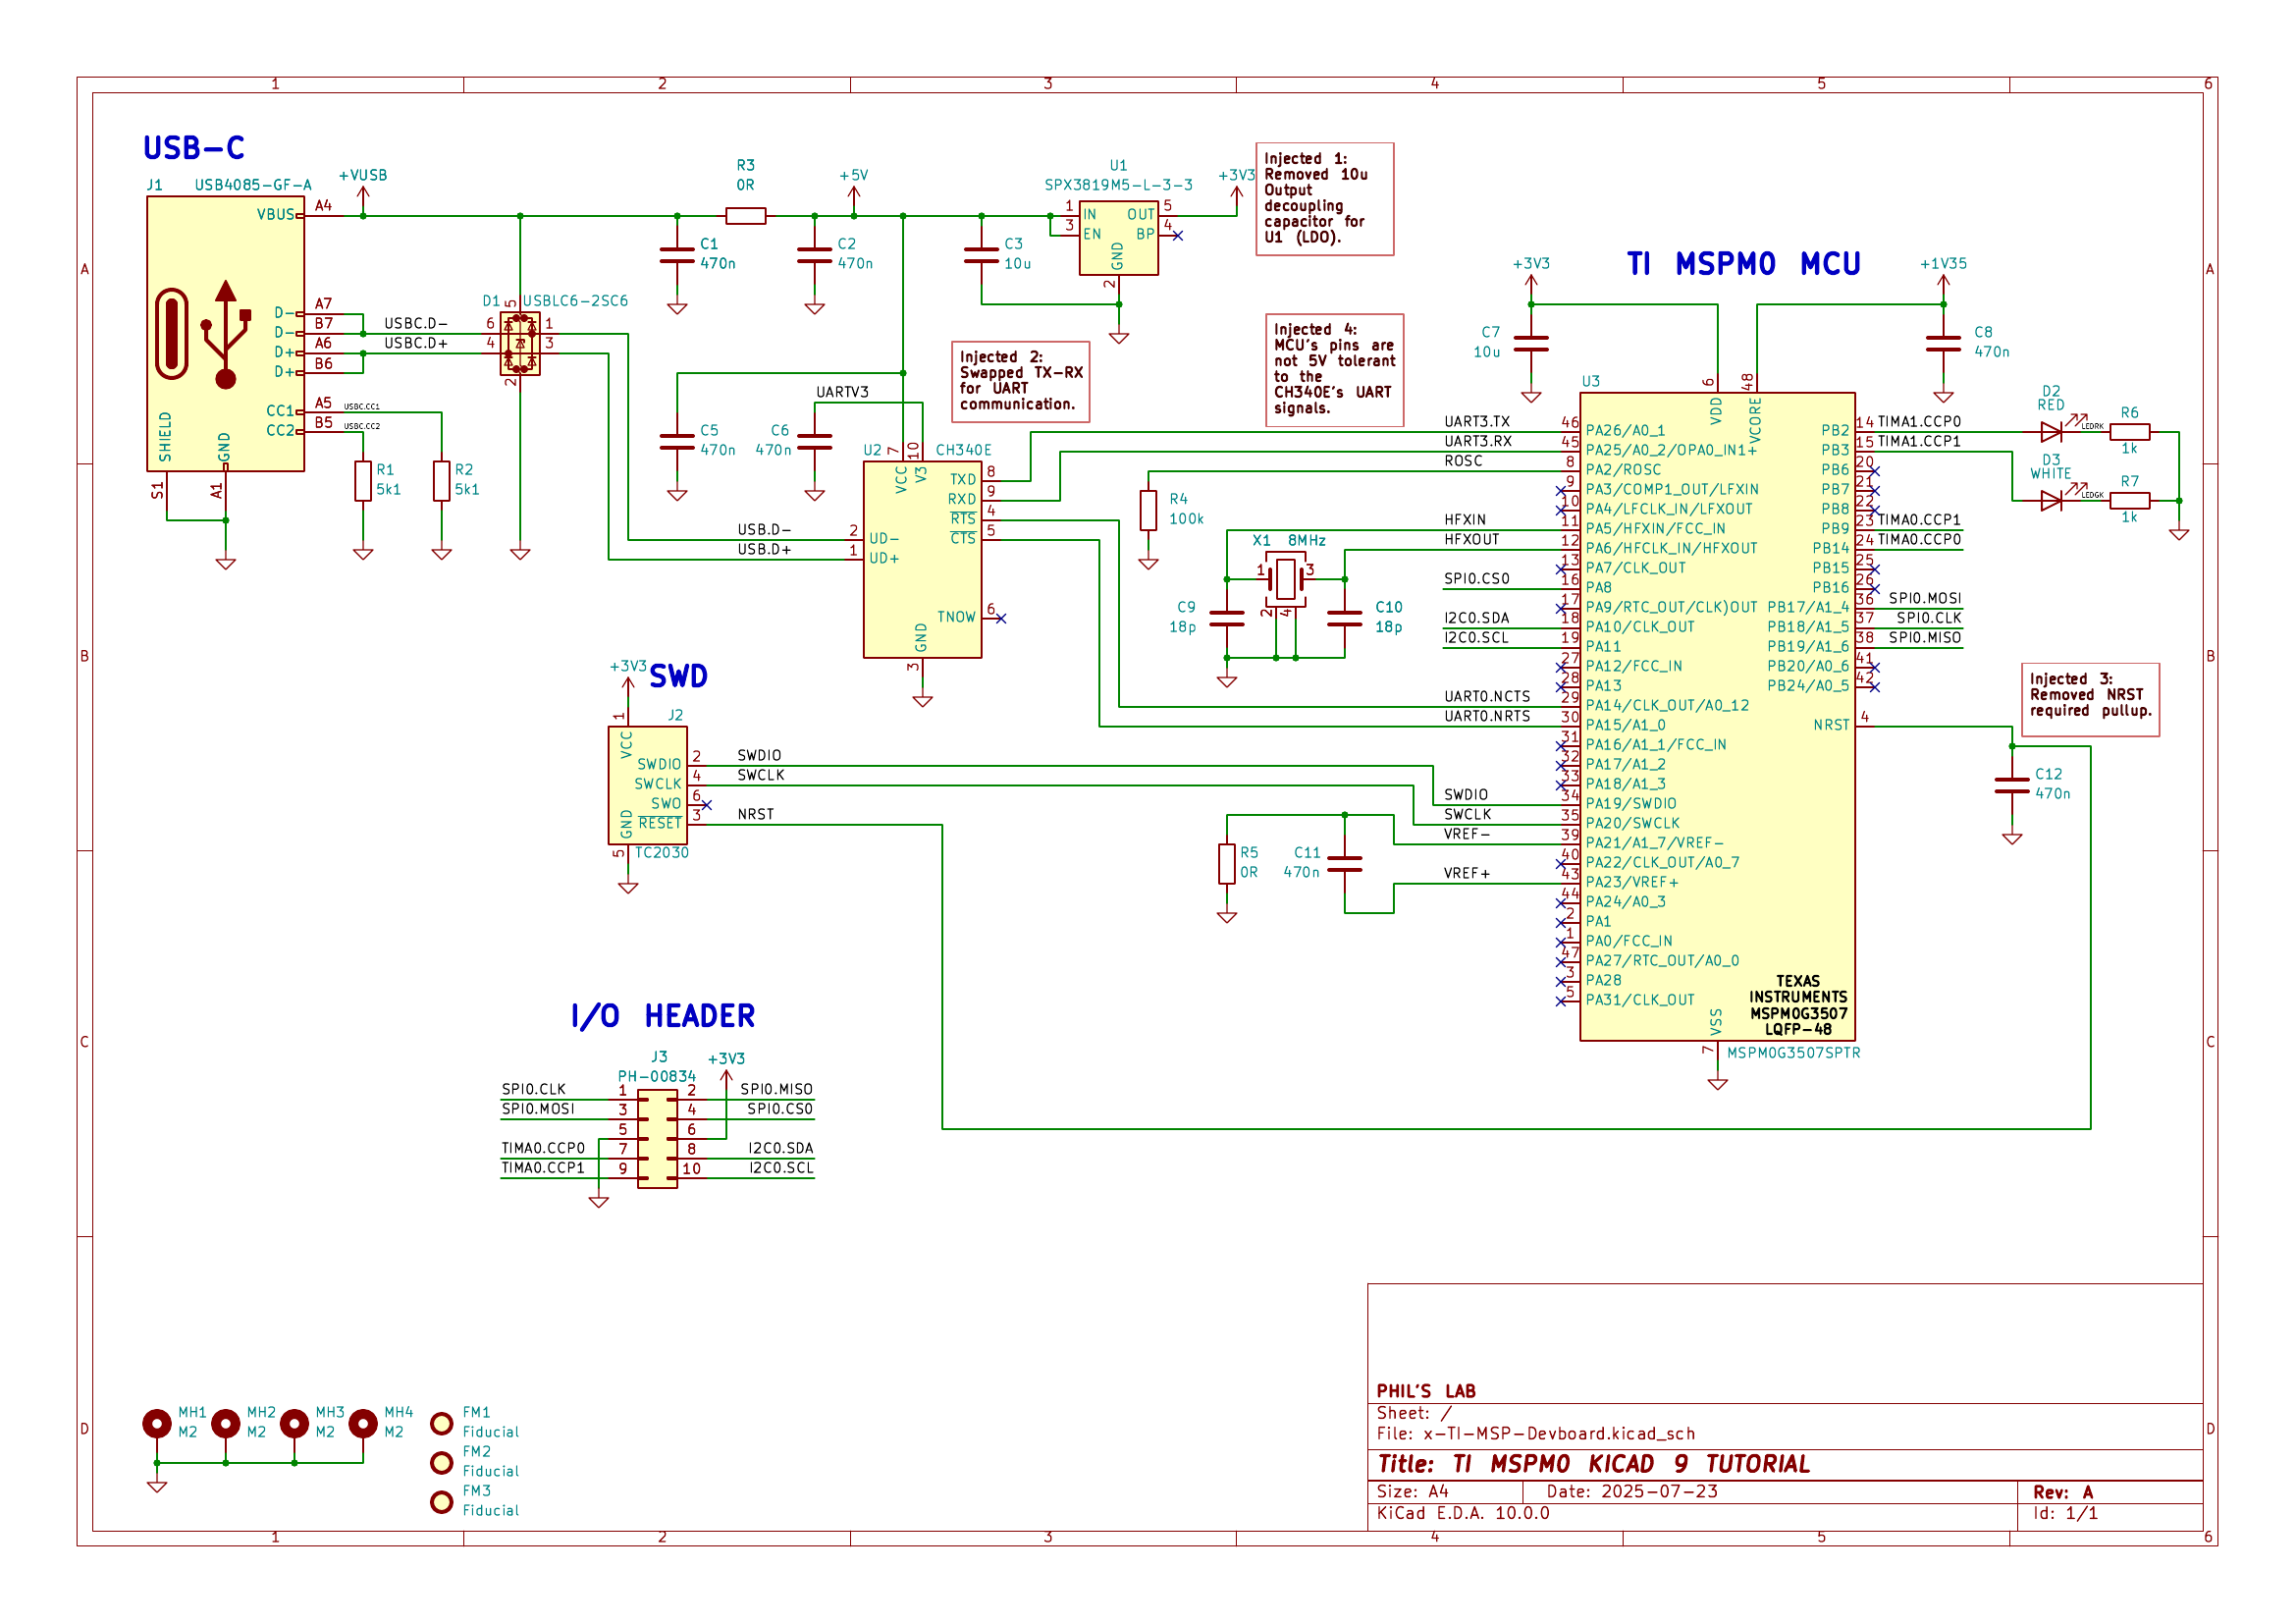
Main components on the X drone controller
X drone controller bill of materials (BOM)
65 components, 30 distinct parts.
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 1 | ICM-42605 | LGA-14_L3.0-W2.5-P0.50-TL | U1 |
| 1 | W25Q16JVSS | SOIC-8_5.3x5.3mm_P1.27mm | U2 |
| 1 | BMP280 | Bosch_LGA-8_2x2.5mm_P0.65mm_ClockwisePinNumbering | U3 |
| 1 | STM32F411 | QFN-48-1EP_7x7mm_P0.5mm_EP5.6x5.6mm | U5 |
| 1 | L86-M33 | XCVR_L86-M33 | U6 |
| 1 | 915MHz | COMM-SMD_LORA1276-C1-915MHZ | U7 |
| 1 | AP7361C-33E | SOT-223-3_TabPin2 | U9 |
| 2 | AO3400A | Q_SOT-23 | Q2, Q3 |
| 1 | Shenzhen SCTF Elec SX2B12.000F1010F30 | Crystal_SMD_2520-4Pin_2.5x2.0mm | X1 |
| 1 | USB_C_Plug | USB-C | P1 |
| 3 | Connector | CONN-TH_B2B-XH-A-LF-SN | +3.3V, BATT1, UART2 |
| 1 | 915MHZ Antenna | SMA_BAT_Wireless_BWSMA-KWE-Z001 | AE1 |
| 6 | TestPoint | TestPoint_Keystone_5019_Miniature | MISO1, MISO2, MOSI1, MOSI2, SCK1, SCK2 |
| 1 | TS1101S | SW-SMD_4P-L4.5-W4.5-P3.15-LS7.5-TL | RESET1 |
| 1 | SW_SPDT | SW-SMD_SHOUHAN_MST-22D18G23J_C2875122 | SW2 |
| 2 | Conn_01x04_Pin | PinHeader_1x04_P2.00mm_Vertical | SWD1, UART1 |
| 1 | PMEG3015EJ | D_SOD-323F | D1 |
| 1 | Green | D_0805 | D3 |
| 2 | Red | D_0805 | D5, D6 |
| 11 | 100nF | C_0402 | C1, C6, C9, C12, C17, C20, C25, C27 +3 |
Show 10 more
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 1 | 10uF Samsung Electro-Mechanics | C_0402 | C3 |
| 5 | 4.7uF | C_0402 | C4, C5, C15, C18, C26 |
| 1 | 2.2uF | C_0402 | C7 |
| 1 | 10nF | C_0402 | C8 |
| 2 | 20pF | C_0402 | C10, C11 |
| 1 | 1uF | C_0402 | C21 |
| 9 | 5.1kΩ | R_0402 | R1, R2, R3, R4, R7, R8, R9, R10 +1 |
| 2 | 75Ω | R_0603 | R5, R13 |
| 2 | 22Ω | R_0402 | R6, R14 |
| 1 | 200Ω | R_0402 | R11 |
X drone controller design files
The KiCad project lives in the Monacrylic/Pinscope-benchmark-circuits repository on GitHub; these links point at the commit this page was built from.
X drone controller: common questions
What microcontroller does the X drone controller use?
The X drone controller is built around the STM32F411, from the STM32 family.
How big is the X drone controller PCB?
The X drone controller measures 55 × 55 mm, has 4 copper layers and is 1.564 mm thick.
How many components are on the X drone controller?
65 components, from 30 distinct parts. The full bill of materials is listed on this page.
Where can I download the X drone controller design files?
From the Monacrylic/Pinscope-benchmark-circuits repository on GitHub, which has the KiCad layout and the schematic; the links under Design files point to each one.
Can I use the X drone controller design in my own project?
The repository has no license, so all rights stay with Monacrylic. Use it as a reference, and ask the author before reusing the design.
Can I test firmware for the X drone controller without the hardware?
Yes. HardLabs builds a simulation of the board from its netlist and BOM, so you can run and debug STM32 firmware against it before you order a PCB.
More boards in Pinscope-benchmark-circuits
 ESP32
MinRead
64.5 × 120.5 mm114 parts2LNo license2 ESP32
X de link
64.5 × 120.5 mm114 parts2LNo license2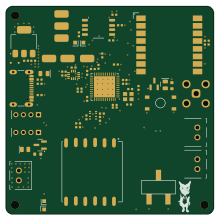 STM32
DroneController
55 × 55 mm65 parts4LNo license2
Osw light
36.1 × 36.1 mm51 parts4LNo license2
X osw light
36.1 × 36.1 mm51 parts4LNo license2
X-TI-MSP-Devboard
55 × 25 mm29 parts2LNo license2
TI-MSP-KICAD9-TUTORIAL
55 × 25 mm29 parts2LNo license2
Similar boards
 STM32
LumenPnP Motherboard
opulo-inc
149 × 95 mm296 parts4LCC-BY-SA-4.03.7k STM32
AxxSolder
AxxAxx
39 × 82.5 mm122 parts2LGPL-3.01.7k STM32
AIOC
skuep
21 × 31.5 mm47 parts2LMIT1.4k STM32
Ferris
pierrechevalier83
208.8 × 86.8 mm102 parts2LSHL-2.11.3k STM32
176 pin board
rusefi
61.8 × 73.2 mm76 parts2LGPL-3.01.2k STM32
Brain board STM32F407
61.8 × 73.2 mm69 parts2LGPL-3.01.2k