
Raster bot

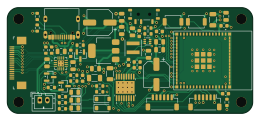
About the Raster bot PCB
Raster bot is an open source ESP32 PCB design by rhammell, published on GitHub. It is a 4-layer board measuring 65 × 28 mm, with 63 components from 34 distinct parts.
Its main chip is the ESP32-S3-MINI-1, from the ESP32 family. Other key parts include the BQ24072RGT, DRV8833PWPR, AP2114H-3.3 and TPS61023DRLR. By type, the board carries 22 capacitors, 19 resistors, 5 ICs, 5 connectors, 5 diodes and 3 transistors.
It belongs with the displays & leds, power & battery and robotics & motion designs in this gallery.
From the project
Raster is a two-wheeled bot featuring a touchscreen display
Raster Bot is a compact, two-wheeled differential-drive robot built around an ESP32 and a capacitive touchscreen display. The project is fully open: it includes the custom PCB, the 3D-printable mechanical design, the firmware (packaged as an Arduino library), and the source graphics.
The firmware provides closed-loop motor control with quadrature encoders and PID speed regulation, battery/charge monitoring, and a touchscreen UI — all wrapped in a simple high-level API so sketches can drive the bot in a few lines.
Main components on the Raster bot
Raster bot bill of materials (BOM)
63 components, 34 distinct parts.
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 1 | ESP32-S3-MINI-1 | ESP32-S3-MINI-1 | U1 |
| 1 | BQ24072RGT | VQFN-16-1EP_3x3mm_P0.5mm_EP1.6x1.6mm_ThermalVias | U2 |
| 1 | DRV8833PWPR | HTSSOP-16-1EP_4.4x5mm_P0.65mm_EP3.4x5mm_Mask2.66x2.46mm_ThermalVias | U3 |
| 1 | AP2114H-3.3 | SOT-223-3_TabPin2 | U4 |
| 1 | TPS61023DRLR | SOT-563 | U5 |
| 2 | AO3401A | SOT-23 | Q1, Q3 |
| 1 | 2N7002 | SOT-23 | Q2 |
| 1 | JST_PH | JST_PH_B2B-PH-K_1x02_P2.00mm_Vertical | J1 |
| 1 | USB_C_Receptacle_USB2.0_16P | USB_C_Receptacle_G-Switch_GT-USB-7010ASV | J2 |
| 1 | Conn_EYESPI | XUNPU_FPC-05F-18PH20_1x18-1MP_P0.5mm_Horizontal | J3 |
| 2 | Conn_Motor_N20_Encoder | JST_SH_BM06B-SRSS-TB_1x06-1MP_P1.00mm_Vertical | J4, J5 |
| 1 | SW_RESET | SW_SPST_TS-1088-xR020 | SW1 |
| 1 | SW_BOOT | SW_SPST_TS-1088-xR020 | SW2 |
| 1 | SW_SPDT_SH | SW_SPDT_Shouhan_MSK12C02 | SW3 |
| 2 | SD103AW | D_SOD-123 | D1, D2 |
| 3 | LED | LED_0805_2012Metric | D3, D4, D5 |
| 1 | 1uH | L_Coilcraft_XxL4030 | L1 |
| 1 | 1uF | C_0603_1608Metric | C1 |
| 5 | 0.1uF | C_0603_1608Metric | C2, C3, C7, C14, C19 |
| 5 | 22uF | C_0805_2012Metric | C4, C12, C18, C21, C22 |
Show 14 more
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 1 | 100uF | C_1206_3216Metric | C5 |
| 6 | 10uF | C_0805_2012Metric | C6, C9, C10, C15, C16, C20 |
| 2 | 470uF | CP_Elec_6.3x7.7 | C8, C17 |
| 1 | 2.2uF | C_0603_1608Metric | C11 |
| 1 | 0.01uF | C_0603_1608Metric | C13 |
| 4 | 10k | R_0603_1608Metric | R1, R7, R8, R12 |
| 4 | 100k | R_0603_1608Metric | R2, R3, R4, R11 |
| 2 | 5.1k | R_0603_1608Metric | R5, R6 |
| 1 | 1.1k | R_0603_1608Metric | R9 |
| 1 | 2.7k | R_0603_1608Metric | R10 |
| 2 | 300m | R_1206_3216Metric | R13, R14 |
| 3 | 4.7k | R_0603_1608Metric | R15, R18, R19 |
| 1 | 220k | R_0603_1608Metric | R16 |
| 1 | 30k | R_0603_1608Metric | R17 |
Raster bot design files
The KiCad project lives in the rhammell/raster-bot repository on GitHub; these links point at the commit this page was built from.
Raster bot: common questions
What microcontroller does the Raster bot use?
The Raster bot is built around the ESP32-S3-MINI-1, from the ESP32 family.
How big is the Raster bot PCB?
The Raster bot measures 65 × 28 mm, has 4 copper layers and is 1.6 mm thick.
How many components are on the Raster bot?
63 components, from 34 distinct parts. The full bill of materials is listed on this page.
Where can I download the Raster bot design files?
From the rhammell/raster-bot repository on GitHub, which has the KiCad layout and the schematic; the links under Design files point to each one.
Can I use the Raster bot design in my own project?
The repository has no license, so all rights stay with rhammell. Use it as a reference, and ask the author before reusing the design.
Can I test firmware for the Raster bot without the hardware?
Yes. HardLabs builds a simulation of the board from its netlist and BOM, so you can run and debug ESP32 firmware against it before you order a PCB.
Similar boards
 ESP32
Open Book Abridged Edition
joeycastillo
85 × 115 mm65 parts2LCC-BY-SA-4.08.1k ESP32
Powertrain
byrantech
64 × 45.4 mm171 parts4LMIT4.3k ESP32
Badge
atopile
56.3 × 39 mm239 parts4LMIT4.0k ESP32
Esp32 minimal
36.2 × 26.8 mm20 parts2LMIT4.0k ESP32
Controller
StuckAtPrototype
29 × 74 mm58 parts4LApache-2.03.8k ESP32
Racer
36 × 50.2 mm70 parts4LApache-2.03.8k