
Control v4.1-stm32

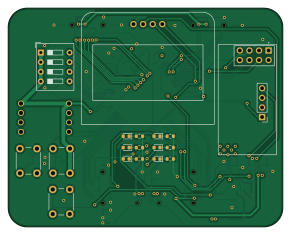
About the Control v4.1-stm32 PCB
Control v4.1-stm32 is an open source STM32 PCB design by RoboJackets, published on GitHub under the Apache-2.0 license. It is a 4-layer board measuring 72.7 × 57.9 mm, with 83 components from 36 distinct parts.
Its main chip is the STM32H723VGTx, from the STM32 family. Other key parts include the TLV62569DBV, TPS2117DRLR and NRF24L01_Breakout. By type, the board carries 25 resistors, 21 capacitors, 16 diodes, 7 connectors, 6 ICs and 4 switches.
It belongs with the robotics & motion designs in this gallery.
From the project
The KiCAD Design Files for Georgia Tech RoboJackets RoboCup Small Size League's Electrical Systems
If you are a new member to the RoboCup electrical team and have never used git version control before, we highly recommend that you familiarize yourself with it by reading this guide.
However, older boards in the archives were designed using EAGLE or PCB (a program that is part of the gEDA project)
Unfortunately, EAGLE and PCB are no longer supported by their respective companies, and are not available for download. If you need access to these files, you are on your own.
Main components on the Control v4.1-stm32
Control v4.1-stm32 bill of materials (BOM)
83 components, 36 distinct parts — part numbers from the project's BOM.
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 1 | TLV62569DBV | SOT-23-5 | U1 |
| 2 | TPS2117DRLR | SOTFL50P160X60-8N | U2, U6 |
| 1 | STM32H723VGTx | LQFP-100_14x14mm_P0.5mm | U3 |
| 1 | ~ | HeaderIMUFooter | U4 |
| 1 | NRF24L01_Breakout | nRF24L01_Breakout | U5 |
| 1 | 25 MHz 10 pF | XTAL_ABM8-25.000MHz-10-B1U-T | Y1 |
| 1 | 32.768K 7pF | XTAL_ABS07-32.768KHZ-T | Y2 |
| 4 | 53625-0274 Molex | 536250274 | J1, J3, J4, J5 |
| 1 | Conn_01x04_Pin | PinHeader_1x04_P2.54mm_Vertical | J2 |
| 1 | USB_C_Receptacle_USB2.0_16P | USB_C_Receptacle_GCT_USB4110 | J6 |
| 1 | Conn_01x04_Pin | Adafruit_SSD1306_No_Mounting_Holes | J7 |
| 3 | SW_Push | SW_PUSH_6mm | SW1, SW2, SW4 |
| 1 | ~ | SW_DIP_SPSTx04_Slide_9.78x12.34mm_W7.62mm_P2.54mm | SW3 |
| 1 | B5819WS-TP | SOD2512X115N | D1 |
| 5 | PJSD05TS | SOD-523_0P9X1P3_ONS | D2, D3, D8, D9, D10 |
| 4 | TPD1E04U04DPYR | DPY2_TEX | D4, D5, D6, D7 |
| 6 | LED | D_0603_1608Metric | D11, D12, D13, D14, D15, D16 |
| 1 | 1K, 100Mhz | BEADC1608X95N | FB1 |
| 1 | 2.2uH | L_0603_1608Metric | L1 |
| 2 | 2.2uF | C_0603_1608Metric | C1, C2 |
Show 16 more
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 8 | 100nF | C_0603_1608Metric | C3, C4, C5, C6, C7, C8, C13, C19 |
| 1 | 4.2uF | C_0603_1608Metric | C9 |
| 1 | 4.7uF | C_0603_1608Metric | C10 |
| 2 | 1uF | C_0603_1608Metric | C12, C14 |
| 2 | 10pF | C_0603_1608Metric | C15, C16 |
| 2 | 12pF | C_0603_1608Metric | C17, C18 |
| 1 | 22pF | C_0603_1608Metric | C20 |
| 2 | 10uF | C_0603_1608Metric | C21, C22 |
| 2 | 5.1k | R_0603_1608Metric | R1, R2 |
| 5 | 10k | R_0603_1608Metric | R3, R4, R5, R6, R11 |
| 4 | 330 | R_0603_1608Metric | R7, R8, R9, R10 |
| 1 | 680k | R_0603_1608Metric | R12 |
| 1 | 150k | R_0603_1608Metric | R13 |
| 2 | 210k | R_0603_1608Metric | R14, R23 |
| 4 | 100k | R_0603_1608Metric | R15, R18, R24, R25 |
| 6 | 1k | R_0603_1608Metric | R19, R20, R21, R22, R26, R27 |
Control v4.1-stm32 design files
The KiCad project lives in the RoboJackets/robocup-pcb repository on GitHub; these links point at the commit this page was built from.
Control v4.1-stm32: common questions
What microcontroller does the Control v4.1-stm32 use?
The Control v4.1-stm32 is built around the STM32H723VGTx, from the STM32 family.
How big is the Control v4.1-stm32 PCB?
The Control v4.1-stm32 measures 72.7 × 57.9 mm, has 4 copper layers and is 1.6 mm thick.
How many components are on the Control v4.1-stm32?
83 components, from 36 distinct parts, with part numbers taken from the project's own BOM. The full bill of materials is listed on this page.
Where can I download the Control v4.1-stm32 design files?
From the RoboJackets/robocup-pcb repository on GitHub, which has the KiCad layout, the schematic and the BOM; the links under Design files point to each one.
Can I use the Control v4.1-stm32 design in my own project?
Yes, under the terms of its Apache-2.0 license, which RoboJackets chose for the repository.
Can I test firmware for the Control v4.1-stm32 without the hardware?
Yes. HardLabs builds a simulation of the board from its netlist and BOM, so you can run and debug STM32 firmware against it before you order a PCB.
More boards in robocup-pcb
Motorboard
132 × 96 mm286 parts4LApache-2.032 RP2040/RP2350
Kicker Board
141 × 146.5 mm123 parts4LApache-2.032
Motor module
64.5 × 66.9 mm122 parts2LApache-2.032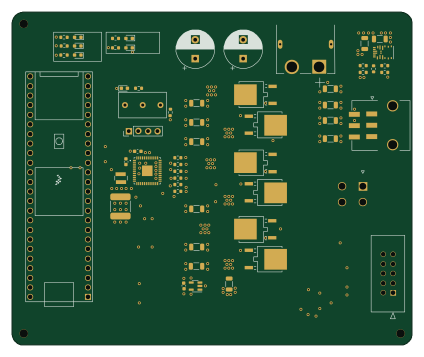 NXP
Motortester v2.0
105.9 × 88.1 mm76 parts4LApache-2.032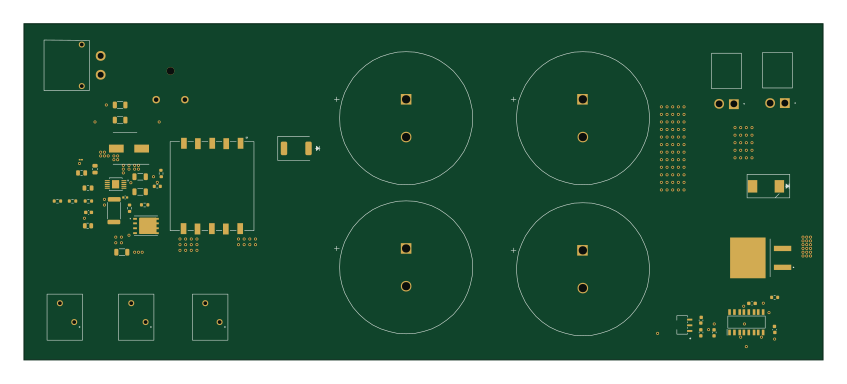
Flyback breakout v1.0
211.5 × 89 mm51 parts2LApache-2.032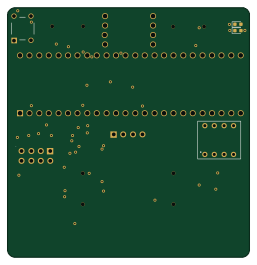 NXP
Control v4.0
64 × 66 mm17 parts4LApache-2.032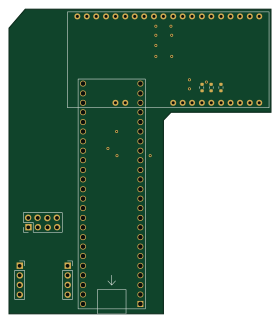 NXP
Teensy adapter v3.0
69.3 × 80.7 mm8 parts4LApache-2.032
Similar boards
 STM32
LumenPnP Motherboard
opulo-inc
149 × 95 mm296 parts4LCC-BY-SA-4.03.7k STM32
AxxSolder
AxxAxx
39 × 82.5 mm122 parts2LGPL-3.01.7k STM32
LibreVNA
jankae
122 × 98 mm592 parts6LGPL-3.01.6k STM32
AIOC
skuep
21 × 31.5 mm47 parts2LMIT1.4k STM32
Ferris
pierrechevalier83
208.8 × 86.8 mm102 parts2LSHL-2.11.3k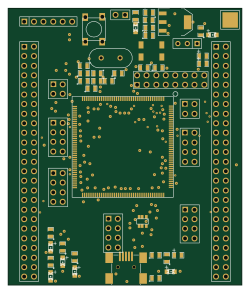 STM32
176 pin board
rusefi
61.8 × 73.2 mm76 parts2LGPL-3.01.2k