
ESP32-S3 6 Motor Driver IMU

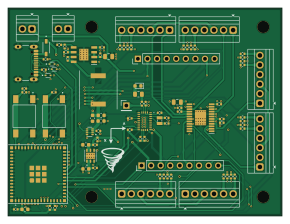
About the ESP32-S3 6 Motor Driver IMU PCB
ESP32-S3 6 Motor Driver IMU is an open source ESP32 PCB design by Amronos, published on GitHub. It is a 4-layer board measuring 72.5 × 55 mm, with 92 components from 31 distinct parts.
Its main chip is the ESP32-S3-MINI-1-N8, from the ESP32 family. Other key parts include the LD39200PU33R, LMR38020FDDAR, TPS2116DRLR, DRV8912QPWPRQ1 and BNO086. By type, the board carries 40 resistors, 25 capacitors, 6 ICs, 6 connectors, 5 diodes and 2 switches.
It belongs with the robotics & motion, iot & wireless and sensors designs in this gallery.
From the project
A board featuring an ESP32-S3, a 6-channel DC motor driver, an integrated IMU, and support for encoder feedback.
This board features an ESP32-S3 microcontroller, a 6-channel DC motor driver, and an integrated BNO086 IMU for precise motion and orientation data. It supports encoder feedback, enabling accurate position control. Motors can be driven at voltages up to 36V.
This board is perfect for robots requiring more than two motors. Simply wire your motors, connect the board to a PC, another microcontroller, or even your phone/tablet and use the ESP32-S3's versatile communication options like I2C, SPI, UART, Wi-Fi, and Bluetooth to control your robot.
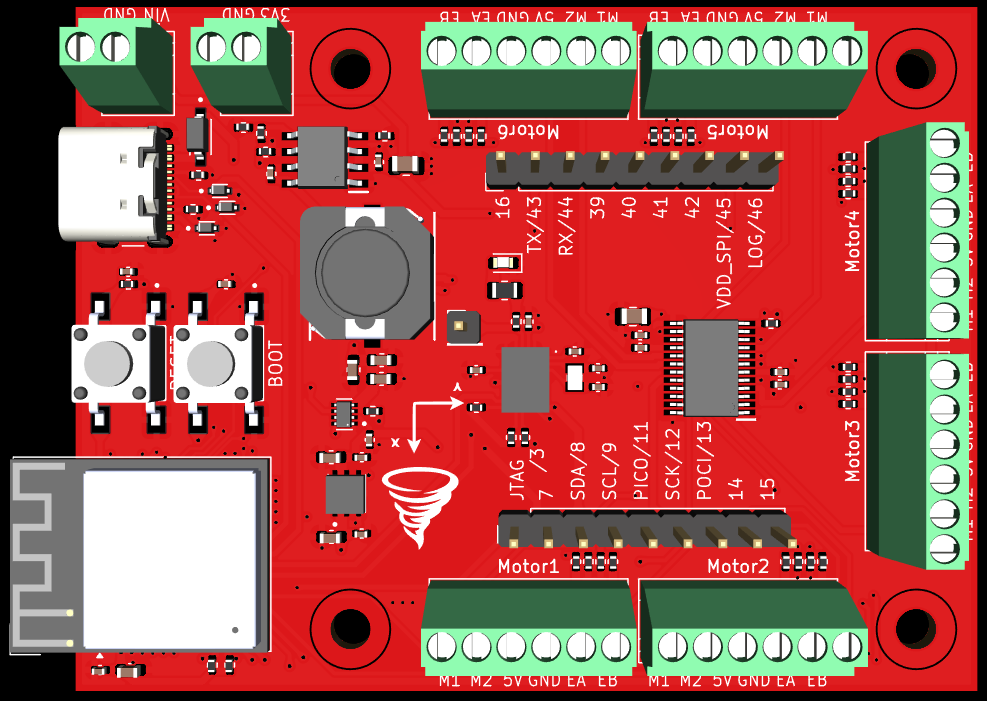
Main components on the ESP32-S3 6 Motor Driver IMU
ESP32-S3 6 Motor Driver IMU bill of materials (BOM)
92 components, 31 distinct parts — part numbers from the project's BOM.
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 1 | ESP32-S3-MINI-1-N8 ESP32-S3-MINI-1 Espressif Systems | ESP32-S2-MINI-1 | U1 |
| 1 | LD39200PU33R STMicroelectronics | SON95P300X300X100-7N | U2 |
| 1 | LMR38020FDDAR Texas Instruments | SOIC127P600X170-9N | U3 |
| 1 | TPS2116DRLR Texas Instruments | SOTFL50P160X60-8N | U4 |
| 1 | DRV8912QPWPRQ1 Texas Instruments | SOP65P640X120-25N | U5 |
| 1 | BNO086 Ceva | BNO086 | U6 |
| 1 | CM8V-T1A-32.768KHZ-12.5PF-20PPM-TB-QA 32.768 kHz Micro Crystal | CM8V32768TA020125 | Y1 |
| 1 | USB4105-GF-A USB_C_Receptacle_USB2.0_16P GCT | USB_C_Receptacle_GCT_USB4105-xx-A_16P_TopMnt_Horizontal | J1 |
| 2 | CONN_01X09 Conn_01x09 Generic | PinHeader_1x09_P2.54mm_Vertical | J2, J3 |
| 1 | CONN_01X01 Conn_01x01 Generic | PinHeader_1x01_P2.54mm_Vertical | J4 |
| 2 | XY308-2.54-2P Screw_Terminal_01x02 XINYA | TerminalBlock_Xinya_XY308-2.54-2P_1x02_P2.54mm_Horizontal | J5, J6 |
| 6 | Screw_Terminal_01x06 | TerminalBlock_Xinya_XY308-2.54-6P_1x06_P2.54mm_Horizontal | Motor1, Motor2, Motor3, Motor4, Motor5, Motor6 |
| 2 | 3-1437565-0 TE Connectivity | SW_3-1437565-0 | SW1, SW2 |
| 1 | 1N5819HW-7-F Diodes Incorporated | SOD3715X145N | D1 |
| 3 | LESD5D5.0CT1G LRC | TVS_LESD5D5.0CT1G | D2, D3, D4 |
| 1 | SML-D12V8WT86C LED ROHM Semiconductor | LED_0603_1608Metric | D5 |
| 1 | MSS1038-153MLC 15 µH Coilcraft | INDPM102100X400N | L1 |
| 2 | GRM21BR61H106KE43L 10 µF Murata Electronics | C_0805_2012Metric | C1, C16 |
| 14 | CL05B104KB54PNC 100 nF Samsung Electro-Mechanics | C_0402_1005Metric | C2, C3, C8, C9, C10, C11, C13, C15 +6 |
| 3 | GRT188R61A226ME13D 22 µF Murata Electronics | C_0603_1608Metric | C4, C5, C6 |
Show 11 more
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 3 | GRT188R61E106ME13D 10 µF Murata Electronics | C_0603_1608Metric | C7, C12, C14 |
| 1 | GRT155R61A475ME13D 4.7 µF Murata Electronics | C_0402_1005Metric | C19 |
| 2 | GCM1555C1H220FA16D 22 pF Murata Electronics | C_0402_1005Metric | C20, C22 |
| 2 | ERA-2AED512X 5.1 kΩ Panasonic Electronic Components | R_0402_1005Metric | R1, R2 |
| 18 | ERA-2AEB103X 10 kΩ Panasonic Electronic Components | R_0402_1005Metric | R3, R4, R5, R9, R10, R15, R16, R20 +10 |
| 1 | ERA-2AEB6492X 64.9 kΩ Panasonic Electronic Components | R_0402_1005Metric | R6 |
| 1 | ERA-2AEB104X 100 kΩ Panasonic Electronic Components | R_0402_1005Metric | R7 |
| 1 | ERA-2AEB2492X 24.9 kΩ Panasonic Electronic Components | R_0402_1005Metric | R8 |
| 4 | ERA-2AEB472X 4.7 kΩ Panasonic Electronic Components | R_0402_1005Metric | R11, R12, R17, R18 |
| 12 | ERA-2AEB203X 20 kΩ Panasonic Electronic Components | R_0402_1005Metric | R13, R14, R19, R21, R23, R25, R27, R29 +4 |
| 1 | ERA-3AEB510V 51 Ω Panasonic Electronic Components | R_0805_2012Metric | R40 |
ESP32-S3 6 Motor Driver IMU design files
The KiCad project lives in the Amronos/ESP32-S3_6_Motor_Driver_IMU repository on GitHub; these links point at the commit this page was built from.
ESP32-S3 6 Motor Driver IMU: common questions
What microcontroller does the ESP32-S3 6 Motor Driver IMU use?
The ESP32-S3 6 Motor Driver IMU is built around the ESP32-S3-MINI-1-N8, from the ESP32 family.
How big is the ESP32-S3 6 Motor Driver IMU PCB?
The ESP32-S3 6 Motor Driver IMU measures 72.5 × 55 mm, has 4 copper layers and is 1.6 mm thick.
How many components are on the ESP32-S3 6 Motor Driver IMU?
92 components, from 31 distinct parts, with part numbers taken from the project's own BOM. The full bill of materials is listed on this page.
Where can I download the ESP32-S3 6 Motor Driver IMU design files?
From the Amronos/ESP32-S3_6_Motor_Driver_IMU repository on GitHub, which has the KiCad layout, the schematic and the BOM; the links under Design files point to each one.
Can I use the ESP32-S3 6 Motor Driver IMU design in my own project?
The repository has no license, so all rights stay with Amronos. Use it as a reference, and ask the author before reusing the design.
Can I test firmware for the ESP32-S3 6 Motor Driver IMU without the hardware?
Yes. HardLabs builds a simulation of the board from its netlist and BOM, so you can run and debug ESP32 firmware against it before you order a PCB.
Similar boards
 ESP32
OSO-BOOK-B1
joeycastillo
85 × 115 mm65 parts2LCC-BY-SA-4.08.1k ESP32
Powertrain
byrantech
64 × 45.4 mm171 parts4LMIT4.3k ESP32
Badge
atopile
56.3 × 39 mm239 parts4LMIT4.0k ESP32
Esp32 minimal
36.2 × 26.8 mm20 parts2LMIT4.0k ESP32
Controller
StuckAtPrototype
29 × 74 mm58 parts4LApache-2.03.8k ESP32
Racer
36 × 50.2 mm70 parts4LApache-2.03.8k