
CamRover

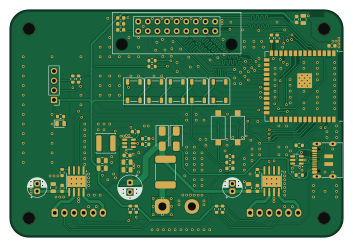
About the CamRover PCB
CamRover is an open source ESP32 PCB design by aravindjayan, published on GitHub. It is a 2-layer board measuring 88 × 60 mm, with 62 components from 28 distinct parts.
Its main chip is the ESP32-S3-WROOM-1, from the ESP32 family. Other key parts include the OV7670, TPS562201DDCR, SRV05-4 and DRV8871DDA. By type, the board carries 19 capacitors, 19 resistors, 8 diodes, 6 ICs, 5 connectors and 2 switches.
It belongs with the robotics & motion and iot & wireless designs in this gallery.
From the project
PCB and bringup codebase for an ESP32-S3 based wheeled robot with an OV2640 camera. Built for IIT Palakkad EE4505 course.
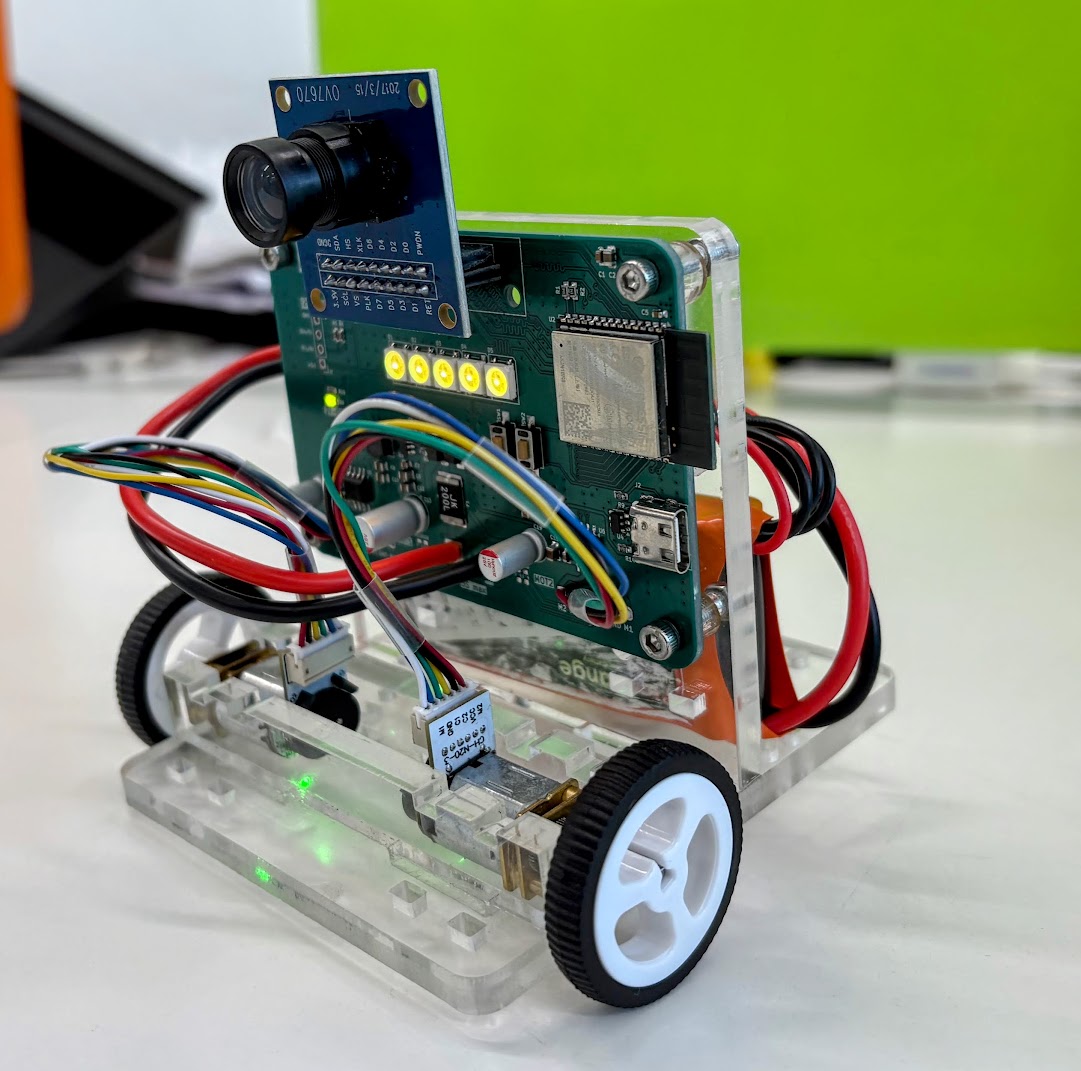
camRover is an ESP32-S3 rover platform with an OV7670 camera, two encoder-equipped DC motors, and addressable RGB LEDs. This repository contains the KiCad hardware design, release manufacturing files, and Arduino firmware used to bring up and test the board.
- boardbringup/ — Arduino ESP32-S3 firmware for camera streaming over Wi-Fi and testing motors, quadrature encoders, and LEDs. - camRoverpcb/camRoverpcbv11/ — KiCad v1.1 project, hierarchical schematics, PCB layout, assembly files, stencil outputs, and release Gerbers/drill files. - camroverimg.jpg — photo of the built rover.
Main components on the CamRover
CamRover bill of materials (BOM)
62 components, 28 distinct parts.
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 1 | OV7670 | ov7670_dipModule | U1 |
| 1 | ESP32-S3-WROOM-1 | ESP32-S3-WROOM-1 | U2 |
| 1 | TPS562201DDCR | SOT-23-6 | U3 |
| 1 | SRV05-4 | SOT-23-6 | U4 |
| 2 | DRV8871DDA | Texas_HTSOP-8-1EP_3.9x4.9mm_P1.27mm_EP2.95x4.9mm_Mask2.4x3.1mm_ThermalVias | U5, U6 |
| 1 | Conn_01x04 | PinHeader_1x04_P2.54mm_Vertical | J1 |
| 1 | USB_C_Receptacle_USB2.0_16P | USB_C_Receptacle_U263-163N-4WS1735-XKB | J2 |
| 1 | Conn_01x02 | SolderWire-1.5sqmm_1x02_P7.8mm_D1.7mm_OD3.9mm | J3 |
| 2 | Conn_01x06 | 6pin_wireConn_2.54p | J4, J5 |
| 1 | Polyfuse - SMD200F/24-2920-2 | Fuse_2920_7451Metric | F1 |
| 2 | TSB008A2526A | SW_SPST_CK_RS282G05A3 | SW1, SW2 |
| 5 | WS2812B | LED_WS2812B_PLCC4_5.0x5.0mm_P3.2mm | D1, D2, D3, D4, D5 |
| 1 | SMAJ13CA | D_SMA | D6 |
| 1 | SS34_SMA | D_SMA | D7 |
| 1 | LED | LED_0805_2012Metric | D8 |
| 1 | 220R@100M 0603 | L_0603_1608Metric | FB1 |
| 1 | 3.3uH_SWPA5020 | L_Sunlord_SWPA5020S | L1 |
| 3 | 1u_0603_25V | C_0603_1608Metric | C1, C4, C11 |
| 3 | 22u_0805_16V | C_0805_2012Metric | C2, C8, C10 |
| 6 | 100n_0603_25V | C_0603_1608Metric | C3, C5, C6, C7, C16, C17 |
Show 8 more
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 4 | 10u_0805_25V | C_0805_2012Metric | C9, C12, C14, C15 |
| 1 | 470uF/25V D5 | CP_Radial_D6.3mm_P2.50mm | C13 |
| 2 | 100uF/25V D5 | CP_Radial_D5.0mm_P2.00mm | C18, C19 |
| 2 | 22R_0603 | R_0603_1608Metric | R1, R2 |
| 11 | 10K_1%_0603 | R_0603_1608Metric | R3, R4, R5, R6, R8, R10, R11, R15 +3 |
| 3 | 33.2K_1%_0603 | R_0603_1608Metric | R7, R12, R13 |
| 2 | 4K7_0603 | R_0603_1608Metric | R9, R14 |
| 1 | 470R_0603 | R_0603_1608Metric | R19 |
CamRover design files
The KiCad project lives in the aravindjayan/CamRover repository on GitHub; these links point at the commit this page was built from.
CamRover: common questions
What microcontroller does the CamRover use?
The CamRover is built around the ESP32-S3-WROOM-1, from the ESP32 family.
How big is the CamRover PCB?
The CamRover measures 88 × 60 mm, has 2 copper layers and is 1.6 mm thick.
How many components are on the CamRover?
62 components, from 28 distinct parts. The full bill of materials is listed on this page.
Where can I download the CamRover design files?
From the aravindjayan/CamRover repository on GitHub, which has the KiCad layout and the schematic; the links under Design files point to each one.
Can I use the CamRover design in my own project?
The repository has no license, so all rights stay with aravindjayan. Use it as a reference, and ask the author before reusing the design.
Can I test firmware for the CamRover without the hardware?
Yes. HardLabs builds a simulation of the board from its netlist and BOM, so you can run and debug ESP32 firmware against it before you order a PCB.
Similar boards
 ESP32
OSO-BOOK-B1
joeycastillo
85 × 115 mm65 parts2LCC-BY-SA-4.08.1k ESP32
Powertrain
byrantech
64 × 45.4 mm171 parts4LMIT4.3k ESP32
Esp32 minimal
atopile
36.2 × 26.8 mm20 parts2LMIT4.0k ESP32
Badge
56.3 × 39 mm239 parts4LMIT4.0k ESP32
Racer
StuckAtPrototype
36 × 50.2 mm70 parts4LApache-2.03.8k ESP32
Controller
29 × 74 mm58 parts4LApache-2.03.8k