
Soft-Robotics

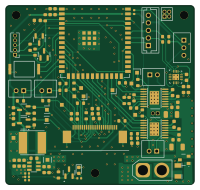
About the Soft-Robotics PCB
Soft-Robotics is an open source ESP32 PCB design by esb8, published on GitHub under the Custom license license. It is a 4-layer board measuring 49.9 × 47.3 mm, with 84 components from 35 distinct parts.
Its main chip is the ESP32-S3-WROOM-1-N16R8, from the ESP32 family. Other key parts include the PZ127-2-02-Z, MPU6500, DRV8874PWPR, XC6206P282MR and XC6206P122MR. By type, the board carries 32 capacitors, 26 resistors, 10 connectors, 8 ICs, 4 transistors and 1 fuse.
It belongs with the robotics & motion and dev boards & breakouts designs in this gallery.
From the project
Custom PCB for soft robotic applications
This project features a soft-robotics controller built around an ESP32 with an onboard camera, driver stages for multiple electromagnets, photoresistor sensing, SPI breakouts, and a UART header for easy flashing all developed for bio-inspired robotics at ELXIR LAB.
Main components on the Soft-Robotics
Soft-Robotics bill of materials (BOM)
84 components, 35 distinct parts — part numbers from the project's BOM.
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 1 | PZ127-2-02-Z | HDR-TH_4P-P1.27-V-M-R2-C2-S1.27_MH127V-12-04-0820 | U1 |
| 1 | MPU6500 | QFN-24-1EP_3x3mm_P0.4mm_EP1.75x1.6mm | U3 |
| 2 | DRV8874PWPR | HTSSOP-16_L5.0-W4.4-P0.65-LS6.4-BL-EP | U4, U5 |
| 1 | ESP32-S3-WROOM-1-N16R8 | ESP32-S3-WROOM-1_EXP | U9 |
| 1 | XC6206P282MR | SOT-23-3 | U12 |
| 1 | XC6206P122MR | SOT-23-3 | U13 |
| 1 | SY8113IADC | TSOT-23-6_L2.9-W1.6-P0.95-LS2.8-BL | U14 |
| 2 | S8050 MDD(Microdiode Electronics) | Q_SOT-23 | Q1, Q2 |
| 1 | AO3401A | SOT-23_L2.9-W1.3-P1.90-LS2.4-BR | Q3 |
| 1 | AO3400A Alpha & Omega Semicon | Q_SOT-23 | Q4 |
| 1 | C99102 Connector | AMASS_XT30U-F_1x02_P5.0mm_Vertical | J1 |
| 1 | CONN_01X03 Conn_01x03 | JST_B3B-PH-K-S | J3 |
| 1 | CONN_01X05_PIN Conn_01x05_Pin | PinHeader_1x05_P1.27mm_Vertical | J4 |
| 1 | CONN_01X02_PIN Conn_01x02_Pin | HDR-TH_2P-P1.27-V-M | J5 |
| 4 | SCREW_TERMINAL_01X02 Screw_Terminal_01x02 | JST_B2B-PH-K-S | J6, J7, J9, J10 |
| 1 | CONN_01X24_SOCKET Conn_01x24_Socket | FPC-SMD_AFC07-S24ECA-00 | J8 |
| 1 | C157993 B5B-PH-K-S-(LF)(SN) | CONN-TH_B5B-PH-K-S-LF-SN | J12 |
| 1 | C41367230 BHFUSE BSMD1206C-1700T | F1206 | F1 |
| 1 | SW_DIP_X02 SW_DIP_x02 | SW-SMD_4P_DSHP02TSGET | SW4 |
| 1 | C2286 Red Hubei KENTO Elec | D_0603 | D2 |
Show 15 more
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 1 | 6.8UH 6.8uH | IND-SMD_L6.0-W6.0 | L1 |
| 4 | 10NF 10nF FH(Guangdong Fenghua Advanced Tech) | C_0603 | C1, C2, C22, C27 |
| 7 | 100NF 100nF YAGEO | C_0603 | C3, C9, C11, C12, C21, C29, C30 |
| 1 | 220PF 220pF FH(Guangdong Fenghua Advanced Tech) | C_0402 | C4 |
| 4 | 22UF 22uF Samsung Electro-Mechanics | C_0603 | C5, C6, C10, C33 |
| 2 | 22NF 22nF Samsung Electro-Mechanics | C_0603 | C7, C28 |
| 2 | 10UF 10uF Samsung Electro-Mechanics | C_0603 | C8, C32 |
| 5 | 1UF 1uF Samsung Electro-Mechanics | C_0603 | C13, C17, C18, C19, C20 |
| 5 | 2.2UF 2.2uF Samsung Electro-Mechanics | C_0603 | C23, C24, C25, C26, C31 |
| 2 | 10UF 10uF Samsung Electro-Mechanics | C_1206 | C34, C35 |
| 12 | 10kΩ UNI-ROYAL(Uniroyal Elec) | R_0603 | R1, R2, R7, R8, R9, R10, R12, R13 +4 |
| 10 | 4.7kΩ UNI-ROYAL(Uniroyal Elec) | R_0603 | R3, R11, R14, R15, R16, R17, R19, R20 +2 |
| 2 | 200Ω UNI-ROYAL(Uniroyal Elec) | R_0402 | R4, R18 |
| 1 | 100kΩ UNI-ROYAL(Uniroyal Elec) | R_0402 | R5 |
| 1 | 22kΩ UNI-ROYAL(Uniroyal Elec) | R_0402 | R6 |
Soft-Robotics design files
The KiCad project lives in the esb8/Soft-Robotics repository on GitHub; these links point at the commit this page was built from.
Soft-Robotics: common questions
What microcontroller does the Soft-Robotics use?
The Soft-Robotics is built around the ESP32-S3-WROOM-1-N16R8, from the ESP32 family.
How big is the Soft-Robotics PCB?
The Soft-Robotics measures 49.9 × 47.3 mm, has 4 copper layers and is 1.6 mm thick.
How many components are on the Soft-Robotics?
84 components, from 35 distinct parts, with part numbers taken from the project's own BOM. The full bill of materials is listed on this page.
Where can I download the Soft-Robotics design files?
From the esb8/Soft-Robotics repository on GitHub, which has the KiCad layout, the schematic and the BOM; the links under Design files point to each one.
Can I use the Soft-Robotics design in my own project?
It is published under Custom license, which limits how it may be reused; read the license before building on it.
Can I test firmware for the Soft-Robotics without the hardware?
Yes. HardLabs builds a simulation of the board from its netlist and BOM, so you can run and debug ESP32 firmware against it before you order a PCB.
Similar boards
 ESP32
OSO-BOOK-B1
joeycastillo
85 × 115 mm65 parts2LCC-BY-SA-4.08.1k ESP32
Powertrain
byrantech
64 × 45.4 mm171 parts4LMIT4.3k ESP32
Badge
atopile
56.3 × 39 mm239 parts4LMIT4.0k ESP32
Esp32 minimal
36.2 × 26.8 mm20 parts2LMIT4.0k ESP32
Racer
StuckAtPrototype
36 × 50.2 mm70 parts4LApache-2.03.8k ESP32
Controller
29 × 74 mm58 parts4LApache-2.03.8k