
Robot

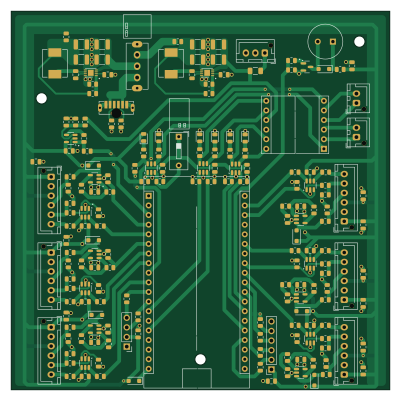
About the Robot PCB
Robot is an open source ESP32 PCB design by jgraulle, published on GitHub. It is a 2-layer board measuring 100 × 100 mm, with 183 components from 31 distinct parts.
Its main chip is the ESP32-DEVKITC, from the ESP32 family. Other key parts include the MCP6001T-I/OT, SN74LVC2G17DBVR, DRV8833 and MCP16311T-E/MNY. By type, the board carries 88 resistors, 50 capacitors, 22 ICs, 14 diodes, 2 connectors and 2 switches.
It belongs with the robotics & motion designs in this gallery.
From the project
Generate file for jlcpcb production: - Run DRC check - Generating Gerbers - File -> Fabrication Outputs -> Gerbers (.gbr) - Select the folder "build" - Layer selection, List of layers that should be selected: - F.Cu - B.Cu - F.Paste - B.Paste - F.Silkscreen - B.Silkscreen - F.Mas
Generate file for jlcpcb production: - Run DRC check - Generating Gerbers - File -> Fabrication Outputs -> Gerbers (.gbr) - Select the folder "build" - Layer selection, List of layers that should be selected: - F.Cu - B.Cu - F.Paste - B.Paste - F.Silkscreen - B.Silkscreen - F.Mask - B.Mask - Edge.Cuts - (contain the board outline/cutouts.) - Jump to General Options and check these: - Select Plot reference designators, otherwise designators will not appear on silkscreen layers - Select Plot footprint text - Select Check zone fills before plotting - Select Tent vias - Select Use Protel filename…
Main components on the Robot
Robot bill of materials (BOM)
183 components, 31 distinct parts.
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 7 | MCP6001T-I/OT | SOT-23-5 | U101, U511, U521, U531, U541, U551, U561 |
| 1 | ESP32-DEVKITC | ESP32-DevKitC-Left | U102 |
| 1 | ESP32-DEVKITC | ESP32-DevKitC-Right | U103 |
| 9 | SN74LVC2G17DBVR 74LVC2G17 Texas Instruments | SOT-23-6 | U201, U202, U203, U512, U522, U532, U542, U552 +1 |
| 1 | DRV8833 | DVR8833_EVM_IN | U204 |
| 1 | DRV8833 | DVR8833_EVM_OUT | U205 |
| 2 | MCP16311T-E/MNY MCP16311MNY Microchip | TDFN-8-1EP_3x2mm_P0.5mm_EP1.60x1.50mm | U401, U402 |
| 1 | AO3414 N-MOSFET ALPHA & OMEGA SEMICONDUCTOR | SOT-23 | Q101 |
| 1 | TYPE-C 6P LT-10.5 USB_C_Receptacle_PowerOnly_6P SHOU HAN | USB_C_Receptacle_SHOU-HAN_TYPE-C-6P-LT-10.5 | J105 |
| 1 | Conn_01x06 | PinSocket_1x06_P2.54mm_Vertical | J301 |
| 1 | QMB-09B-03 Buzzer Jiangsu Huaneng Elec | MagneticBuzzer_PUI_AT-0927-TT-6-R | BZ101 |
| 1 | Fuse | Fuse_1206_3216Metric | F401 |
| 1 | SW_DIP_x01 | SW_DIP_SPSTx01_Slide_9.78x4.72mm_W7.62mm_P2.54mm | SW101 |
| 1 | SS-12F45-G040 SW_SPDT G-Switch | SW_Slide_1P2T_SS-12F45 | SW102 |
| 8 | PMEG1020EH Nexperia | D_SOD-123F | D101, D102, D511, D521, D531, D541, D551, D561 |
| 4 | KP-2012SYCK LED Jaune KINGBRIGHT ELECTRONIC | LED_0805_2012Metric | D201, D202, D203, D204 |
| 1 | KP-2012MGC LED Verte KINGBRIGHT ELECTRONIC | LED_0805_2012Metric | D205 |
| 1 | KP-2012SURCK LED Rouge KINGBRIGHT ELECTRONIC | LED_0805_2012Metric | D206 |
| 1 | 22µH | L_KOHERelec_MDA-7050 | L411 |
| 1 | 15µH | L_KOHERelec_MDA-7050 | L412 |
Show 11 more
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 28 | 100n Kyocera or Samsung | C_0805_2012Metric | C101, C102, C103, C201, C202, C203, C301, C302 +20 |
| 8 | 10u Kyocera or Samsung | C_1210_3225Metric | C411, C412, C415, C416, C421, C422, C425, C426 |
| 14 | 1u Kyocera or Samsung | C_0805_2012Metric | C413, C423, C514, C515, C524, C525, C534, C535 +6 |
| 29 | 10k KOA or Vishay or PANASONIC | R_0805_2012Metric | R101, R105, R109, R204, R206, R207, R209, R211 +21 |
| 45 | 1k KOA or Vishay or PANASONIC | R_0805_2012Metric | R102, R104, R201, R202, R203, R205, R208, R210 +37 |
| 3 | 0R KOA or Vishay or PANASONIC | R_0805_2012Metric | R103, R413, R423 |
| 2 | 5.1k 1% KOA or Vishay or PANASONIC | R_0805_2012Metric | R106, R107 |
| 1 | 22k KOA or Vishay or PANASONIC | R_0805_2012Metric | R108 |
| 6 | 200R KOA or Vishay or PANASONIC | R_0805_2012Metric | R301, R302, R303, R304, R305, R306 |
| 1 | 52.3k KOA or Vishay or PANASONIC | R_0805_2012Metric | R411 |
| 1 | 31.6k KOA or Vishay or PANASONIC | R_0805_2012Metric | R421 |
Robot design files
The KiCad project lives in the jgraulle/robot-pcb repository on GitHub; these links point at the commit this page was built from.
- Layoutrobot-5A.kicad_pcb
- Schematicrobot-5A.kicad_sch
Robot: common questions
What microcontroller does the Robot use?
The Robot is built around the ESP32-DEVKITC, from the ESP32 family.
How big is the Robot PCB?
The Robot measures 100 × 100 mm, has 2 copper layers and is 1.6 mm thick.
How many components are on the Robot?
183 components, from 31 distinct parts. The full bill of materials is listed on this page.
Where can I download the Robot design files?
From the jgraulle/robot-pcb repository on GitHub, which has the KiCad layout and the schematic; the links under Design files point to each one.
Can I use the Robot design in my own project?
The repository has no license, so all rights stay with jgraulle. Use it as a reference, and ask the author before reusing the design.
Can I test firmware for the Robot without the hardware?
Yes. HardLabs builds a simulation of the board from its netlist and BOM, so you can run and debug ESP32 firmware against it before you order a PCB.
Similar boards
 ESP32
Open Book Abridged Edition
joeycastillo
85 × 115 mm65 parts2LCC-BY-SA-4.08.1k ESP32
Badge
atopile
56.3 × 39 mm239 parts4LMIT4.0k ESP32
Esp32 minimal
36.2 × 26.8 mm20 parts2LMIT4.0k ESP32
Racer
StuckAtPrototype
36 × 50.2 mm70 parts4LApache-2.03.8k ESP32
Controller
29 × 74 mm58 parts4LApache-2.03.8k ESP32
Bitaxe
skot
56.5 × 99.8 mm86 parts4LCERN-OHL-S-2.01.4k