
Cm4-robo controller

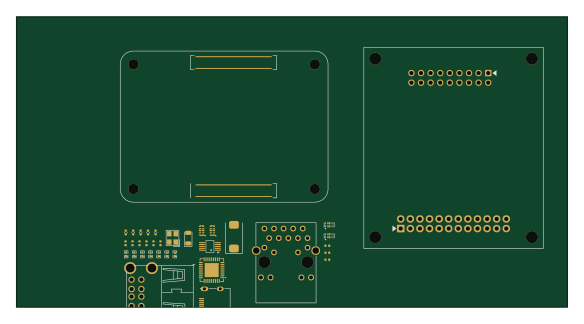
About the Cm4-robo controller PCB
Cm4-robo controller is an open source Raspberry Pi PCB design by jrseti, published on GitHub under the CC0-1.0 license. It is a 2-layer board measuring 145.8 × 76.9 mm, with 49 components from 26 distinct parts.
Its main chip is the ComputeModule4-CM4, from the Raspberry Pi family. Other key parts include the RoboClaw 2x15A OEM, TPD4EUSB30DQAR-N, FSUSB42MUX, USB2514B-I/M2 and AP22653W6-7. By type, the board carries 17 capacitors, 17 resistors, 8 ICs, 1 crystal, 1 LED and 1 diode.
From the project
Simple controller with toggle switches to move the dish motors
This repository contains hardware and firmware work for refurbishing a legacy 3-meter satellite dish into a modern, networked robotic system.
The design is split into two PCB projects that work together over CAN:
The main motion-control and compute board for the dish.
- STM32-based two-axis motion controller - On-board Raspberry Pi Compute Module 4 carrier - Power, I/O, communications, and safety/control interfaces - KiCad hardware design plus associated embedded/software assets
Main components on the Cm4-robo controller
Cm4-robo controller bill of materials (BOM)
49 components, 26 distinct parts.
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 1 | RoboClaw 2x15A OEM ROBOCLAW-2X15A-OEM Basicmicro | MOD-TH_ROBOCLAW-OEM-2X15A | U1 |
| 2 | TPD4EUSB30DQAR-N BORN(伯恩半导体) | DFN-10_L2.5-W1.0-P0.50-BL-A | U2, U6 |
| 1 | FSUSB42MUX onsemi(安森美) | MSOP-10_L3.0-W3.0-P0.50-LS5.0-BL | U3 |
| 1 | USB2514B-I/M2 MICROCHIP(美国微芯) | SQFN-36_L6.0-W6.0-P0.50-BL-EP | U4 |
| 1 | AP22653W6-7 DIODES(美台) | SOT-23-6_L2.9-W1.6-P0.95-LS2.8-BR | U5 |
| 2 | TPD4EUSB30DQAR TI(德州仪器) | USON-10_L2.5-W1.0-P0.50-BL | U7, U8 |
| 1 | X322524MOB4SI YXC(扬兴晶振) | CRYSTAL-SMD_4P-L3.2-W2.5-BL | X1 |
| 1 | ComputeModule4-CM4 | Raspberry-Pi-4-Compute-Module | Module1 |
| 1 | LPJG0926HENL LPJG0926HENL_C22457393 LINK-PP(连普科技) | RJ45-TH_LPJG0926HENL_C22457393 | RJ1 |
| 1 | 907-111A1022D10200 Double layer DIP 90° black 精拓金 | USB-A-TH_USB-M-51 | USB1 |
| 1 | TYPE-C-31-M-12 韩国韩荣 | USB-C_SMD-TYPE-C-31-M-12_1 | USBC1 |
| 1 | KT-0805R RED KENTO | LED0805-R-RD | LED1 |
| 1 | SMF6.0A hongjiacheng | D_SOD-123FL | D1 |
| 2 | 15pF FH(Guangdong Fenghua Advanced Tech) | C_0402 | C1, C4 |
| 7 | CL21B106KPQNNNE 10uF 10V SAMSUNG(三星) | C0805 | C2, C3, C11, C13, C14, C15, C16 |
| 2 | 100nF Samsung Electro-Mechanics | C_0402 | C5, C17 |
| 5 | 100n Samsung Electro-Mechanics | C_0402_1005Metric | C6, C7, C8, C9, C10 |
| 1 | EEFCX0J101R 100uF 6.3V PANASONIC | CP_EIA-7343-31_Kemet-D | C12 |
| 1 | 10kΩ UNI-ROYAL(Uniroyal Elec) | R_0402 | R1 |
| 3 | 100Ω UNI-ROYAL(Uniroyal Elec) | R_0402 | R2, R3, R4 |
Show 6 more
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 3 | 1.5kΩ UNI-ROYAL(Uniroyal Elec) | R_0402 | R5, R16, R17 |
| 2 | 2.2kΩ UNI-ROYAL(Uniroyal Elec) | R0402 | R6, R8 |
| 2 | 5.1kΩ UNI-ROYAL(Uniroyal Elec) | R_0402 | R7, R9 |
| 4 | FRC0402F3602TS 36K 1% FOJAN(富捷) | R0402 | R10, R11, R13, R14 |
| 1 | 12kΩ UNI-ROYAL(Uniroyal Elec) | R0402 | R12 |
| 1 | 15kΩ UNI-ROYAL(Uniroyal Elec) | R_0402 | R15 |
Cm4-robo controller design files
The KiCad project lives in the jrseti/Dish repository on GitHub; these links point at the commit this page was built from.
Cm4-robo controller: common questions
What microcontroller does the Cm4-robo controller use?
The Cm4-robo controller is built around the ComputeModule4-CM4, from the Raspberry Pi family.
How big is the Cm4-robo controller PCB?
The Cm4-robo controller measures 145.8 × 76.9 mm, has 2 copper layers and is 1.6 mm thick.
How many components are on the Cm4-robo controller?
49 components, from 26 distinct parts. The full bill of materials is listed on this page.
Where can I download the Cm4-robo controller design files?
From the jrseti/Dish repository on GitHub, which has the KiCad layout and the schematic; the links under Design files point to each one.
Can I use the Cm4-robo controller design in my own project?
Yes, under the terms of its CC0-1.0 license, which jrseti chose for the repository.
Can I test firmware for the Cm4-robo controller without the hardware?
Yes. HardLabs builds a simulation of the board from its netlist and BOM, so you can run and debug Raspberry Pi firmware against it before you order a PCB.
More boards in Dish
Similar boards
 Raspberry Pi
Open source rover
nasa-jpl
220 × 178 mm144 parts2LApache-2.09.7k Raspberry Pi
SPIRIT
SPIRIT-org
82 × 155 mm130 parts6LCERN-OHL-S-2.01.3k Raspberry Pi
CM5RevEng
schlae
55 × 40 mm417 parts10LNo license1.0k Raspberry Pi
Haxo hw
cardonabits
102.4 × 211.3 mm38 parts2LCustom license672 Raspberry Pi
Desktop 50 Pin TopConn
BlueSCSI
89.2 × 82.6 mm103 parts2LGPL-3.0449 Raspberry Pi
PowerBook
74.5 × 56.3 mm78 parts2LGPL-3.0449