
Flathead robot

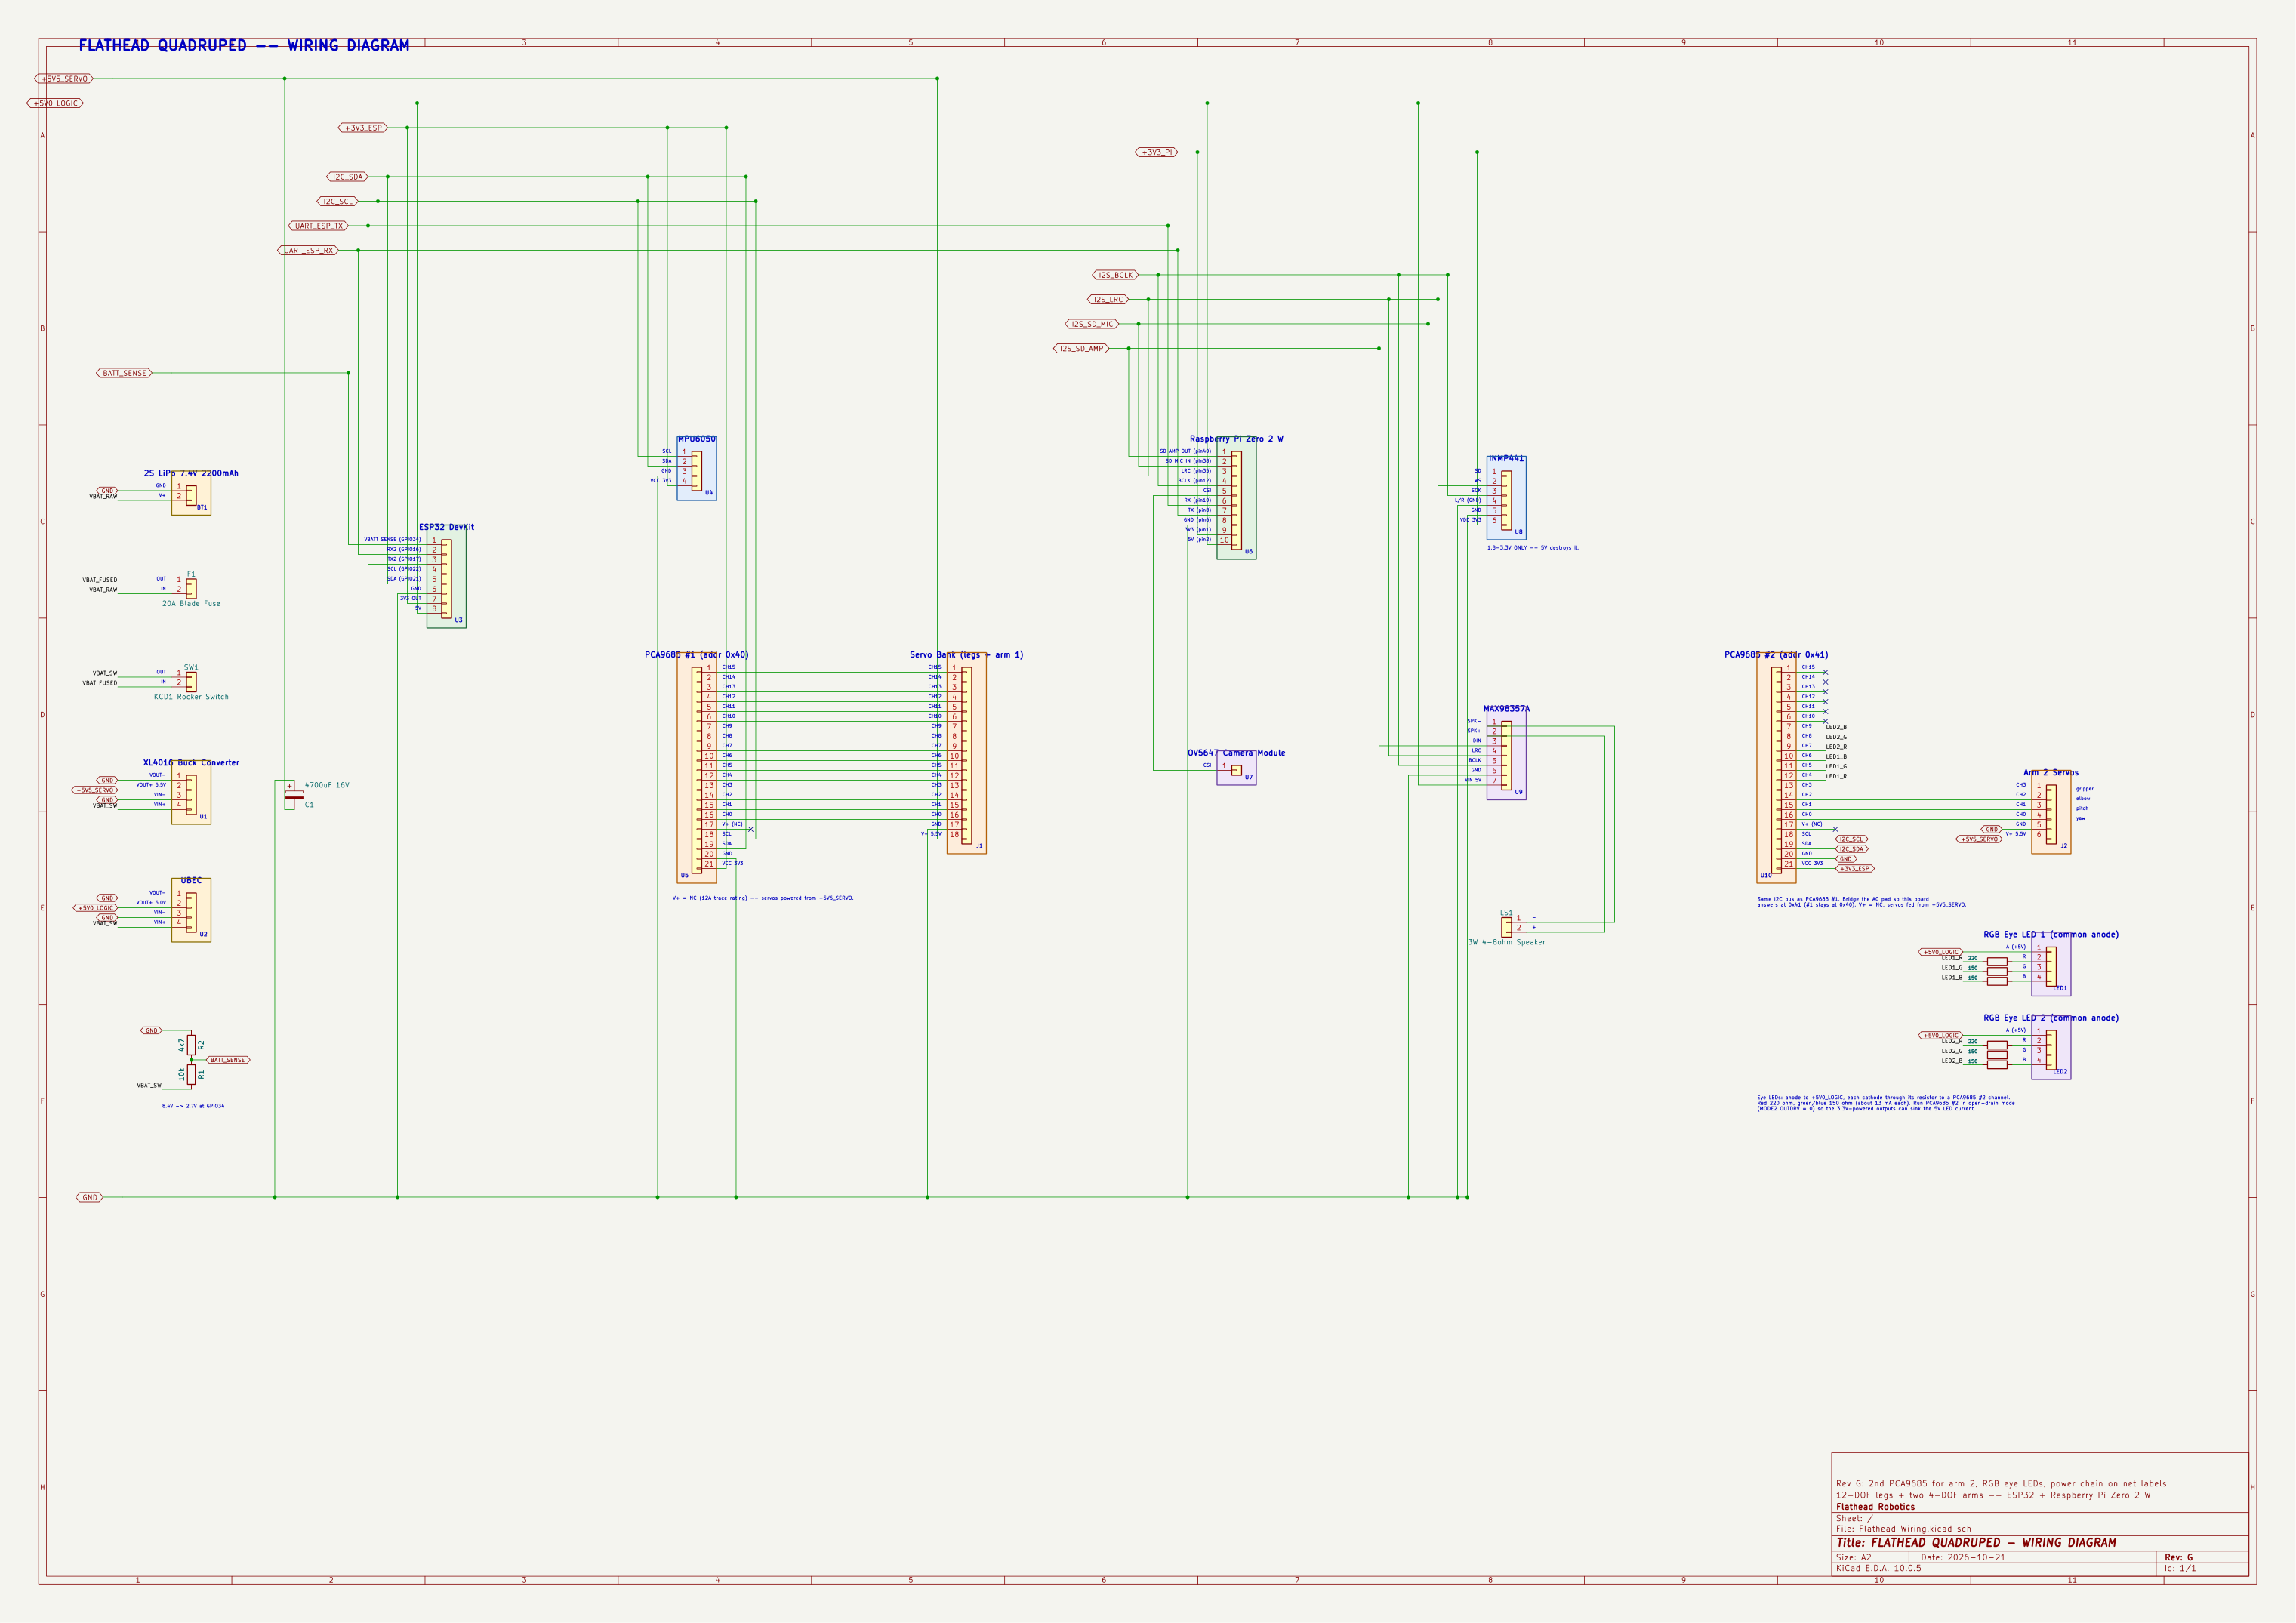
About the Flathead robot PCB
Flathead robot is an open source ESP32 PCB design by michaelsumin78-hue, published on GitHub. It is a board, with 27 components from 23 distinct parts.
Its main chip is the ESP32 DevKit, from the ESP32 family. Other key parts include the XL4016 Buck Converter, UBEC, MPU6050, PCA9685 and Raspberry Pi Zero 2 W. By type, the board carries 10 ICs, 8 resistors, 2 connectors, 2 LEDs, 1 battery holder and 1 fuse.
It belongs with the robotics & motion and power & battery designs in this gallery.
From the project
4 legged robot with autonomous vision based off of the cyberpunk 2077 robot
3D printed Autonomous Quadruped robot using camera vision, all inspired by the Cyberpunk 2077 flathead robot.
https://drive.google.com/file/d/126V4TeB604TGq49DJKtc-aOF2DAQ/view?usp=drive_link
This robot is mainly intended to be used for fun, walking outside or around the house. I also want to potentially make it usable as an AI companion as I want to run a small AI model on the Raspberry Pi Zero so conversations can be held.
Main components on the Flathead robot
Flathead robot bill of materials (BOM)
27 components, 23 distinct parts.
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 1 | XL4016 Buck Converter | U1 | |
| 1 | UBEC | U2 | |
| 1 | ESP32 DevKit | U3 | |
| 1 | MPU6050 | U4 | |
| 1 | PCA9685 | U5 | |
| 1 | Raspberry Pi Zero 2 W | U6 | |
| 1 | OV5647 Camera Module | U7 | |
| 1 | INMP441 | U8 | |
| 1 | MAX98357A | U9 | |
| 1 | PCA9685 #2 | U10 | |
| 1 | Servo Bank | J1 | |
| 1 | Arm 2 Servos | J2 | |
| 1 | 2S LiPo 7.4V 2200mAh | BT1 | |
| 1 | 20A Blade Fuse | F1 | |
| 1 | 3W 4-8ohm Speaker | LS1 | |
| 1 | KCD1 Rocker Switch | SW1 | |
| 1 | RGB Eye LED 1 | LED1 | |
| 1 | RGB Eye LED 2 | LED2 | |
| 1 | 4700uF 16V | C1 | |
| 1 | 10k | R1 |
Show 3 more
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 1 | 4k7 | R2 | |
| 2 | 220 | R3, R6 | |
| 4 | 150 | R4, R5, R7, R8 |
Flathead robot design files
The KiCad project lives in the michaelsumin78-hue/flathead_robot repository on GitHub; these links point at the commit this page was built from.
- Schematicwiring/Flathead_Wiring.kicad_sch
Flathead robot: common questions
What microcontroller does the Flathead robot use?
The Flathead robot is built around the ESP32 DevKit, from the ESP32 family.
How many components are on the Flathead robot?
27 components, from 23 distinct parts. The full bill of materials is listed on this page.
Where can I download the Flathead robot design files?
From the michaelsumin78-hue/flathead_robot repository on GitHub, which has the schematic; the links under Design files point to each one.
Can I use the Flathead robot design in my own project?
The repository has no license, so all rights stay with michaelsumin78-hue. Use it as a reference, and ask the author before reusing the design.
Can I test firmware for the Flathead robot without the hardware?
Yes. HardLabs builds a simulation of the board from its netlist and BOM, so you can run and debug ESP32 firmware against it before you order a PCB.
Similar boards
 ESP32
OSO-BOOK-B1
joeycastillo
85 × 115 mm65 parts2LCC-BY-SA-4.08.1k ESP32
Powertrain
byrantech
64 × 45.4 mm171 parts4LMIT4.3k ESP32
Badge
atopile
56.3 × 39 mm239 parts4LMIT4.0k ESP32
Esp32 minimal
36.2 × 26.8 mm20 parts2LMIT4.0k ESP32
Controller
StuckAtPrototype
29 × 74 mm58 parts4LApache-2.03.8k ESP32
Racer
36 × 50.2 mm70 parts4LApache-2.03.8k