
WRO FE 2026 FoxRobotics

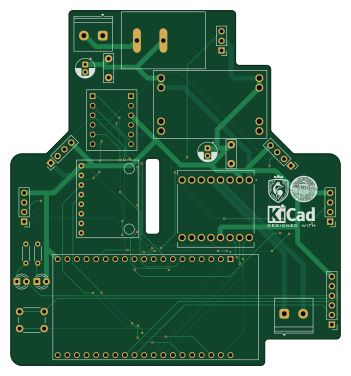
About the WRO FE 2026 FoxRobotics PCB
WRO FE 2026 FoxRobotics is an open source ESP32 PCB design by Nakashima26, published on GitHub under the MIT license. It is a 2-layer board measuring 87.2 × 93.9 mm, with 20 components from 15 distinct parts.
Its main chip is the ESP32-DEVKITC-32D, from the ESP32 family. Other key parts include the ROB-14450, BOB-12009 and MPU6050. By type, the board carries 4 ICs, 4 capacitors, 3 connectors, 2 switches and 2 resistors.
It belongs with the sensors designs in this gallery.
From the project
CETYS Mexicali WRO2026 FoxRobotics Team
1. Vehicle Overview - 1.1 Design goals · 1.2 Bill of Materials 2. Mechanical Design & Mobility - 2.1 Chassis selection · 2.2 Wheels · 2.3 Drive system (torque vs. speed) · 2.4 Steering · 2.5 Custom parts & assembly 3. Power Architecture & Sensors - 3.1 Power budget · 3.2 Sensor selection and placement · 3.3 PCB & wiring 4. Software Architecture - 4.1 System overview · 4.2 Inter-controller protocol ("V2") · 4.3 Vision pipeline · 4.4 Obstacle handling · 4.5 ESP32 state machine · 4.6 Cascade PID · 4.7 Startup handshake · 4.8 Development status 5. Systemic Thinking & Engineering Decisions - 5.1…
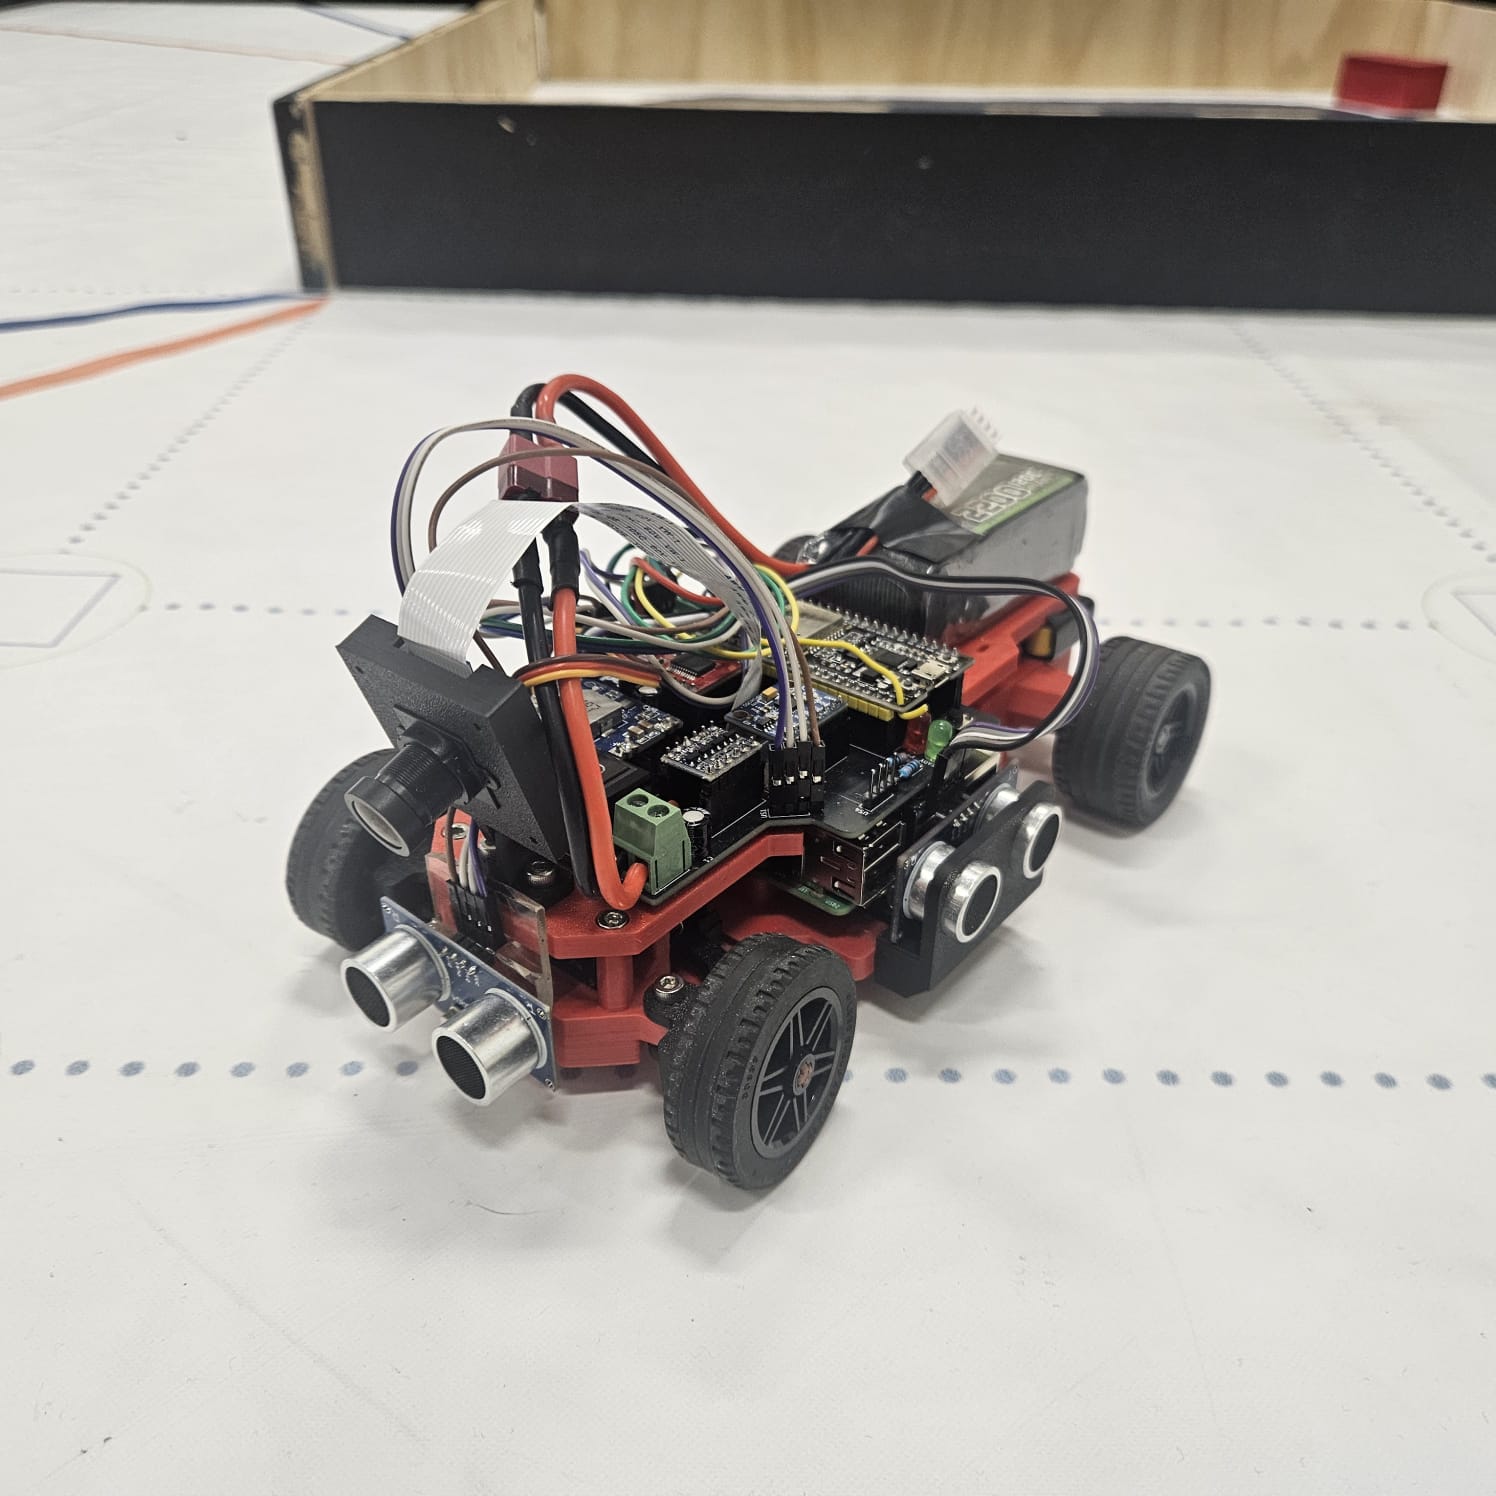
Main components on the WRO FE 2026 FoxRobotics
WRO FE 2026 FoxRobotics bill of materials (BOM)
20 components, 15 distinct parts.
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 1 | ESP32-DEVKITC-32D | ESP32-DEVKITC-32D | U1 |
| 1 | ROB-14450 | MODULE_ROB-14450 | U2 |
| 1 | BOB-12009 | CONV_BOB-12009 | U3 |
| 1 | MPU6050 | module_mpu6050 | U4 |
| 1 | VCC | TerminalBlock_Phoenix_PT-1,5-2-5.0-H_1x02_P5.00mm_Horizontal | J1 |
| 1 | SERVO | PinHeader_1x03_P2.54mm_Vertical | J4 |
| 1 | MOTOR | TerminalBlock_Phoenix_PT-1,5-2-5.0-H_1x02_P5.00mm_Horizontal | J5 |
| 1 | V1 | Mini560 | MINI560 |
| 1 | EXEC_PRGM | SW_PUSH_6mm | SW1 |
| 1 | HX KCD1-2P-X PWR hanxia(韩下) | SW-TH_L22.2-W15.0-P7.00_KCD1-2P-P | SW2 |
| 4 | ULTRASONIC | PinHeader_1x04_P2.54mm_Vertical | US1, US2, US3, US4 |
| 1 | 470uF | CP_Radial_D5.0mm_P2.00mm | C1 |
| 2 | 0.1uF | C_Disc_D7.5mm_W2.5mm_P5.00mm | C2, C4 |
| 1 | 100uF | CP_Radial_D5.0mm_P2.00mm | C3 |
| 2 | 330 | R_Axial_DIN0204_L3.6mm_D1.6mm_P5.08mm_Horizontal | R1, R2 |
WRO FE 2026 FoxRobotics design files
The KiCad project lives in the Nakashima26/WRO_FE_2026_FoxRobotics repository on GitHub; these links point at the commit this page was built from.
WRO FE 2026 FoxRobotics: common questions
What microcontroller does the WRO FE 2026 FoxRobotics use?
The WRO FE 2026 FoxRobotics is built around the ESP32-DEVKITC-32D, from the ESP32 family.
How big is the WRO FE 2026 FoxRobotics PCB?
The WRO FE 2026 FoxRobotics measures 87.2 × 93.9 mm, has 2 copper layers and is 1.6 mm thick.
How many components are on the WRO FE 2026 FoxRobotics?
20 components, from 15 distinct parts. The full bill of materials is listed on this page.
Where can I download the WRO FE 2026 FoxRobotics design files?
From the Nakashima26/WRO_FE_2026_FoxRobotics repository on GitHub, which has the KiCad layout and the schematic; the links under Design files point to each one.
Can I use the WRO FE 2026 FoxRobotics design in my own project?
Yes, under the terms of its MIT license, which Nakashima26 chose for the repository.
Can I test firmware for the WRO FE 2026 FoxRobotics without the hardware?
Yes. HardLabs builds a simulation of the board from its netlist and BOM, so you can run and debug ESP32 firmware against it before you order a PCB.
Similar boards
 ESP32
Open Book Abridged Edition
joeycastillo
85 × 115 mm65 parts2LCC-BY-SA-4.08.1k ESP32
Badge
atopile
56.3 × 39 mm239 parts4LMIT4.0k ESP32
Esp32 minimal
36.2 × 26.8 mm20 parts2LMIT4.0k ESP32
Racer
StuckAtPrototype
36 × 50.2 mm70 parts4LApache-2.03.8k ESP32
Controller
29 × 74 mm58 parts4LApache-2.03.8k ESP32
Bitaxe
skot
56.5 × 99.8 mm86 parts4LCERN-OHL-S-2.01.4k