
Arm drive

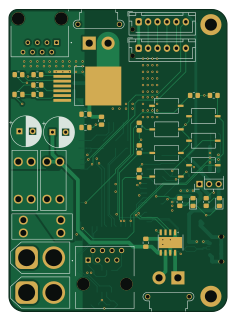
About the Arm drive PCB
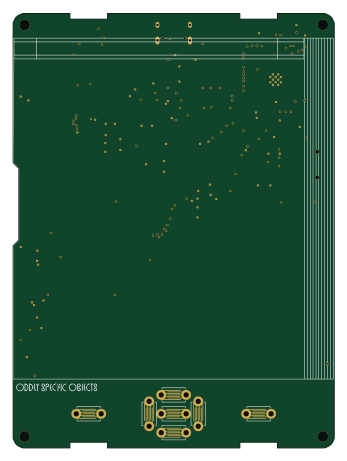
Arm drive is an open source ESP32 PCB design by robotique-udes, published on GitHub under the MIT license. It is a 4-layer board measuring 57.8 × 80 mm, with 66 components from 43 distinct parts.
Its main chip is the 1028-RT6285GSP, from the ESP32 family. Other key parts include the RT8258GJ6, KSZ8567STXI-, 296-50412-1, 296-TLV1117LV12DCYR and 296-26344-1. By type, the board carries 23 capacitors, 14 resistors, 10 ICs, 7 connectors, 7 switches and 3 fuses.
From the project
Ce répertoire contient les projets du rover, les projets sont trié par version du rover:
Main components on the Arm drive
Arm drive bill of materials (BOM)
66 components, 43 distinct parts — part numbers from the project's BOM.
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 1 | RT8258GJ6 150-SMDB03CE3/TR7TR-ND | SOIC-8-1EP_3.9x4.9mm_P1.27mm_EP2.29x3mm | U1 |
| 1 | KSZ8567STXI- SN65HVD232Q | SOIC127P600X175-8N | U2 |
| 1 | 296-50412-1 LM7805MPX/NOPB | SOT-223-3_TabPin2 | U3 |
| 1 | 296-TLV1117LV12DCYR DRV8251A | Texas_HSOP-8-1EP_3.9x4.9mm_P1.27mm_ThermalVias | U4 |
| 1 | 1028-RT6285GSP ESP32-S3-WROOM-1 | ESP32-S3-WROOM-1 | U5 |
| 1 | 296-26344-1 XT60PM-M | AMASS_XT60-M_1x02_P7.20mm_Vertical | U6 |
| 1 | 1965-ESP32-S3FN8 BTN8962TA | PG-TO263-7-1_INF-M | U7 |
| 1 | BTN8962TA | PG-TO263-7-1_INF-M | U8 |
| 1 | AZ1117CH2-3.3TRG1 | SOT-223-3_TabPin2 | U9 |
| 1 | XT60PM-M | AMASS_XT60-M_1x02_P7.20mm_Vertical | U10 |
| 1 | RJ45 | ASSMANN_A-2014-2-4-N-T-R | J1 |
| 1 | USB_B_Micro | USB_Micro-B_Amphenol_10118193-0001LF_Horizontal | J2 |
| 1 | RJ45 | AMPHENOL_54601-908WPLF | J3 |
| 2 | ~ | JST_XH_B6B-XH-AM_1x06_P2.50mm_Vertical | J6, J7 |
| 2 | XT30PW-F | AMASS_XT30PW-F_1x02_P2.50mm_Horizontal | J9, J10 |
| 1 | 25A | FUSE_3568-20 | F1 |
| 1 | 20A | FUSE_3568-20 | F2 |
| 1 | 4A | FUSE_3568-20 | F3 |
| 2 | CKN12215-1 TS09-63-25-WT-160-SMT-TR | SW_TS09-63-25_CUD | SW1, SW2 |
| 5 | TS09-63-25-WT-160-SMT-TR | SW_TS09-63-25_CUD | SW3, SW4, SW5, SW6, SW7 |
Show 23 more
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 1 | 641-1271-1 R | LED_0805_2012Metric_Pad1.15x1.40mm_HandSolder | D1 |
| 1 | 641-1271-1 G | LED_0805_2012Metric_Pad1.15x1.40mm_HandSolder | D2 |
| 1 | 478-KGM15AR51E103KT 100nF | C_0805_2012Metric_Pad1.18x1.45mm_HandSolder | C1 |
| 1 | 490-10515-1 10uF | C_0805_2012Metric_Pad1.18x1.45mm_HandSolder | C2 |
| 1 | 1276-6780-1 100nF | C_0805_2012Metric_Pad1.18x1.45mm_HandSolder | C3 |
| 6 | 1276-1935-2 100nF | C_0805_2012Metric_Pad1.18x1.45mm_HandSolder | C4, C7, C10, C11, C19, C21 |
| 5 | 1276-1935-2 220nF | C_0805_2012Metric_Pad1.18x1.45mm_HandSolder | C5, C9, C12, C13, C14 |
| 1 | 399-C1206C102KGRAC7800 22uF | C_0805_2012Metric_Pad1.18x1.45mm_HandSolder | C6 |
| 1 | 1276-1935-2 1uF | C_0805_2012Metric_Pad1.18x1.45mm_HandSolder | C8 |
| 2 | 1276-1935-2 470uF | CP_Radial_D8.0mm_P3.50mm | C15, C20 |
| 1 | 1276-1274-1 1nF | C_0805_2012Metric_Pad1.18x1.45mm_HandSolder | C16 |
| 1 | 4713-GMC10X5R106M10NT 100nF | C_0805_2012Metric_Pad1.18x1.45mm_HandSolder | C17 |
| 1 | 1276-1935-2 1nF | C_0805_2012Metric_Pad1.18x1.45mm_HandSolder | C18 |
| 1 | 1276-1935-2 10uF | C_0805_2012Metric_Pad1.18x1.45mm_HandSolder | C22 |
| 1 | 1276-1935-2 22uF | C_0805_2012Metric_Pad1.18x1.45mm_HandSolder | C23 |
| 2 | 311-10.0KHR 1k | R_0805_2012Metric_Pad1.20x1.40mm_HandSolder | R1, R10 |
| 1 | 311-75.0HR 1k | R_0805_2012Metric_Pad1.20x1.40mm_HandSolder | R2 |
| 1 | 311-75.0HR 10K | R_0805_2012Metric_Pad1.20x1.40mm_HandSolder | R3 |
| 2 | 311-1.00KHR 3.3k | R_0805_2012Metric_Pad1.20x1.40mm_HandSolder | R4, R5 |
| 1 | 311-10.0KHR 3.3k | R_0805_2012Metric_Pad1.20x1.40mm_HandSolder | R6 |
| 4 | 311-10.0KHR 10k | R_0805_2012Metric_Pad1.20x1.40mm_HandSolder | R7, R9, R11, R12 |
| 1 | 311-750HR 1k | R_0805_2012Metric_Pad1.20x1.40mm_HandSolder | R13 |
| 2 | 311-750HR 3.3k | R_0805_2012Metric_Pad1.20x1.40mm_HandSolder | R14, R15 |
Arm drive design files
The KiCad project lives in the robotique-udes/PCB repository on GitHub; these links point at the commit this page was built from.
Arm drive: common questions
What microcontroller does the Arm drive use?
The Arm drive is built around the 1028-RT6285GSP, from the ESP32 family.
How big is the Arm drive PCB?
The Arm drive measures 57.8 × 80 mm, has 4 copper layers and is 1.6 mm thick.
How many components are on the Arm drive?
66 components, from 43 distinct parts, with part numbers taken from the project's own BOM. The full bill of materials is listed on this page.
Where can I download the Arm drive design files?
From the robotique-udes/PCB repository on GitHub, which has the KiCad layout, the schematic and the BOM; the links under Design files point to each one.
Can I use the Arm drive design in my own project?
Yes, under the terms of its MIT license, which robotique-udes chose for the repository.
Can I test firmware for the Arm drive without the hardware?
Yes. HardLabs builds a simulation of the board from its netlist and BOM, so you can run and debug ESP32 firmware against it before you order a PCB.
More boards in PCB
 ESP32
DDB
152.8 × 53.5 mm106 parts4LMIT0 ESP32
Pdb
96.5 × 97.9 mm92 parts4LMIT0 ESP32
Science module
100 × 72.5 mm71 parts4LMIT0 ESP32
Arm drive jl
80 × 50 mm60 parts4LMIT0 ESP32
Arm drive j3 4 5
90 × 50 mm59 parts4LMIT0 ESP32
Gripper 2024
59.5 × 90 mm57 parts4LMIT0 ESP32
Arm drive j2
38 × 76 mm55 parts4LMIT0 ESP32
Drive 27A
32.5 × 59.3 mm50 parts4LMIT0 ESP32
AntenneMotorisé
100 × 70 mm39 parts4LMIT0
PCB BioGenius
124.5 × 94 mm19 parts2LMIT0
BNO BREAKOUT
31.4 × 49 mm11 parts2LMIT0
Similar boards
 ESP32
Open Book Abridged Edition
joeycastillo
85 × 115 mm65 parts2LCC-BY-SA-4.08.1k ESP32
Badge
atopile
56.3 × 39 mm239 parts4LMIT4.0k ESP32
Esp32 minimal
36.2 × 26.8 mm20 parts2LMIT4.0k ESP32
Racer
StuckAtPrototype
36 × 50.2 mm70 parts4LApache-2.03.8k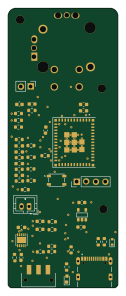 ESP32
Controller
29 × 74 mm58 parts4LApache-2.03.8k ESP32
Bitaxe
skot
56.5 × 99.8 mm86 parts4LCERN-OHL-S-2.01.4k