
Arm drive j3 4 5

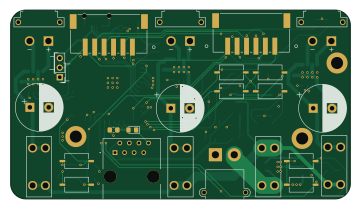
About the Arm drive j3 4 5 PCB
Arm drive j3 4 5 is an open source ESP32 PCB design by robotique-udes, published on GitHub under the MIT license. It is a 4-layer board measuring 90 × 50 mm, with 59 components from 36 distinct parts.
Its main chip is the 296-26344-1, from the ESP32 family. Other key parts include the RT8258GJ6, KSZ8567STXI-, 296-50412-1, 296-TLV1117LV12DCYR and 1028-RT6285GSP. By type, the board carries 17 capacitors, 12 resistors, 9 connectors, 8 ICs, 8 switches and 4 fuses.
From the project
Ce répertoire contient les projets du rover, les projets sont trié par version du rover:
Main components on the Arm drive j3 4 5
Arm drive j3 4 5 bill of materials (BOM)
59 components, 36 distinct parts — part numbers from the project's BOM.
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 1 | RT8258GJ6 ~ | SOIC-8-1EP_3.9x4.9mm_P1.27mm_EP2.29x3mm | U1 |
| 1 | KSZ8567STXI- SN65HVD232QDRQ1 | SOIC127P600X175-8N | U2 |
| 1 | 296-50412-1 AZ1117CH2-3.3TRG1 | SOT-223-3_TabPin2 | U3 |
| 1 | 296-TLV1117LV12DCYR DRV8251 | Texas_HSOP-8-1EP_3.9x4.9mm_P1.27mm_ThermalVias | U4 |
| 1 | 1028-RT6285GSP DRV8251 | Texas_HSOP-8-1EP_3.9x4.9mm_P1.27mm_ThermalVias | U5 |
| 1 | 296-26344-1 ESP32-S3-WROOM-1 | ESP32-S3-WROOM-1 | U6 |
| 1 | 1965-ESP32-S3FN8 DRV8251 | Texas_HSOP-8-1EP_3.9x4.9mm_P1.27mm_ThermalVias | U7 |
| 1 | LM7805MPX/NOPB | SOT-223-3_TabPin2 | U8 |
| 1 | USB_B_Micro | USB_Micro-B_Amphenol_10118193-0001LF_Horizontal | J1 |
| 1 | RJ45 | AMPHENOL_54601-908WPLF | J2 |
| 3 | XT30PW-F | AMASS_XT30PW-F | J3, J4, J7 |
| 3 | ~ | CONN_S6B-XH-SM4-TB_JST | J5, J8, J9 |
| 1 | XT30PW-M | AMASS_XT30PW-M_1x02_P2.50mm_Horizontal | J6 |
| 3 | 4A | FUSE_3568-20 | F1, F2, F3 |
| 1 | 9A | FUSE_3568-20 | F4 |
| 2 | CKN12215-1 TS09-63-25-WT-160-SMT-TR | SW_TS09-63-25_CUD | SW1, SW2 |
| 6 | TS09-63-25-WT-160-SMT-TR | SW_TS09-63-25_CUD | SW3, SW4, SW5, SW6, SW7, SW8 |
| 1 | 641-1271-1 G | LED_0805_2012Metric_Pad1.15x1.40mm_HandSolder | D2 |
| 1 | 478-KGM15AR51E103KT 100nF | C_0805_2012Metric_Pad1.18x1.45mm_HandSolder | C1 |
| 1 | 490-10515-1 100nF | C_0805_2012Metric_Pad1.18x1.45mm_HandSolder | C2 |
Show 16 more
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 1 | 1276-6780-1 10uF | C_0805_2012Metric_Pad1.18x1.45mm_HandSolder | C3 |
| 4 | 1276-1935-2 100nF | C_0805_2012Metric_Pad1.18x1.45mm_HandSolder | C4, C8, C10, C18 |
| 1 | 1276-1935-2 10uF | C_0805_2012Metric_Pad1.18x1.45mm_HandSolder | C5 |
| 1 | 399-C1206C102KGRAC7800 100nF | C_0805_2012Metric_Pad1.18x1.45mm_HandSolder | C6 |
| 3 | 1276-1935-2 470uF | CP_Radial_D12.5mm_P5.00mm | C7, C9, C11 |
| 1 | 1276-1935-2 22uF | C_0805_2012Metric_Pad1.18x1.45mm_HandSolder | C12 |
| 1 | 1276-1935-2 220nF | C_0805_2012Metric_Pad1.18x1.45mm_HandSolder | C13 |
| 1 | 4713-GMC10X5R106M10NT 22uF | C_0805_2012Metric_Pad1.18x1.45mm_HandSolder | C17 |
| 1 | 1276-1935-2 1uF | C_0805_2012Metric_Pad1.18x1.45mm_HandSolder | C19 |
| 1 | 1276-1935-2 47nF | C_0805_2012Metric_Pad1.18x1.45mm_HandSolder | C20 |
| 6 | 311-10.0KHR 3.3k | R_0805_2012Metric_Pad1.20x1.40mm_HandSolder | R1, R6, R7, R9, R10, R11 |
| 1 | 311-75.0HR 1k | R_0805_2012Metric_Pad1.20x1.40mm_HandSolder | R2 |
| 1 | 311-75.0HR 60 | R_0805_2012Metric_Pad1.20x1.40mm_HandSolder | R3 |
| 1 | 311-1.00KHR 60 | R_0805_2012Metric_Pad1.20x1.40mm_HandSolder | R4 |
| 2 | 311-1.00KHR 3.3k | R_0805_2012Metric_Pad1.20x1.40mm_HandSolder | R5, R8 |
| 1 | 311-750HR 10k | R_0805_2012Metric_Pad1.20x1.40mm_HandSolder | R13 |
Arm drive j3 4 5 design files
The KiCad project lives in the robotique-udes/PCB repository on GitHub; these links point at the commit this page was built from.
Arm drive j3 4 5: common questions
What microcontroller does the Arm drive j3 4 5 use?
The Arm drive j3 4 5 is built around the 296-26344-1, from the ESP32 family.
How big is the Arm drive j3 4 5 PCB?
The Arm drive j3 4 5 measures 90 × 50 mm, has 4 copper layers and is 1.6 mm thick.
How many components are on the Arm drive j3 4 5?
59 components, from 36 distinct parts, with part numbers taken from the project's own BOM. The full bill of materials is listed on this page.
Where can I download the Arm drive j3 4 5 design files?
From the robotique-udes/PCB repository on GitHub, which has the KiCad layout, the schematic and the BOM; the links under Design files point to each one.
Can I use the Arm drive j3 4 5 design in my own project?
Yes, under the terms of its MIT license, which robotique-udes chose for the repository.
Can I test firmware for the Arm drive j3 4 5 without the hardware?
Yes. HardLabs builds a simulation of the board from its netlist and BOM, so you can run and debug ESP32 firmware against it before you order a PCB.
More boards in PCB
 ESP32
DDB
152.8 × 53.5 mm106 parts4LMIT0 ESP32
Pdb
96.5 × 97.9 mm92 parts4LMIT0 ESP32
Science module
100 × 72.5 mm71 parts4LMIT0 ESP32
Arm drive
57.8 × 80 mm66 parts4LMIT0 ESP32
Arm drive jl
80 × 50 mm60 parts4LMIT0 ESP32
Gripper 2024
59.5 × 90 mm57 parts4LMIT0 ESP32
Arm drive j2
38 × 76 mm55 parts4LMIT0 ESP32
Drive 27A
32.5 × 59.3 mm50 parts4LMIT0 ESP32
AntenneMotorisé
100 × 70 mm39 parts4LMIT0
PCB BioGenius
124.5 × 94 mm19 parts2LMIT0
BNO BREAKOUT
31.4 × 49 mm11 parts2LMIT0
Similar boards
 ESP32
Open Book Abridged Edition
joeycastillo
85 × 115 mm65 parts2LCC-BY-SA-4.08.1k ESP32
Badge
atopile
56.3 × 39 mm239 parts4LMIT4.0k ESP32
Esp32 minimal
36.2 × 26.8 mm20 parts2LMIT4.0k ESP32
Racer
StuckAtPrototype
36 × 50.2 mm70 parts4LApache-2.03.8k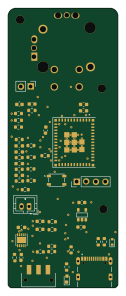 ESP32
Controller
29 × 74 mm58 parts4LApache-2.03.8k ESP32
Bitaxe
skot
56.5 × 99.8 mm86 parts4LCERN-OHL-S-2.01.4k