
Robot

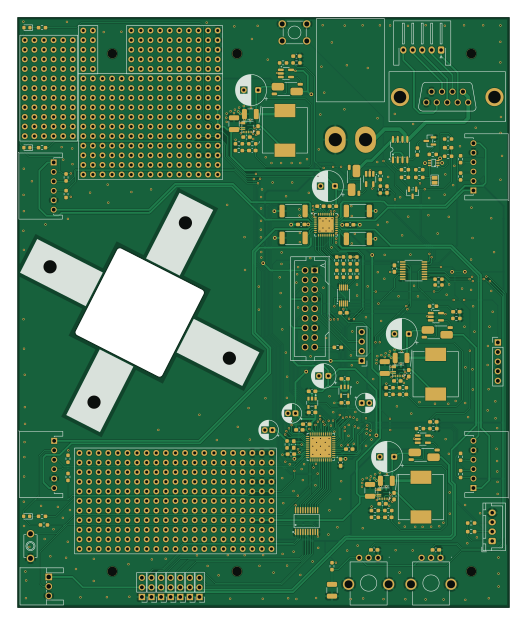
About the Robot PCB
Robot is an open source FPGA PCB design by roman-khvatov, published on GitHub under the MIT license. It is a 2-layer board measuring 130 × 156 mm, with 161 components from 68 distinct parts.
Its main chip is the C2678152, from the FPGA family. Other key parts include the SN74LVC1G14DBV, MaixCAM2, C20345375, 74HCT245 and MCP4728. By type, the board carries 62 resistors, 53 capacitors, 18 connectors, 16 ICs, 4 diodes and 3 inductors.
It belongs with the robotics & motion designs in this gallery.
From the project
Кружок робототехники RoboWay
Мы запускаем образовательный кружок робототехники RoboWay для подростков в возрасте от 12 до 18 лет (возможны исключения в зависимости от подготовки ребенка). Цель кружка — дать учащимся фундаментальные знания в области электроники, программирования и робототехники.
В отличие от большинства кружков, где используются готовые наборы и работа сводится к сборке по инструкции, в RoboWay участники будут разрабатывать и изготавливать роботов с нуля. Мы стремимся к тому, чтобы дети осознанно подходили к техническому творчеству и понимали принципы работы систем, а не просто следовали пошаговым…
Main components on the Robot
Robot bill of materials (BOM)
161 components, 68 distinct parts — part numbers from the project's BOM.
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 1 | SN74LVC1G14DBV ADC128D818 | TSSOP-16_4.4x5mm_P0.65mm | U1 |
| 1 | MaixCAM2 | CONN-TH_18P-P2.54_B18B-XADSS-N-LF-SN | U2 |
| 1 | C20345375 DRV8845RHHR | VQFN-36_L6.0-W6.0-P0.50-TL-EP4.1 | U3 |
| 1 | C2678152 ICE40UP5K-SG48ITR | QFN-48-1EP_7x7mm_P0.5mm_EP5.6x5.6mm | U4 |
| 1 | 74HCT245 | TSSOP-20_L6.5-W4.4-P0.65-LS6.4-BL | U5 |
| 1 | MCP4728 | MSOP-10_3x3mm_P0.5mm | U6 |
| 1 | NC7SZ175 | SC-70-6_L2.0-W1.3-P0.65-LS2.1-BL | U7 |
| 1 | TLV70212DBVR | SOT-23-5_L3.0-W1.7-P0.95-LS2.8-BL | U8 |
| 1 | TMI6050-33 | SOT-23-5_L2.9-W1.6-P0.95-LS2.8-BR | U9 |
| 3 | SY8366HQQC silergy(矽力杰) | QFN-12_L3.0-W3.0-P0.45-TL-EP | U10, U11, U12 |
| 4 | INA180A2 | SOT-23-5_HandSoldering | U13, U14, U15, U16 |
| 1 | DMP3036SSD | SO-8_L4.9-W3.9-P1.27-LS5.9-BL | Q1 |
| 1 | Si2003 | SOT-23 | Q2 |
| 1 | CONN_01X03_PIN Servo1 | PinHeader_1x03_P2.54mm_Vertical | J1 |
| 1 | Servo2 | PinHeader_1x03_P2.54mm_Vertical | J2 |
| 1 | Servo3 | PinHeader_1x03_P2.54mm_Vertical | J3 |
| 1 | Servo4 | PinHeader_1x03_P2.54mm_Vertical | J4 |
| 1 | Servo5 | PinHeader_1x03_P2.54mm_Vertical | J5 |
| 1 | Servo6 | PinHeader_1x03_P2.54mm_Vertical | J6 |
| 1 | Servo7 | PinHeader_1x03_P2.54mm_Vertical | J7 |
Show 48 more
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 1 | Beacon | JST_XH_B4B-XH-A_1x04_P2.50mm_Vertical | J8 |
| 1 | DLED | CONN-TH_S3B-XH-A-1-LF-SN | J9 |
| 1 | Lidar | PinHeader_1x05_P2.54mm_Vertical | J10 |
| 1 | Console | PinHeader_1x04_P2.54mm_Vertical | J11 |
| 1 | M1 | CONN-TH_S6B-XH-A-LF-SN | J12 |
| 1 | M2 | CONN-TH_S6B-XH-A-LF-SN | J13 |
| 1 | M3 | CONN-TH_S6B-XH-A-LF-SN | J14 |
| 1 | M4 | CONN-TH_S6B-XH-A-LF-SN | J15 |
| 1 | Battery | TRX | J16 |
| 1 | DE9_Receptacle | DSUB-TH_DMS009PM000XH00 | J17 |
| 1 | Balance | JST_XH_S5B-XH-A-1_1x05_P2.50mm_Horizontal | J18 |
| 1 | Off | SolderJumper-2_P1.3mm_Open_Pad1.0x1.5mm | JP1 |
| 1 | User | KEY-TH_2P-L6.0-W3.5-P6.50 | SW1 |
| 1 | Pwr | KEY-TH_4P-L6.0-W6.0-P4.50-LS6.50 | SW2 |
| 3 | C2286 KT-0603R | LED_0603_1608Metric | D1, D2, D3 |
| 1 | BAT54C | SOT-23 | D4 |
| 3 | C2835875 CDRH127L125NP-4R7NC (4u7) | IND-SMD_L12.0-W12.0_CDRH127XX | L1, L2, L3 |
| 1 | 1.0 | C_0603_1608Metric_Pad1.08x0.95mm_HandSolder | C1 |
| 20 | 1.0 | C_0603_1608Metric_Pad1.08x0.95mm_HandSolder | C2, C8, C9, C10, C11, C12, C13, C14 +12 |
| 4 | 470x16V | CP_Radial_D8.0mm_P3.80mm | C3, C27, C33, C39 |
| 2 | 10n | C_0603_1608Metric_Pad1.08x0.95mm_HandSolder | C4, C5 |
| 1 | 22n | C_0603_1608Metric_Pad1.08x0.95mm_HandSolder | C6 |
| 1 | 0.22 | C_0603_1608Metric_Pad1.08x0.95mm_HandSolder | C7 |
| 2 | 10x16V | CP_Radial_D5.0mm_P2.00mm | C15, C18 |
| 1 | 100x16V | CP_Radial_D6.3mm_P2.50mm | C20 |
| 1 | 20x16V | CP_Radial_D5.0mm_P2.00mm | C24 |
| 3 | C | C_0603_1608Metric_Pad1.08x0.95mm_HandSolder | C25, C31, C37 |
| 3 | 22.0 | C_1210_3225Metric_Pad1.33x2.70mm_HandSolder | C26, C32, C38 |
| 7 | 2.2 | C_0603_1608Metric_Pad1.08x0.95mm_HandSolder | C28, C34, C40, C43, C45, C47, C49 |
| 4 | 10.0 | C_1210_3225Metric_Pad1.33x2.70mm_HandSolder | C29, C35, C41, C51 |
| 3 | 0.1 | C_0603_1608Metric_Pad1.08x0.95mm_HandSolder | C30, C36, C42 |
| 1 | 820K 5K1 | R_0603_1608Metric_Pad0.98x0.95mm_HandSolder | R1 |
| 1 | 5K1 | R_0603_1608Metric_Pad0.98x0.95mm_HandSolder | R2 |
| 17 | 10K | R_0603_1608Metric_Pad0.98x0.95mm_HandSolder | R3, R19, R20, R21, R22, R23, R24, R25 +9 |
| 4 | C7420023 FRM252WJR220TK (0.22) | R_2512_6332Metric_Pad1.40x3.35mm_HandSolder | R4, R5, R6, R7 |
| 3 | ~ | R_0603_1608Metric_Pad0.98x0.95mm_HandSolder | R8, R9, R10 |
| 8 | NP | R_0603_1608Metric_Pad0.98x0.95mm_HandSolder | R11, R12, R13, R14, R15, R16, R17, R18 |
| 1 | 1M | R_0603_1608Metric_Pad0.98x0.95mm_HandSolder | R27 |
| 3 | 1K | R_0603_1608Metric_Pad0.98x0.95mm_HandSolder | R28, R56, R60 |
| 2 | 100K | R_0603_1608Metric_Pad0.98x0.95mm_HandSolder | R29, R30 |
| 4 | 100 | R_0603_1608Metric_Pad0.98x0.95mm_HandSolder | R31, R57, R58, R59 |
| 5 | R | R_0603_1608Metric_Pad0.98x0.95mm_HandSolder | R32, R35, R38, R61, R62 |
| 3 | 110K | R_0603_1608Metric_Pad0.98x0.95mm_HandSolder | R33, R36, R39 |
| 3 | 15K | R_0603_1608Metric_Pad0.98x0.95mm_HandSolder | R34, R37, R40 |
| 4 | 0.018 | R_Shunt_Vishay_WSK2512_6332Metric_T2.21mm | R41, R44, R47, R50 |
| 1 | 3K7 | R_0603_1608Metric_Pad0.98x0.95mm_HandSolder | R53 |
| 1 | RK09K1130A6S RK09K1130A6S (10K) ALPSALPINE(阿尔卑斯阿尔派) | RES-TH_RK09K1130A6S | R54 |
| 1 | RK09K1130A6S ALPSALPINE(阿尔卑斯阿尔派) | RES-TH_RK09K1130A6S | R55 |
Robot design files
The KiCad project lives in the roman-khvatov/RoboWay repository on GitHub; these links point at the commit this page was built from.
Robot: common questions
What microcontroller does the Robot use?
The Robot is built around the C2678152, from the FPGA family.
How big is the Robot PCB?
The Robot measures 130 × 156 mm, has 2 copper layers and is 1.6 mm thick.
How many components are on the Robot?
161 components, from 68 distinct parts, with part numbers taken from the project's own BOM. The full bill of materials is listed on this page.
Where can I download the Robot design files?
From the roman-khvatov/RoboWay repository on GitHub, which has the KiCad layout, the schematic and the BOM; the links under Design files point to each one.
Can I use the Robot design in my own project?
Yes, under the terms of its MIT license, which roman-khvatov chose for the repository.
Can I test firmware for the Robot without the hardware?
Yes. HardLabs builds a simulation of the board from its netlist and BOM, so you can run and debug FPGA firmware against it before you order a PCB.
More boards in RoboWay
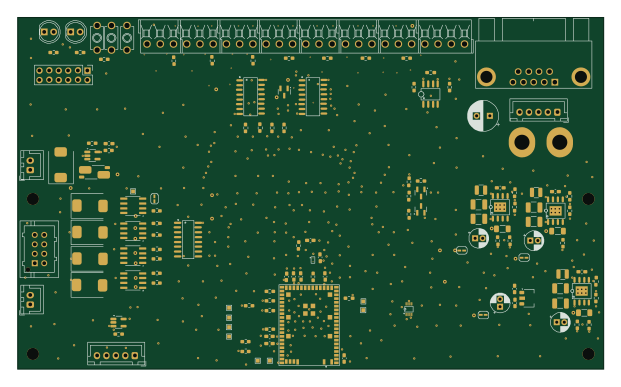
Main ext
155 × 93 mm165 parts4LMIT1
Generic
108.2 × 114.7 mm154 parts2LMIT1
Main int
135 × 85 mm151 parts4LMIT1 RISC-V
Tetris
33 × 91.7 mm76 parts4LMIT1
Extension
73 × 50 mm56 parts2LMIT1
Powmeter
27.3 × 59.7 mm38 parts2LMIT1
Panel
117 × 78 mm37 parts2LMIT1
Ledflash
22.9 × 33.7 mm25 parts2LMIT1
But1
37 × 106 mm23 parts2LMIT1
Btns
40 × 122 mm21 parts2LMIT1
Similar boards
 FPGA
Base board
GlasgowEmbedded
80 × 49 mm222 parts4L0BSD2.2k FPGA
Thunderscope Rev5.3
EEVengers
122.5 × 103.5 mm817 parts6LMIT1.3k FPGA
Usb sniffer
ataradov
58.2 × 38.1 mm86 parts2LBSD-3-Clause1.3k FPGA
Tomu, I'm
theacodes
13 × 9.4 mm40 parts4LMIT1.1k FPGA
Icepi zero
cheyao
65 × 30 mm143 parts4LSHL-2.1828 FPGA
Sd2snes
mrehkopf
101.5 × 83 mm147 partsGPL-2.0717