
Pilot — EMI-Hardened Flight Control & Sensor Cape

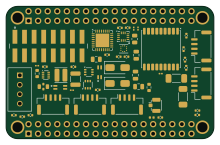
About the Pilot — EMI-Hardened Flight Control & Sensor Cape PCB
Pilot — EMI-Hardened Flight Control & Sensor Cape is an open source PCB design by Stab-Rabbit-coding, published on GitHub under the CERN-OHL-W-2.0 license. It is a 6-layer board measuring 55 × 35 mm, with 96 components from 35 distinct parts.
Other key parts include the TPS62933DRLR. By type, the board carries 57 capacitors, 16 resistors, 4 crystals, 2 inductors, 1 IC and 1 transformer.
It belongs with the sensors designs in this gallery.
From the project
A functional, security conscious, Unmanned Aerial Vehicle based on the Firefly Class spacecraft Serenity from the 2002 show..
This directory holds the KiCad projects for the four cape/board types:
Per-board net/pin documentation lives in the matching .md files (Pilot.md, TACCO.md, FlightEngineer.md, XCVR-49MHZ-2.md). KiCad files keep KiCad board coordinates (documented exception to the hull-frame standard, see root AGENTS.md).
A pass was made to wire in a second Ethernet channel and to clear the Design-Rule-Check (DRC) and ratsnest issues introduced by a manual component rearrangement. This section records exactly what landed and what is still open, so the thread can be picked up cleanly.
Main components on the Pilot — EMI-Hardened Flight Control & Sensor Cape
Pilot — EMI-Hardened Flight Control & Sensor Cape bill of materials (BOM)
96 components, 35 distinct parts — part numbers from the project's BOM.
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 1 | TPS62933DRLR | SOT-583-8 | U-3V3 |
| 2 | CX0805MRX7R0BB472 4.7nF X2Y | X2Y_0805_4T | X2Y-CAN, X2Y-RS485 |
| 1 | ECS-2520MV-250-BN-TR 25MHz 3.3V | Oscillator_SMD_ECS_2520MV-xxx-xx-4Pin_2.5x2.0mm | X-25M |
| 1 | ECS-2520MV-500-BN-TR 50MHz 3.3V | Oscillator_SMD_ECS_2520MV-xxx-xx-4Pin_2.5x2.0mm | X-50M |
| 1 | HI-6138PCIF | Holt_HI-6138_QFN-48_6x6mm_P0.4mm_EP4.6mm | 1553-XCVR |
| 1 | PM-DB2791S | Xfmr_1553_SMD_0.40in_8pin | 1553-XFM |
| 1 | SRF2012-121YA SRF2012-100Y | Bourns_SRF2012_4T | CMC-RS485 |
| 4 | SM04B-GHS-TB(LF)(SN) SM04B-GHS-TB | JST_GH_SM04B-GHS-TB_1x04-1MP_P1.25mm_Horizontal | ETH1, ETH2, MIL-1553, RS-485 |
| 2 | DP83825IRMQR | Texas_RMQ0024A_WQFN-24-1EP_3x3mm_P0.4mm_EP1.9x1.9mm | ETH1-PHY, ETH2-PHY |
| 1 | PB2I-P1-2x18 | PocketBeagle2_2x18_P1_Socket | PB2-P1 |
| 1 | PB2I-P2-2x18 | PocketBeagle2_2x18_P2_Socket | PB2-P2 |
| 1 | ISOW1412DFMR | SOIC-20W_7.5x12.8mm_P1.27mm | RS485 |
| 1 | 749010012A | Wurth_749010012A_WE-LAN | T-ETH2 |
| 2 | SMAJ33CA | D_SMA | TVS-1553N, TVS-1553P |
| 1 | PRTR5V0U2X,115 PRTR5V0U2X | SOT-363_SC-70-6 | TVS-RS485 |
| 1 | 742792512 | L_0805_2012Metric | FB1 |
| 1 | 74438335033 3.3uH 2.25A | L_WE-MAPI_3015 | L-3V3 |
| 26 | 100nF | C_0402_1005Metric | C-3V3-HF, C-25M, C-50M, C-485-3, C-485-6, C-1553A, C-1553B, C-1553D +18 |
| 6 | 10uF 10V X5R | C_0805_2012Metric | C-3V3-IN, C-485-2, C-485-5, C-CAN2, C-CAN5, C-IN2 |
| 2 | 22uF 6.3V X5R | C_0805_2012Metric | C-3V3-O1, C-3V3-O2 |
Show 15 more
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 9 | 10nF | C_0201_0603Metric | C-485-1, C-485-4, C-CAN1, C-CAN4, C-IMU2, C-P1-A1, C-P1-IO1, C-P2-A1 +1 |
| 2 | 10uF 6.3V X5R | C_0805_2012Metric | C-1553C, C-GPS1 |
| 2 | 10nF 2kV | C_1808_4520Metric | C-BS1, C-BS2 |
| 1 | 47uF 10V X5R | C_1210_3225Metric | C-IN1 |
| 9 | 1uF | C_0402_1005Metric | C-P1-A3, C-P1-CRD2, C-P1-CTD2, C-P1-IO3, C-P2-A3, C-P2-CRD2, C-P2-CTD2, C-P2-IO3 +1 |
| 1 | 120R | R_0603_1608Metric | R-485T |
| 1 | 10k | R_0402_1005Metric | R-1553IRQ |
| 2 | 55R 2% | R_0603_1608Metric | R-1553N, R-1553P |
| 4 | 75R | R_0402_1005Metric | R-BS1R, R-BS1T, R-BS2R, R-BS2T |
| 1 | 100k | R_0201_0603Metric | R-EN3 |
| 1 | 100k 1% | R_0201_0603Metric | R-FB3H |
| 1 | 32.4k 1% | R_0201_0603Metric | R-FB3L |
| 2 | 2.49k | R_0201_0603Metric | R-P1-AD0, R-P2-AD0 |
| 2 | 6.49k 1% | R_0201_0603Metric | R-P1-RBIAS, R-P2-RBIAS |
| 1 | 10k | R_0201_0603Metric | R-TPM10 |
Pilot — EMI-Hardened Flight Control & Sensor Cape design files
The KiCad project lives in the Stab-Rabbit-coding/Serenity-UAV repository on GitHub; these links point at the commit this page was built from.
Pilot — EMI-Hardened Flight Control & Sensor Cape: common questions
How big is the Pilot — EMI-Hardened Flight Control & Sensor Cape PCB?
The Pilot — EMI-Hardened Flight Control & Sensor Cape measures 55 × 35 mm, has 6 copper layers and is 1.6 mm thick.
How many components are on the Pilot — EMI-Hardened Flight Control & Sensor Cape?
96 components, from 35 distinct parts, with part numbers taken from the project's own BOM. The full bill of materials is listed on this page.
Where can I download the Pilot — EMI-Hardened Flight Control & Sensor Cape design files?
From the Stab-Rabbit-coding/Serenity-UAV repository on GitHub, which has the KiCad layout, the schematic and the BOM; the links under Design files point to each one.
Can I use the Pilot — EMI-Hardened Flight Control & Sensor Cape design in my own project?
Yes, under the terms of its CERN-OHL-W-2.0 license, which Stab-Rabbit-coding chose for the repository.
More boards in Serenity-UAV
Flight Engineer — Power Distribution Board
90 × 65 mm115 parts4LCERN-OHL-W-2.01
TACCO — Comms / Logging / Payload Cape
55 × 35 mm108 parts6LCERN-OHL-W-2.01
Observer
69.9 × 56.4 mm43 parts4LCERN-OHL-W-2.01
XCVR-49MHZ-2 EMI-Hardened 49 MHz AX.25 KISS Transceiver
55 × 35 mm41 parts4LCERN-OHL-W-2.01
CAN-PERIPH-GW-1 / MAL-CAN-PERIPH-GW
64.3 × 19.5 mm39 parts2LCERN-OHL-W-2.01
ENC-NACELLE-1 / SKIPPER-TILT-ENC
7 × 14 mm4 parts2LCERN-OHL-W-2.01
Similar boards
Sensor smd
scottbez1
40 × 20 mm5 parts2LApache-2.04.2k
Sensors
StuckAtPrototype
15.2 × 9 mm14 parts4LApache-2.03.8k
Microphone
Mentra-Community
5.5 × 6.1 mm6 parts2LMIT1.2k
TemperaturePCB PANEL
stuartpittaway
116 × 75.5 mm178 parts2LCC-BY-NC-4.01.1k
Pots
shanteacontrols
390 × 93 mm75 parts2LApache-2.0956
ButtonsLEDs
390 × 37 mm82 parts2LApache-2.0956