
UTDRoboSubCompute

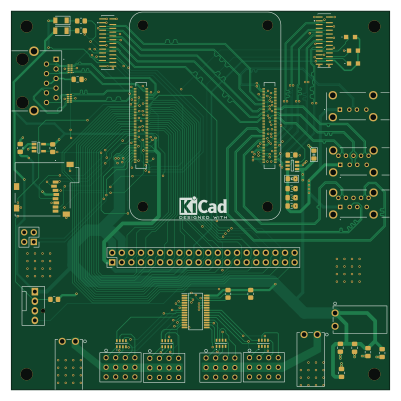
About the UTDRoboSubCompute PCB
UTDRoboSubCompute is an open source Raspberry Pi PCB design by WilliamDATaylor, published on GitHub under the MIT license. It is a 4-layer board measuring 100 × 100.1 mm, with 51 components from 28 distinct parts.
Its main chip is the ComputeModule5-CM5, from the Raspberry Pi family. Other key parts include the TPD4E05U06QDQARQ1, RT9742GGJ5, AP22653W6-7 and PCA9685PW,118. By type, the board carries 17 connectors, 14 resistors, 12 capacitors, 5 ICs and 2 LEDs.
It belongs with the dev boards & breakouts and robotics & motion designs in this gallery.
From the project
cm5 carrier board for the UTD RoboSub Team
This will compete in the 2026 MateROV competition.
Designs are heavily influenced by the reference RPI CM5 IO board.
1. Servo Controller 2. GPIO Pins 3. CSI/DSI 4. SD Card boot 5. Power Inputs 6. USB 2.0 7. USB 3.0 8. CM5 9. Fan 10. Sizing and dimensions 11. Trace Routing 12. Additional Details
Internally connected to GPIO 2 & GPIO 3 (I2c1). Info here
The Servo controller is on the x0 I2c address

Main components on the UTDRoboSubCompute
UTDRoboSubCompute bill of materials (BOM)
51 components, 28 distinct parts.
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 2 | TPD4E05U06QDQARQ1 | DQA_R-PUSON-N10_ | IC1, IC2 |
| 1 | RT9742GGJ5 | SOT94P280X100-5N | U2 |
| 1 | AP22653W6-7 | SOT95P280X145-6N | U3 |
| 1 | PCA9685PW,118 | SOP65P640X110-28N | U4 |
| 1 | Disable Bluetooth/Wifi | PinHeader_2x02_P2.54mm_Vertical | J1 |
| 1 | GSB191217FHR | GSB191217FHR | J2 |
| 1 | ARJM11B1-502-NN-EW2 | ARJM11B1502NNEW2 | J3 |
| 1 | GTFP08432B1HR | GTFP08432B1HR | J4 |
| 1 | Fan_Header | FanPinHeader_1x04_P2.54mm_Vertical | J5 |
| 3 | Wago connector 2091-1372 | CONN2_2091-1372_WAGO | J6, J7, J8 |
| 4 | HEADER-3X04 | CON12_3X4_TU_TSW_SAI | J9, J10, J11, J12 |
| 1 | Conn_02x20_Odd_Even | PinHeader_2x20_P2.54mm_Vertical | J13 |
| 2 | GSB3116344KHHR | GSB3116344KHHR | J14, J15 |
| 2 | TF38-22S-0.5SV(830) TF38-22S-0.5SV_830_ | TF3822S05SV830 | J16, J17 |
| 1 | ComputeModule5-CM5 | Raspberry-Pi-5-Compute-Module | Module1 |
| 1 | 150120GS75000 | LEDC3214X68N | Act1 |
| 1 | 150120RS75000 | LEDC3216X68N | Pwr1 |
| 1 | 0.1u | C_0805_2012Metric_Pad1.18x1.45mm_HandSolder | C1 |
| 5 | 10u | C_0805_2012Metric_Pad1.18x1.45mm_HandSolder | C2, C3, C5, C6, C7 |
| 1 | 100u | C_0805_2012Metric_Pad1.18x1.45mm_HandSolder | C4 |
Show 8 more
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 3 | ~ | C_0805_2012Metric_Pad1.18x1.45mm_HandSolder | C8, C9, C10 |
| 2 | 0.1u | C_0805_2012Metric_Pad1.15x1.40mm_HandSolder | C11, C12 |
| 3 | 2.2K | ERJS06_U06__0805_ | R1, R2, R11 |
| 1 | 150 | R_0805_2012Metric_Pad1.20x1.40mm_HandSolder | R3 |
| 4 | 10k | R_0805_2012Metric_Pad1.20x1.40mm_HandSolder | R4, R5, R6, R8 |
| 1 | 90 | R_0805_2012Metric_Pad1.20x1.40mm_HandSolder | R9 |
| 1 | 12K | R_0805_2012Metric_Pad1.20x1.40mm_HandSolder | R10 |
| 4 | 220 | CAT161000F4 | RN1, RN2, RN3, RN4 |
UTDRoboSubCompute design files
The KiCad project lives in the WilliamDATaylor/UTDRoboSubCompute repository on GitHub; these links point at the commit this page was built from.
- LayoutUTDRoboSubCompute.kicad_pcb
- SchematicUTDRoboSubCompute.kicad_sch
UTDRoboSubCompute: common questions
What microcontroller does the UTDRoboSubCompute use?
The UTDRoboSubCompute is built around the ComputeModule5-CM5, from the Raspberry Pi family.
How big is the UTDRoboSubCompute PCB?
The UTDRoboSubCompute measures 100 × 100.1 mm, has 4 copper layers and is 1.6 mm thick.
How many components are on the UTDRoboSubCompute?
51 components, from 28 distinct parts. The full bill of materials is listed on this page.
Where can I download the UTDRoboSubCompute design files?
From the WilliamDATaylor/UTDRoboSubCompute repository on GitHub, which has the KiCad layout and the schematic; the links under Design files point to each one.
Can I use the UTDRoboSubCompute design in my own project?
Yes, under the terms of its MIT license, which WilliamDATaylor chose for the repository.
Can I test firmware for the UTDRoboSubCompute without the hardware?
Yes. HardLabs builds a simulation of the board from its netlist and BOM, so you can run and debug Raspberry Pi firmware against it before you order a PCB.
Similar boards
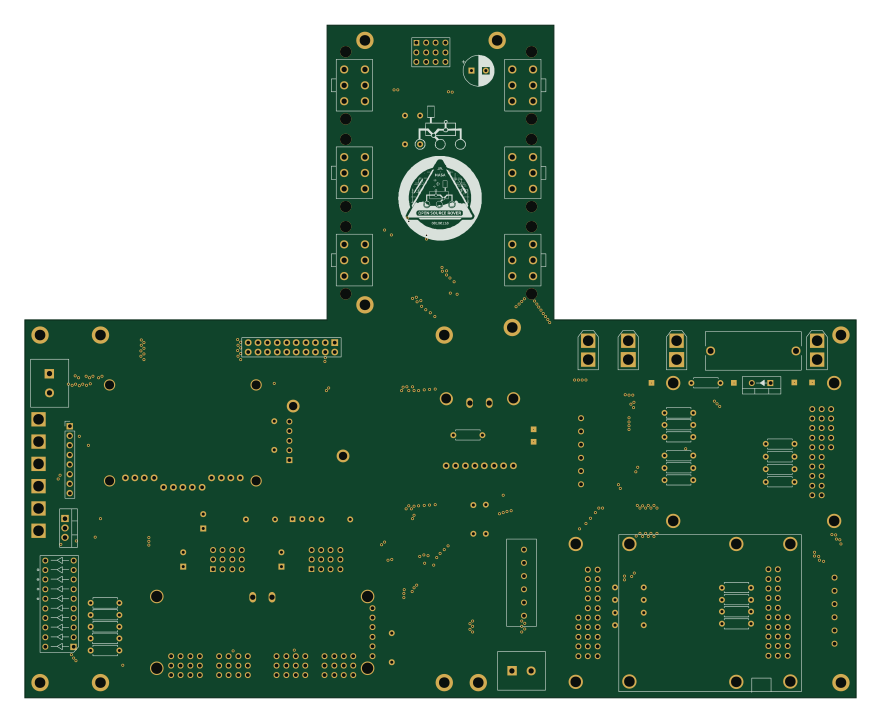 Raspberry Pi
Open source rover
nasa-jpl
220 × 178 mm144 parts2LApache-2.09.7k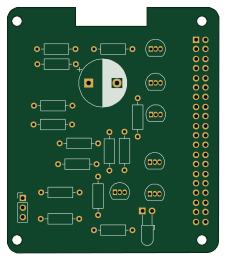 Raspberry Pi
Iot
dotnet
56 × 65 mm24 parts2LMIT2.4k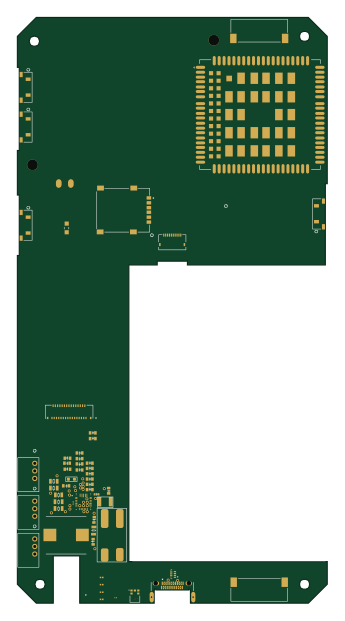 Raspberry Pi
SPIRIT
SPIRIT-org
82 × 155 mm130 parts6LCERN-OHL-S-2.01.3k Raspberry Pi
CM5RevEng
schlae
55 × 40 mm417 parts10LNo license1.0k Raspberry Pi
Haxo hw
cardonabits
102.4 × 211.3 mm38 parts2LCustom license673 Raspberry Pi
Phased
Neumi
75 × 100 mm71 parts2LNo license507