
Hyper Wheel base

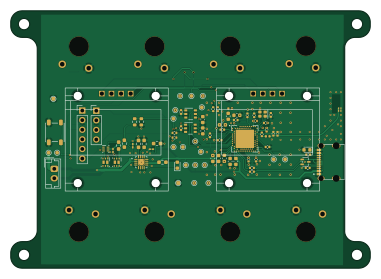
About the Hyper Wheel base PCB
Hyper Wheel base is an open source Nordic nRF PCB design by AnotherBuildCorner, published on GitHub. It is a 4-layer board measuring 95 × 68 mm, with 75 components from 46 distinct parts.
Its main chip is the NRF52840-QIAA-R7, from the Nordic nRF family. Other key parts include the CSD85301Q2, AS5600L-ASOM, TPS22916CNYFPR, BQ29700DSER and BQ24074RGTR. By type, the board carries 26 capacitors, 15 ICs, 4 connectors, 4 inductors, 2 jumpers and 2 switches.
It belongs with the displays & leds, power & battery and keyboards designs in this gallery.
From the project
A programmable HID control interface that replaces discrete key presses with continuous rotary input, enabling precise, context-aware interaction for workflows like video editing and CAD.
A programmable HID control interface that replaces discrete key presses with continuous rotary input, enabling precise, context-aware interaction for workflows like video editing and CAD.
- 4-layer mixed-signal embedded system (98 × 65 mm) based on nRF52840 (BLE + USB HID) - RF-aware PCB layout with calculated 50Ω antenna trace on TG155 FR4 - Battery-powered architecture (LiPo + charger + protection + load switching) - Multi-bus I²C system separating OLED displays and encoders for signal integrity - Designed within JLCPCB DFM constraints (no blind vias, optimized BOM, 0402/0603 preference) -…
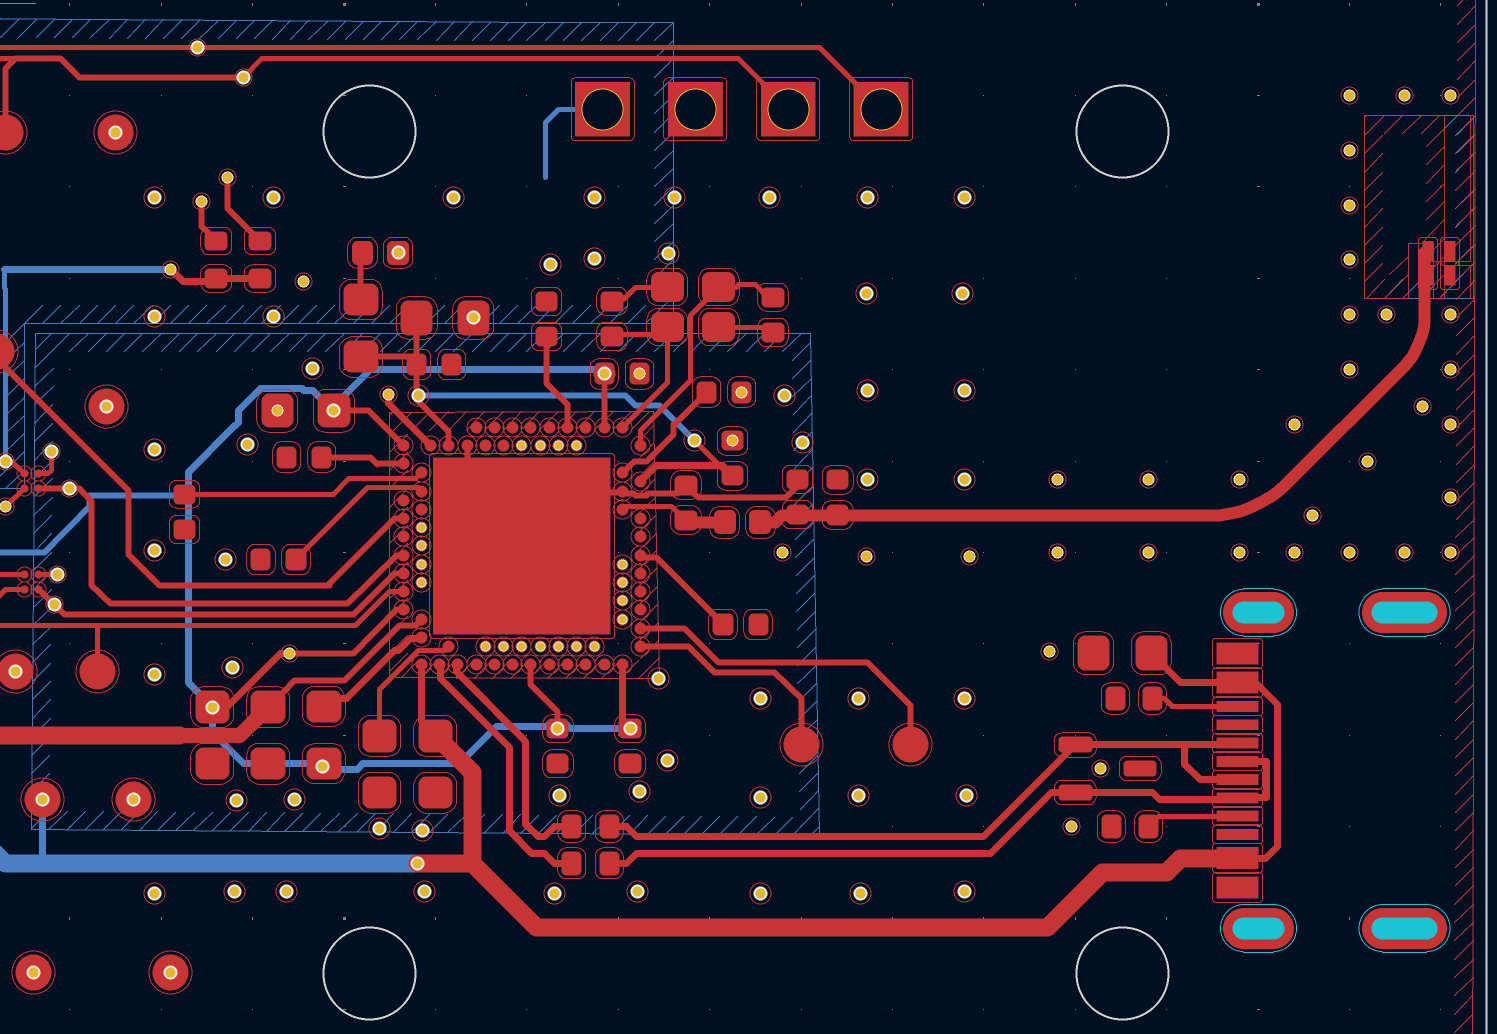
Main components on the Hyper Wheel base
Hyper Wheel base bill of materials (BOM)
75 components, 46 distinct parts — part numbers from the project's BOM.
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 2 | CSD85301Q2 | CDS85301-DQK0006B | U1, U9 |
| 1 | NRF52840-QIAA-R7 | NORDIC_NRF52840-QIAA-R7 | U2 |
| 2 | AS5600L-ASOM | AS5600L-ASOM_AMS | U3, U13 |
| 2 | TPS22916CNYFPR | DBV0006A_L | U4, U10 |
| 1 | BQ29700DSER | BQ29700-DSE0006A | U6 |
| 1 | BQ24074RGTR | BQ24074-QFN50P300X300X100-17N | U7 |
| 2 | DRV5032FCDBZR | DRV5032-DBZ0003A-IPC_A | U8, U14 |
| 1 | TPD2EUSB30ADRTR | SOT-323_SC-70 | U11 |
| 2 | ~ | OLED 128x64 | U15, U16 |
| 1 | 2450AT07A0100T | 2450AT07A0100T_JOT+Keepout | U17 |
| 1 | 32MHZ 32MHz | Crystal_SMD_2016-4Pin_2.0x1.6mm | Y1 |
| 1 | Conn_01x06_Socket | PinHeader_1x06_P2.54mm_Vertical | J1-1 |
| 1 | LIPO | JST_EH_B2B-EH-A_1x02_P2.50mm_Vertical | J2 |
| 1 | Conn_01x04_Socket | PinHeader_1x04_P2.54mm_Vertical | J2-1 |
| 1 | USB4215-03-A | USBC-CONN_8p94X6p5X3p16_12L_GCC | J3 |
| 1 | 0.1U 0.1u | C_0201_0603Metric_Pad0.64x0.40mm_HandSolder | CP1 |
| 1 | 1u | C_0201_0603Metric_Pad0.64x0.40mm_HandSolder | CP2 |
| 1 | 4.7U 4.7u | C_0201_0603Metric_Pad0.64x0.40mm_HandSolder | CP3 |
| 2 | JUMPER_2_OPEN Jumper_2_Open | SolderJumper-2_P1.3mm_Open_Pad1.0x1.5mm | JP1, JP2 |
| 2 | 5.1K 5.1k | R_0402_1005Metric | RCC1, RCC2 |
Show 26 more
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 4 | 4.7K 4.7k | R_0402_1005Metric | RD1, RD2, RS1, RS2 |
| 1 | 2.2K 2.2k | R_0603_1608Metric_Pad0.98x0.95mm_HandSolder | RP1 |
| 1 | 330 | R_0603_1608Metric_Pad0.98x0.95mm_HandSolder | RP2 |
| 1 | 1.5K 1.5k | R_0603_1608Metric_Pad0.98x0.95mm_HandSolder | RP3 |
| 1 | 4.12K 4.12k | R_0603_1608Metric_Pad0.98x0.95mm_HandSolder | RP4 |
| 1 | 1.18K 1.18k | R_0603_1608Metric_Pad0.98x0.95mm_HandSolder | RP5 |
| 1 | 1.13K 1.13k | R_0603_1608Metric_Pad0.98x0.95mm_HandSolder | RP6 |
| 2 | 22 | R_0402_1005Metric | RUSB1, RUSB2 |
| 1 | 150k | R_0603_1608Metric | Rdiv1 |
| 1 | 300k | R_0603_1608Metric | Rdiv2 |
| 2 | SW_Push | SW_SPST_PTS647_Sx38 | SW1, SW2 |
| 1 | LED | LED_0603_1608Metric | DP1 |
| 1 | D_TVS | D_0603_1608Metric | D1 |
| 1 | 4.7NH 4.7nH | L_0402_1005Metric | L1 |
| 2 | 10UH 10uH | L_0603_1608Metric | L2, L4 |
| 1 | 15NH 15nH | L_0402_1005Metric | L3 |
| 4 | 12P 12p | C_0402_1005Metric | C1, C2, C17, C18 |
| 1 | 0.8P 0.8p | C_0402_1005Metric | C3 |
| 1 | 0.5P 0.5p | C_0402_1005Metric | C4 |
| 6 | 100N 100n | C_0402_1005Metric | C5, C7, C8, C12, C25, C26 |
| 4 | 4.7U 4.7u | C_0603_1608Metric | C6, C19, C20, C21 |
| 1 | 820P 820p | C_0402_1005Metric | C9 |
| 3 | N.C. | C_0402_1005Metric | C10, C13, C22 |
| 1 | 100P 100p | C_0402_1005Metric | C11 |
| 4 | 1.0U 1.0u | C_0603_1608Metric | C14, C15, C23, C24 |
| 1 | 47N 47n | C_0402_1005Metric | C16 |
Hyper Wheel base design files
The KiCad project lives in the AnotherBuildCorner/Hyper_Wheel repository on GitHub; these links point at the commit this page was built from.
Hyper Wheel base: common questions
What microcontroller does the Hyper Wheel base use?
The Hyper Wheel base is built around the NRF52840-QIAA-R7, from the Nordic nRF family.
How big is the Hyper Wheel base PCB?
The Hyper Wheel base measures 95 × 68 mm, has 4 copper layers and is 1.6 mm thick.
How many components are on the Hyper Wheel base?
75 components, from 46 distinct parts, with part numbers taken from the project's own BOM. The full bill of materials is listed on this page.
Where can I download the Hyper Wheel base design files?
From the AnotherBuildCorner/Hyper_Wheel repository on GitHub, which has the KiCad layout, the schematic and the BOM; the links under Design files point to each one.
Can I use the Hyper Wheel base design in my own project?
The repository has no license, so all rights stay with AnotherBuildCorner. Use it as a reference, and ask the author before reusing the design.
Can I test firmware for the Hyper Wheel base without the hardware?
Yes. HardLabs builds a simulation of the board from its netlist and BOM, so you can run and debug Nordic nRF firmware against it before you order a PCB.
More boards in Hyper_Wheel
Similar boards
 Nordic nRF
Keyboard
byrantech
262.5 × 109.6 mm206 parts2LMIT4.3k Nordic nRF
TOTEM
GEIGEIGEIST
258.8 × 94.4 mm85 parts2LCERN-OHL-P-2.02.0k Nordic nRF
Pixl.js
solosky
40 × 23 mm45 parts4LGPL-2.01.4k Nordic nRF
Board hl15-latest
dennisss
61 × 37 mm14 parts2LApache-2.0381 Nordic nRF
Management
101 × 31.5 mm50 parts2LApache-2.0381 Nordic nRF
Board
363 × 128 mm420 parts4LApache-2.0381