
GOONER2000

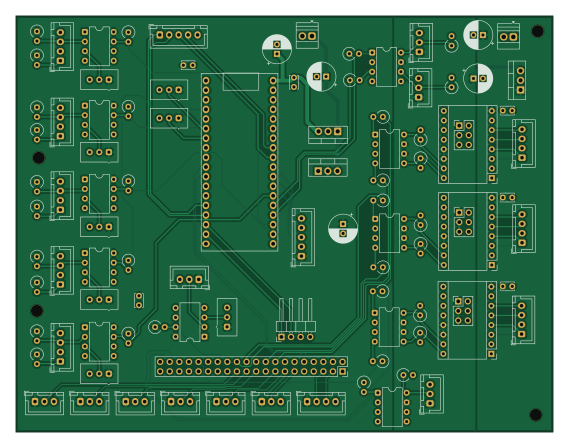
About the GOONER2000 PCB
GOONER2000 is an open source ESP32 PCB design by avi-guha, published on GitHub. It is a 4-layer board measuring 142 × 110 mm, with 99 components from 22 distinct parts.
Its main chip is the ESP32_Pico_Devkit, from the ESP32 family. Other key parts include the LM311, MCT62H, L7805 and POLOLU_BREAKOUT_DRV8825. By type, the board carries 28 connectors, 15 ICs, 11 capacitors and 3 modules.
It belongs with the robotics & motion designs in this gallery.
From the project
1. Clone this repo to your local device. git clone https://github.com/KazuoCalvin/ENPH-253-ROBO-SUMMER-.git
1. Clone this repo to your local device. git clone https://github.com/KazuoCalvin/ENPH-253-ROBO-SUMMER-.git
For your first time, use git fetch origin git checkout -b your-branch-name origin/your-branch-name
From next time, to switch branches, use git checkout (Personal Branch name)
3. Commit and Push in Personal Branch git commit -m "concise, but descriptive message" git push origin (Personal Branch name)
Main components on the GOONER2000
GOONER2000 bill of materials (BOM)
99 components, 22 distinct parts — part numbers from the project's BOM.
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 6 | LM311 | DIP-8_W7.62mm | U1, U2, U4, U5, U6, U9 |
| 5 | MCT62H | DIP-8_W7.62mm | U3, U11, U13, U14, U15 |
| 2 | L7805 | TO-220-3_Vertical | U7, U10 |
| 1 | ~ | TO-220-3_Vertical | U8 |
| 1 | ~ | ESP32_Pico_Devkit | U12 |
| 3 | POLOLU_BREAKOUT_DRV8825 Pololu_Breakout_DRV8825 | Pololu_Breakout-16_15.2x20.3mm | A1, A2, A3 |
| 2 | CONN_01X05_SOCKET Conn_01x05_Socket | JST_XH_B5B-XH-A_1x05_P2.50mm_Vertical | J1, J9 |
| 9 | CONN_01X04_SOCKET Conn_01x04_Socket | JST_XH_B4B-XH-A_1x04_P2.50mm_Vertical | J2, J3, J6, J7, J8, J11, J22, J23 +1 |
| 10 | CONN_01X03_SOCKET Conn_01x03_Socket | JST_XH_B3B-XH-A_1x03_P2.50mm_Vertical | J4, J5, J10, J12, J13, J14, J15, J16 +2 |
| 1 | CONN_01X03_SOCKET Conn_01x02_Socket | TerminalBlock_Xinya_XY308-2.54-2P_1x02_P2.54mm_Horizontal | J18 |
| 1 | CONN_01X02_SOCKET Conn_01x02_Socket | TerminalBlock_Xinya_XY308-2.54-2P_1x02_P2.54mm_Horizontal | J19 |
| 1 | CONN_01X04_SOCKET Conn_01x04_Socket | PinHeader_1x04_P2.54mm_Horizontal | J21 |
| 1 | RASPBERRY_PI_4 Raspberry_Pi_4 | PinSocket_2x20_P2.54mm_Vertical | J24 |
| 3 | Conn_02x03_Odd_Even | PinHeader_2x03_P2.54mm_Vertical | J28, J29, J30 |
| 6 | R_Potentiometer | Potentiometer_Vishay_T93YA_Vertical | RV1, RV2, RV3, RV4, RV5, RV6 |
| 2 | 100k | Potentiometer_Vishay_T93YA_Vertical | RV_Kd1, RV_Kp1 |
| 20 | 1k | R_Axial_DIN0309_L9.0mm_D3.2mm_P2.54mm_Vertical | R_CLAW_PWM1, R_CLAW_PWM_P1, R_DHES_PU1, R_IRED_LEFT1, R_IRED_LEFT_PU1, R_IRED_RIGHT1, R_IRED_RIGHT_PU1, R_IRLF_BACKUP1 +12 |
| 13 | 100 | R_Axial_DIN0309_L9.0mm_D3.2mm_P2.54mm_Vertical | R_IRED_LEFT_LED1, R_IRED_RIGHT_LED1, R_IRLF_BACKUP_LED1, R_IRLF_LEFT_LED1, R_IRLF_RIGHT_LED1, R_PWM_BU1, R_PWM_BU2, R_SM1_DIR1 +5 |
| 1 | R | R_Axial_DIN0309_L9.0mm_D3.2mm_P2.54mm_Vertical | R_SM3_DIR2 |
| 1 | 47P 47p | CP_Radial_D7.5mm_P2.50mm | C1 |
Show 2 more
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 4 | 47U 47u | CP_Radial_D7.5mm_P2.50mm | C2, C6, C7, C8 |
| 6 | 100P 100p | C_Disc_D3.4mm_W2.1mm_P2.50mm | C3, C4, C5, C9, C10, C11 |
GOONER2000 design files
The KiCad project lives in the avi-guha/ROBOT repository on GitHub; these links point at the commit this page was built from.
GOONER2000: common questions
What microcontroller does the GOONER2000 use?
The GOONER2000 is built around the ESP32_Pico_Devkit, from the ESP32 family.
How big is the GOONER2000 PCB?
The GOONER2000 measures 142 × 110 mm, has 4 copper layers and is 1.6 mm thick.
How many components are on the GOONER2000?
99 components, from 22 distinct parts, with part numbers taken from the project's own BOM. The full bill of materials is listed on this page.
Where can I download the GOONER2000 design files?
From the avi-guha/ROBOT repository on GitHub, which has the KiCad layout, the schematic and the BOM; the links under Design files point to each one.
Can I use the GOONER2000 design in my own project?
The repository has no license, so all rights stay with avi-guha. Use it as a reference, and ask the author before reusing the design.
Can I test firmware for the GOONER2000 without the hardware?
Yes. HardLabs builds a simulation of the board from its netlist and BOM, so you can run and debug ESP32 firmware against it before you order a PCB.
More boards in ROBOT
Similar boards
 ESP32
OSO-BOOK-B1
joeycastillo
85 × 115 mm65 parts2LCC-BY-SA-4.08.1k ESP32
Powertrain
byrantech
64 × 45.4 mm171 parts4LMIT4.3k ESP32
Esp32 minimal
atopile
36.2 × 26.8 mm20 parts2LMIT4.0k ESP32
Badge
56.3 × 39 mm239 parts4LMIT4.0k ESP32
Racer
StuckAtPrototype
36 × 50.2 mm70 parts4LApache-2.03.8k ESP32
Controller
29 × 74 mm58 parts4LApache-2.03.8k