
RoboCore 2.0

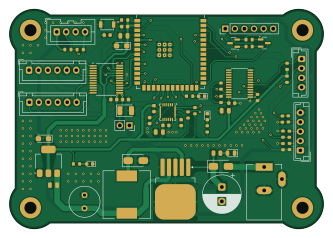
About the RoboCore 2.0 PCB
RoboCore 2.0 is an open source ESP32 PCB design by AvishkaVishwa, published on GitHub. It is a 2-layer board measuring 83 × 58 mm, with 64 components from 32 distinct parts.
Its main chip is the ESP32-S3-WROOM-1, from the ESP32 family. Other key parts include the TB6612FNG, LM2596S-5, AMS1117-3.3, MPU-6050 and TCA9548APWR. By type, the board carries 22 resistors, 18 capacitors, 8 connectors, 6 ICs, 6 diodes and 2 transistors.
It belongs with the sensors, robotics & motion and iot & wireless designs in this gallery.
From the project
ESP32-S3 based RoboCore 2.0 robotics controller board – custom 2-layer PCB with dual motor drivers, encoders, IMU, sensors and ESP-IDF test firmware.
RoboCore 2.0 is my second-generation robotics controller board,
RoboCore 2.0 is built on a 2-layer FR-4 PCB (1.6 mm) designed specifically for small mobile robots.
- Microcontroller section: ESP32-S3 with proper decoupling and EN/BOOT circuitry following Espressif’s reference design for reliable flashing and resets.
- Power distribution: 5 V rail for motors and sensors, 3.3 V rail for logic (ESP32-S3, IMU, I²C devices). Decoupling capacitors are placed close to each IC to keep the supply stable.
Main components on the RoboCore 2.0
RoboCore 2.0 bill of materials (BOM)
64 components, 32 distinct parts — part numbers from the project's BOM.
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 1 | TB6612FNG | SSOP-24_5.3x8.2mm_P0.65mm | U1 |
| 1 | LM2596S-5 | TO-263-5_TabPin3 | U2 |
| 1 | ESP32-S3-WROOM-1 | ESP32-S3-WROOM-1 | U3 |
| 1 | AMS1117-3.3 | SOT-223-3_TabPin2 | U4 |
| 1 | MPU-6050 | InvenSense_QFN-24_4x4mm_P0.5mm | U5 |
| 1 | TCA9548APWR | TSSOP-24_4.4x7.8mm_P0.65mm | U6 |
| 2 | BC817 | SOT-23 | Q1, Q2 |
| 1 | CONN_01X06_SOCKET Conn_01x06_Socket | PinHeader_1x06_P2.54mm_Vertical | J1 |
| 1 | Barrel_Jack_Switch | BarrelJack_Kycon_KLDX-0202-xC_Horizontal | J2 |
| 1 | CONN_01X02_PIN Conn_01x02_Pin | PinSocket_1x02_P2.54mm_Vertical | J3 |
| 1 | CONN_01X04_PIN Conn_01x04_Pin | JST_XA_B04B-XASK-1_1x04_P2.50mm_Vertical | J4 |
| 1 | CONN_01X05_PIN Conn_01x05_Pin | JST_EH_B5B-EH-A_1x05_P2.50mm_Vertical | J5 |
| 2 | CONN_01X06_PIN Conn_01x06_Pin | JST_XH_B6B-XH-A_1x06_P2.50mm_Vertical | J6, J8 |
| 1 | CONN_01X04_PIN Conn_01x04_Pin | JST_EH_B4B-EH-A_1x04_P2.50mm_Vertical | J7 |
| 1 | SW_Push | SW_SPST_B3U-1000P | SW1 |
| 1 | C95872 M7 MDD(Microdiode Electronics) | D_SMA | D1 |
| 3 | Red | D_0603 | D2, D5, D6 |
| 1 | Red | D_0805 | D3 |
| 1 | SS34 | D_SMA | D4 |
| 1 | 33UH 33uH | L_12x12mm_H6mm | L1 |
Show 12 more
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 8 | 100NF 100nF YAGEO | C_0603 | C1, C3, C4, C7, C13, C14, C15, C16 |
| 1 | 680UF 680uF | CP_Radial_D10.0mm_P3.80mm | C2 |
| 1 | 22UF 22uF Samsung Electro-Mechanics | C_CASE-B-3528-21(mm) | C5 |
| 1 | 220UF 220uF | C_Radial_D8.0mm_H7.0mm_P3.50mm | C6 |
| 4 | 10UF 10uF YAGEO | C_0805 | C8, C9, C12, C17 |
| 2 | 22UF 22uF Samsung Electro-Mechanics | C_CASE-A-3216-18(mm) | C10, C11 |
| 1 | 2.2NF 2.2nF FH(Guangdong Fenghua Advanced Tech) | C_0603 | C18 |
| 3 | 1k | R_0603 | R1, R6, R17 |
| 8 | 10kΩ UNI-ROYAL(Uniroyal Elec) | R_0603 | R2, R3, R5, R9, R11, R13, R15, R18 |
| 1 | 1k | R_0805 | R4 |
| 6 | 4.7kΩ UNI-ROYAL(Uniroyal Elec) | R_0603 | R7, R8, R19, R20, R21, R22 |
| 4 | 20kΩ UNI-ROYAL(Uniroyal Elec) | R_0603 | R10, R12, R14, R16 |
RoboCore 2.0 design files
The KiCad project lives in the AvishkaVishwa/RoboCore_2.0 repository on GitHub; these links point at the commit this page was built from.
RoboCore 2.0: common questions
What microcontroller does the RoboCore 2.0 use?
The RoboCore 2.0 is built around the ESP32-S3-WROOM-1, from the ESP32 family.
How big is the RoboCore 2.0 PCB?
The RoboCore 2.0 measures 83 × 58 mm, has 2 copper layers and is 1.6 mm thick.
How many components are on the RoboCore 2.0?
64 components, from 32 distinct parts, with part numbers taken from the project's own BOM. The full bill of materials is listed on this page.
Where can I download the RoboCore 2.0 design files?
From the AvishkaVishwa/RoboCore_2.0 repository on GitHub, which has the KiCad layout, the schematic and the BOM; the links under Design files point to each one.
Can I use the RoboCore 2.0 design in my own project?
The repository has no license, so all rights stay with AvishkaVishwa. Use it as a reference, and ask the author before reusing the design.
Can I test firmware for the RoboCore 2.0 without the hardware?
Yes. HardLabs builds a simulation of the board from its netlist and BOM, so you can run and debug ESP32 firmware against it before you order a PCB.
Similar boards
 ESP32
Open Book Abridged Edition
joeycastillo
85 × 115 mm65 parts2LCC-BY-SA-4.08.1k ESP32
Badge
atopile
56.3 × 39 mm239 parts4LMIT4.0k ESP32
Esp32 minimal
36.2 × 26.8 mm20 parts2LMIT4.0k ESP32
Racer
StuckAtPrototype
36 × 50.2 mm70 parts4LApache-2.03.8k ESP32
Controller
29 × 74 mm58 parts4LApache-2.03.8k ESP32
Bitaxe
skot
56.5 × 99.8 mm86 parts4LCERN-OHL-S-2.01.4k