
MiniBot

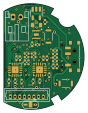
About the MiniBot PCB
MiniBot is an open source ESP32 PCB design by DDeGonge, published on GitHub under the MIT license. It is a 4-layer board measuring 21.2 × 28 mm, with 58 components from 26 distinct parts.
Its main chip is the ESP32-C3-MINI-1-H4X, from the ESP32 family. Other key parts include the MMC5633NJL, MIC23050-SYML-TR, MCP73832-2-OT and STSPIN220. By type, the board carries 23 resistors, 19 capacitors, 6 ICs, 3 connectors, 3 switches and 2 jumpers.
It belongs with the robotics & motion, iot & wireless and power & battery designs in this gallery.
From the project
Super cheap super tiny bots for....playing chess...
A swarm robotics platform built around autonomous chess. The system runs 34 small differential-drive robots across an 8x8 board, each independently localized and coordinated by a central Python application running on a Raspberry Pi.
The design is general-purpose — chess is the primary use case, but the platform works for any scenario requiring coordinated movement of many small autonomous robots in a bounded space.
Main components on the MiniBot
MiniBot bill of materials (BOM)
58 components, 26 distinct parts — part numbers from the project's BOM.
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 1 | MMC5633NJL Memsic Inc. | BGA4C40P2X2_85X85X60 | IC1 |
| 1 | MIC23050-SYML-TR Microchip Technology | SON50P200X200X90-9N-D | IC2 |
| 1 | ESP32-C3-MINI-1-H4X Espressif Systems | ESP32C3MINI1H4X | U1 |
| 1 | MCP73832-2-OT Microchip Technology | SOT-23-5 | U3 |
| 2 | STSPIN220 STMicroelectronics | VQFN-16-1EP_3x3mm_P0.5mm_EP1.8x1.8mm | U4, U5 |
| 1 | 530470810 Conn_01x08 Molex | Molex_PicoBlade_53047-0810_1x08_P1.25mm_Vertical | J1 |
| 1 | S2B-PH-K-S Conn_01x02 JST | JST_PH_S2B-PH-K_1x02_P2.00mm_Horizontal | J2 |
| 1 | GSB1C41110SSHR Amphenol Canada | GSB1C41110SSHR | J3 |
| 2 | Jumper_3_Bridged12 | SolderJumper-3_P1.3mm_Bridged12_RoundedPad1.0x1.5mm | JP1, JP2 |
| 1 | PCM12SMTR C&K | PCM12SMTR | S1 |
| 2 | EVP-AWBD4A Panasonic | EVPAWBD4A | S2, S3 |
| 1 | EASV2010RWA0 Everlight Electronics Co Ltd | EASV2010RWA0 | LED1 |
| 1 | MLZ2012N1R0LT000 L TKD | L_0805_2012Metric | L1 |
| 3 | GRM155R60J475ME47D 4.7uF Murata Electronics | C_0402_1005Metric | C1, C8, C10 |
| 10 | GRM155R71C104KA88J 0.1uF Murata Electronics | C_0402_1005Metric | C2, C4, C5, C6, C9, C15, C16, C19 +2 |
| 1 | GCM155C71A105KE38D 1uF Murata Electronics | C_0402_1005Metric | C3 |
| 1 | GRM1555C1H561JA01D 560pF Murata Electronics | C_0402_1005Metric | C7 |
| 2 | GRM155R60J106ME05J 10uF Murata Electronics | C_0402_1005Metric | C17, C21 |
| 2 | GRM155R71C223KA01D 22nF Murata Electronics | C_0402_1005Metric | C18, C22 |
| 4 | RC0402FR-135K1L 5.1k YAGEO | R_0402_1005Metric | R1, R2, R14, R15 |
Show 6 more
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 6 | RC0402FR-0710KL 10k YAGEO | R_0402_1005Metric | R3, R4, R5, R6, R9, R12 |
| 3 | RC0402FR-07390KL 390k YAGEO | R_0402_1005Metric | R7, R10, R11 |
| 1 | RC0402FR-0712K4L 12.4k YAGEO | R_0402_1005Metric | R8 |
| 3 | RC0402FR-071KL 1k YAGEO | R_0402_1005Metric | R13, R16, R20 |
| 4 | AC0402FR-7W1RL 1 YAGEO | R_0402_1005Metric | R18, R19, R22, R23 |
| 2 | RC0402FR-0747KL 47k YAGEO | R_0402_1005Metric | R24, R25 |
MiniBot design files
The KiCad project lives in the DDeGonge/MiniBot repository on GitHub; these links point at the commit this page was built from.
MiniBot: common questions
What microcontroller does the MiniBot use?
The MiniBot is built around the ESP32-C3-MINI-1-H4X, from the ESP32 family.
How big is the MiniBot PCB?
The MiniBot measures 21.2 × 28 mm, has 4 copper layers and is 0.8 mm thick.
How many components are on the MiniBot?
58 components, from 26 distinct parts, with part numbers taken from the project's own BOM. The full bill of materials is listed on this page.
Where can I download the MiniBot design files?
From the DDeGonge/MiniBot repository on GitHub, which has the KiCad layout, the schematic and the BOM; the links under Design files point to each one.
Can I use the MiniBot design in my own project?
Yes, under the terms of its MIT license, which DDeGonge chose for the repository.
Can I test firmware for the MiniBot without the hardware?
Yes. HardLabs builds a simulation of the board from its netlist and BOM, so you can run and debug ESP32 firmware against it before you order a PCB.
More boards in MiniBot
Similar boards
 ESP32
Open Book Abridged Edition
joeycastillo
85 × 115 mm65 parts2LCC-BY-SA-4.08.1k ESP32
Powertrain
byrantech
64 × 45.4 mm171 parts4LMIT4.3k ESP32
Badge
atopile
56.3 × 39 mm239 parts4LMIT4.0k ESP32
Esp32 minimal
36.2 × 26.8 mm20 parts2LMIT4.0k ESP32
Controller
StuckAtPrototype
29 × 74 mm58 parts4LApache-2.03.8k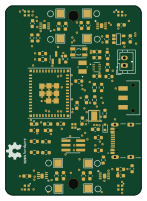 ESP32
Racer
36 × 50.2 mm70 parts4LApache-2.03.8k