
MR SLDR

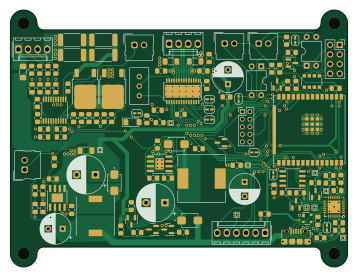
About the MR SLDR PCB
MR SLDR is an open source ESP32 PCB design by MikolajMarkiel, published on GitHub under the MIT license. It is a 2-layer board measuring 89.3 × 68 mm, with 135 components from 56 distinct parts.
Its main chip is the ESP32-WROOM-E, from the ESP32 family. Other key parts include the BM3451, CP2102N-Axx-xQFN28, DRV8825, 93CxxC and PC817. By type, the board carries 50 resistors, 29 capacitors, 10 connectors, 9 ICs, 9 transistors and 9 jumpers.
It belongs with the iot & wireless, robotics & motion and usb & debug tools designs in this gallery.
From the project
BLE controlled camera slider
The project is in build stage. Missing documentation and functionalities will be added in time.
The MR_SLDR is a project of remote controlled slider for camera. It will be controlled by Bluetooth Low Energy protocol. The main library source for this project is Zephyr OS.
Due to problems with flexibility occurence of threads in zephyr (minimal period step is 100us) I've decided to leave control of stepper motor up to hardware timer peripheral. Unfortunately right now esp32 timer drivers are dedicated only for counters that lose synchronization after overflow of counted ticks. Because of that…
Main components on the MR SLDR
MR SLDR bill of materials (BOM)
135 components, 56 distinct parts — part numbers from the project's BOM.
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 1 | BM3451 | TSSOP-20_4.4x6.5mm_P0.65mm | U1 |
| 2 | ~ | SOIC-8-1EP_3.9x4.9mm_P1.27mm_EP2.29x3mm | U2, U3 |
| 1 | ESP32-WROOM-E | ESP32-WROOM-32E | U4 |
| 1 | CP2102N-Axx-xQFN28 | QFN-28-1EP_5x5mm_P0.5mm_EP3.35x3.35mm | U5 |
| 1 | DRV8825 | HTSSOP-28-1EP_4.4x9.7mm_P0.65mm_EP3.4x9.5mm_ThermalVias | U6 |
| 1 | 93CxxC | SO-8_3.9x4.9mm_P1.27mm | U7 |
| 2 | PC817 | DIP-4_W7.62mm | U8, U9 |
| 6 | BC817 | SOT-23 | Q1, Q2, Q6, Q7, Q8, Q9 |
| 1 | IRLML6402 | SOT-23 | Q3 |
| 2 | QM6006D | TO-252-2 | Q4, Q5 |
| 4 | Conn_01x02_Pin | Molex_SL_171971-0002_1x02_P2.54mm_Vertical | J1, J8, J9, J10 |
| 1 | Conn_01x04_Pin | Molex_KK-254_AE-6410-04A_1x04_P2.54mm_Vertical | J2 |
| 1 | USB_B_Micro | USB_Micro-B_Amphenol_10118194_Horizontal | J3 |
| 1 | Conn_02x05_Odd_Even | PinHeader_2x05_P2.00mm_Vertical | J4 |
| 1 | Conn_01x04_Socket | Molex_KK-254_AE-6410-04A_1x04_P2.54mm_Vertical | J5 |
| 1 | Conn_01x06_Pin | Molex_KK-254_AE-6410-06A_1x06_P2.54mm_Vertical | J6 |
| 1 | Conn_02x04_Odd_Even | PinSocket_2x04_P2.54mm_Vertical | J7 |
| 1 | TestPoint | TestPoint_THTPad_1.0x1.0mm_Drill0.5mm | Batt.meas1 |
| 1 | Fuse | Fuse_1206_3216Metric_Pad1.42x1.75mm_HandSolder | F1 |
| 4 | SolderJumper_2_Bridged | SolderJumper-2_P1.3mm_Bridged_RoundedPad1.0x1.5mm | JP1, JP7, JP8, JP9 |
Show 36 more
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 5 | SolderJumper_2_Open | SolderJumper-2_P1.3mm_Open_RoundedPad1.0x1.5mm | JP2, JP3, JP4, JP5, JP6 |
| 1 | 100k | Potentiometer_Bourns_3296W_Vertical | RV1 |
| 1 | +3.3V | TestPoint_THTPad_1.0x1.0mm_Drill0.5mm | TP1 |
| 1 | +12V | TestPoint_THTPad_1.0x1.0mm_Drill0.5mm | TP2 |
| 6 | TestPoint | TestPoint_THTPad_1.0x1.0mm_Drill0.5mm | TP3, TP4, TP5, TP6, TP7, TP8 |
| 3 | SS24 | DIOM5336X265N | D1, D2, D3 |
| 1 | SP0503BAHT | SOT-143 | D4 |
| 1 | 10V | D_MiniMELF | D5 |
| 1 | BAT54S | SOT-23 | D6 |
| 1 | 33uH | L_12x12mm_H8mm | L1 |
| 1 | 22uH | L_TDK_VLF10040 | L2 |
| 2 | 680uF | CP_Radial_D10.0mm_P5.00mm | C1, C19 |
| 15 | 100nF | C_0805_2012Metric_Pad1.18x1.45mm_HandSolder | C2, C3, C4, C5, C6, C8, C9, C10 +7 |
| 2 | 470uF | CP_Radial_D8.0mm_P3.80mm | C11, C14 |
| 1 | none | C_0805_2012Metric_Pad1.18x1.45mm_HandSolder | C16 |
| 3 | 470nF | C_0805_2012Metric_Pad1.18x1.45mm_HandSolder | C17, C18, C23 |
| 1 | 4.7uF | C_1206_3216Metric_Pad1.33x1.80mm_HandSolder | C20 |
| 1 | 100uF | CP_Radial_D8.0mm_P3.80mm | C24 |
| 4 | 10nF | C_0805_2012Metric_Pad1.18x1.45mm_HandSolder | C25, C26, C27, C28 |
| 14 | 1k | R_0805_2012Metric_Pad1.20x1.40mm_HandSolder | R1, R2, R3, R7, R14, R15, R16, R19 +6 |
| 2 | 5M | R_0805_2012Metric_Pad1.20x1.40mm_HandSolder | R4, R8 |
| 3 | 3k | R_0805_2012Metric_Pad1.20x1.40mm_HandSolder | R5, R10, R20 |
| 1 | 220k | R_0805_2012Metric_Pad1.20x1.40mm_HandSolder | R6 |
| 3 | 1M | R_0805_2012Metric_Pad1.20x1.40mm_HandSolder | R9, R11, R35 |
| 7 | 10k | R_0805_2012Metric_Pad1.20x1.40mm_HandSolder | R12, R32, R33, R34, R38, R41, R42 |
| 1 | 2k | R_0805_2012Metric_Pad1.20x1.40mm_HandSolder | R13 |
| 4 | 5m | R_2512_6332Metric_Pad1.40x3.35mm_HandSolder | R17, R18, R22, R23 |
| 1 | 1.8k | R_0805_2012Metric_Pad1.20x1.40mm_HandSolder | R21 |
| 4 | 100k | R_0805_2012Metric_Pad1.20x1.40mm_HandSolder | R24, R39, R40, R48 |
| 1 | 11k | R_0805_2012Metric_Pad1.20x1.40mm_HandSolder | R25 |
| 1 | 24k | R_0805_2012Metric_Pad1.20x1.40mm_HandSolder | R27 |
| 1 | 47k | R_0805_2012Metric_Pad1.20x1.40mm_HandSolder | R28 |
| 1 | 4,7k | R_0805_2012Metric_Pad1.20x1.40mm_HandSolder | R29 |
| 2 | 100m | R_1206_3216Metric_Pad1.30x1.75mm_HandSolder | R36, R37 |
| 3 | none | R_0805_2012Metric_Pad1.20x1.40mm_HandSolder | R45, R46, R49 |
| 1 | 1k | R_Array_Convex_4x1206 | RN1 |
MR SLDR design files
The KiCad project lives in the MikolajMarkiel/MR_SLDR repository on GitHub; these links point at the commit this page was built from.
MR SLDR: common questions
What microcontroller does the MR SLDR use?
The MR SLDR is built around the ESP32-WROOM-E, from the ESP32 family.
How big is the MR SLDR PCB?
The MR SLDR measures 89.3 × 68 mm, has 2 copper layers and is 1.6 mm thick.
How many components are on the MR SLDR?
135 components, from 56 distinct parts, with part numbers taken from the project's own BOM. The full bill of materials is listed on this page.
Where can I download the MR SLDR design files?
From the MikolajMarkiel/MR_SLDR repository on GitHub, which has the KiCad layout, the schematic and the BOM; the links under Design files point to each one.
Can I use the MR SLDR design in my own project?
Yes, under the terms of its MIT license, which MikolajMarkiel chose for the repository.
Can I test firmware for the MR SLDR without the hardware?
Yes. HardLabs builds a simulation of the board from its netlist and BOM, so you can run and debug ESP32 firmware against it before you order a PCB.
Similar boards
 ESP32
Open Book Abridged Edition
joeycastillo
85 × 115 mm65 parts2LCC-BY-SA-4.08.1k ESP32
Badge
atopile
56.3 × 39 mm239 parts4LMIT4.0k ESP32
Esp32 minimal
36.2 × 26.8 mm20 parts2LMIT4.0k ESP32
Racer
StuckAtPrototype
36 × 50.2 mm70 parts4LApache-2.03.8k ESP32
Controller
29 × 74 mm58 parts4LApache-2.03.8k ESP32
Bitaxe
skot
56.5 × 99.8 mm86 parts4LCERN-OHL-S-2.01.4k