
Open MOtor DRiver Initiative (OMODRI) - Extension Board

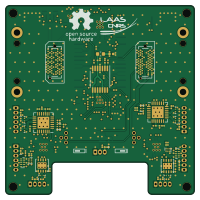
About the Open MOtor DRiver Initiative (OMODRI) - Extension Board
Open MOtor DRiver Initiative (OMODRI) - Extension Board is an open source PCB design by open-dynamic-robot-initiative, published on GitHub under the BSD-3-Clause license. It is a 6-layer board measuring 50 × 50 mm, with 167 components from 98 distinct parts.
Other key parts include the 74LVC2G17, DSLVDS1047PWR, DSLVDS1048PWR, F28388DZWTS and TPS3703A7330DSERQ1. By type, the board carries 55 resistors, 52 capacitors, 18 ICs, 17 diodes, 11 connectors and 9 jumpers.
It belongs with the robotics & motion designs in this gallery.
From the project
Open-source drive for brushless motors, following the open dynamic robot initiative
Main components on the Open MOtor DRiver Initiative (OMODRI) - Extension Board
Open MOtor DRiver Initiative (OMODRI) - Extension Board bill of materials (BOM)
167 components, 98 distinct parts — part numbers from the project's BOM.
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 1 | 74LVC2G17 OPA388 | SOT-23-5 | U1 |
| 1 | 74LVC2G17 74LVC2G06 | USON-6_P0.5mm_1x1.5mm | U2 |
| 1 | 74LVC2G17 CDCLVC1106 | TSSOP-14_4.4x5mm_P0.65mm | U3 |
| 1 | DSLVDS1047PWR CAT24C16 | DFN-8-1EP_3x2mm_P0.5mm_EP1.3x1.5mm | U4 |
| 1 | DSLVDS1048PWR 74LVC1G06 | USON-6_P0.5mm_1x1.5mm | U5 |
| 1 | F28388DZWTS DP83826I | VQFN-32-1EP_5x5mm_P0.5mm_EP2.2x2.2mm | U6 |
| 1 | TPS3703A7330DSERQ1 74LVC1G06 | USON-6_P0.5mm_1x1.5mm | U7 |
| 1 | TPS3703A7120DSERQ1 DP83826I | VQFN-32-1EP_5x5mm_P0.5mm_EP2.2x2.2mm | U8 |
| 1 | DRV8353SRTAT THVD2450 | TDFN-8-1EP_3.0x3.0mm_P0.65mm | U9 |
| 1 | DRV8353SRTAT MAX3107 | TQFN-24-1EP_3.5x3.5mm_P0.4mm_EP2.4x2.4mm | U10 |
| 1 | MPM3804GG iC-MB4 | TQFN-28-1EP_5x5mm_P0.5mm_EP3.1x3.1mm | U12 |
| 1 | MPM3804GG THVD2450 | TDFN-8-1EP_3.0x3.0mm_P0.65mm | U13 |
| 1 | LT6654AIS6-3 MAX3107 | TQFN-24-1EP_3.5x3.5mm_P0.4mm_EP2.4x2.4mm | U14 |
| 1 | BMI088 iC-MB4 | TQFN-28-1EP_5x5mm_P0.5mm_EP3.1x3.1mm | U16 |
| 1 | TCAN330GDCNR 74LVC1G125 | USON-6_P0.5mm_1x1.5mm | U17 |
| 1 | THVD2450DRBR 74LVC1G125 | USON-6_P0.5mm_1x1.5mm | U18 |
| 1 | 74LVC2G17 74LVC1G125 | USON-6_P0.5mm_1x1.5mm | U19 |
| 1 | 74LVC1G125 | USON-6_P0.5mm_1x1.5mm | U20 |
| 1 | CONN_01X04_MOUNTINGPINS Conn_01x03 | Hirose_DF13-03P-1.25DSA_1x03_P1.25mm_Vertical | J1 |
| 2 | CONN_01X05_MOUNTINGPINS ADM6_ADF6 | ADM6-10-XX.X-XXX-4-X-A-XR | J2, J3 |
Show 78 more
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 2 | 5034800800 Molex_480749101 | RJ45_Molex_48074-9101_Horizontal | J4, J5 |
| 1 | CONN_01X02 Conn_01x04 | Hirose_DF13-04P-1.25DSA_1x04_P1.25mm_Vertical | J6 |
| 1 | 20021311-00008T4LF Conn_01x06 | Hirose_DF13-06P-1.25DSA_1x06_P1.25mm_Vertical | J7 |
| 1 | ADF6-10-03.5-L-4-2-A Conn_01x06 | Hirose_DF13-06P-1.25DSA_1x06_P1.25mm_Vertical | J8 |
| 1 | ADF6-10-03.5-L-4-2-A Conn_01x04 | Hirose_DF13-04P-1.25DSA_1x04_P1.25mm_Vertical | J9 |
| 2 | CONN_01X03 Conn_01x06 | Hirose_DF13-06P-1.25DSA_1x06_P1.25mm_Vertical | J10, J11 |
| 7 | SolderJumper_3_Open | SolderJumper-3_0201_0603Metric_Open_Pad | JP1, JP2, JP4, JP5, JP6, JP8, JP9 |
| 2 | Jumper_4 | Harwin_M50_04_P1.27mm_cross_Vertical | JP3, JP7 |
| 1 | Housing | uOmodri_laas | N1 |
| 1 | B3U-1000P-B B3U-3100P | SW_SPST_B3U-1000P | SW1 |
| 1 | TPD6E05U06RVZR PESD6V5C1USF | Diodes_DSN0603-2_0.6x0.3mm_P0.4mm | D1 |
| 1 | BAT54L LED_RED | LED_0402_1005Metric | D2 |
| 1 | TPD6E05U06RVZR LED_GREEN | LED_0402_1005Metric | D3 |
| 1 | WS2812B PESD12VA-SF | Diodes_DSN0603-2_0.6x0.3mm_P0.4mm | D4 |
| 3 | TPD1E04U04DPLT PESD12VA-SF | Diodes_DSN0603-2_0.6x0.3mm_P0.4mm | D5, D7, D8 |
| 1 | HSMG-C280 IP4283CZ10 | Diodes_DFN2510A-10_1.0x2.5mm_P0.5mm | D6 |
| 2 | HSMC-C280 PESD12VA-SF | Diodes_DSN0603-2_0.6x0.3mm_P0.4mm | D9, D10 |
| 1 | ESD321DPYR IP4283CZ10 | Diodes_DFN2510A-10_1.0x2.5mm_P0.5mm | D11 |
| 1 | ESD321DPYR PESD12VA-SF | Diodes_DSN0603-2_0.6x0.3mm_P0.4mm | D12 |
| 5 | PESD12VA-SF | Diodes_DSN0603-2_0.6x0.3mm_P0.4mm | D13, D14, D15, D16, D17 |
| 3 | BLM18SG221TN1D 220R@100MHz | L_0603_1608Metric | FB1, FB2, FB3 |
| 1 | GRM033R61C224KE14J 100n | C_0201_0603Metric | C1 |
| 1 | GRM033R61C224KE14J 10n | C_0201_0603Metric | C2 |
| 10 | GRM033R61E104KE14J 100n | C_0201_0603Metric | C3, C8, C12, C14, C22, C31, C39, C50 +2 |
| 2 | GRM033R71E182KA12D 10u | C_0402_1005Metric | C4, C33 |
| 4 | GRM033R71E182KA12D 1u | C_0201_0603Metric | C5, C32, C36, C49 |
| 8 | GRM033R71E182KA12D 100n | C_0201_0603Metric | C6, C9, C35, C43, C45, C46, C47, C48 |
| 3 | GRM033R61E104KE14J 10n | C_0201_0603Metric | C7, C13, C26 |
| 2 | GRM033R71E182KA12D 33n | C_0201_0603Metric | C10, C11 |
| 1 | C5750X7S2A226M280KB 1u | C_0201_0603Metric | C15 |
| 1 | C5750X7S2A226M280KB 10u | C_0402_1005Metric | C16 |
| 1 | C5750X7S2A226M280KB 10n | C_0201_0603Metric | C17 |
| 1 | C5750X7S2A226M280KB 100n | C_0201_0603Metric | C18 |
| 2 | GRM033R61E104KE14J 1u | C_0201_0603Metric | C19, C44 |
| 1 | GRM033R61E104KE14J 10u | C_0402_1005Metric | C20 |
| 1 | GRM033R61E104KE14J 2.2n | C_0603_1608Metric | C21 |
| 1 | GRM033R61E104KE14J 33n | C_0201_0603Metric | C23 |
| 1 | C1005X5R1V105K050BE 33n | C_0201_0603Metric | C24 |
| 2 | GRM188R61E106MA73D 100n | C_0201_0603Metric | C25, C38 |
| 3 | C1005X5R1V105K050BE 100n | C_0201_0603Metric | C27, C37, C40 |
| 2 | GRM033C81A105ME05D 1u | C_0201_0603Metric | C28, C41 |
| 1 | C1608X7S2A473K080AB 10u | C_0402_1005Metric | C29 |
| 1 | GRM033R71E182KA12D 10n | C_0201_0603Metric | C30 |
| 1 | GRM033R71E182KA12D 2.2n | C_0603_1608Metric | C34 |
| 1 | C1608X7S2A473K080AB 100n | C_0201_0603Metric | C42 |
| 6 | ERJ-1GNF1002C 10k | R_0201_0603Metric | R1, R2, R3, R4, R15, R48 |
| 1 | ERJ-1GNF1200C 4.7k | R_0201_0603Metric | R6 |
| 1 | ERJ-1GNF1001C 120 | R_0201_0603Metric | R7 |
| 2 | ERJ-1GNF1001C 2.2k | R_0201_0603Metric | R8, R10 |
| 2 | ERJ-1GNF1001C 470 | R_0201_0603Metric | R9, R11 |
| 1 | ERJ-1GNF1001C 10k | R_0201_0603Metric | R12 |
| 1 | ERJ-1GNF1002C 10 | R_0201_0603Metric | R14 |
| 1 | ERJ-1GNF1002C 4.7k | R_0201_0603Metric | R16 |
| 1 | ERJ-1GNF1001C 4.7k | R_0201_0603Metric | R17 |
| 2 | ERJ-1GNF1000C 2.2k | R_0201_0603Metric | R18, R19 |
| 1 | ERJ-1GNF1000C 6.49k | R_0201_0603Metric | R20 |
| 5 | ERJ-1GNF1002C 2.2k | R_0201_0603Metric | R21, R22, R23, R28, R29 |
| 1 | ERJ-2RKF1003X 470 | R_0201_0603Metric | R24 |
| 1 | ERJ-2RKF5101X 470 | R_0201_0603Metric | R25 |
| 2 | ERJ-1GNF1002C 1M | R_0805_2012Metric | R26, R36 |
| 1 | ERJ-1GNF1200C 10 | R_0201_0603Metric | R27 |
| 1 | ERJ-1GNF1200C 6.49k | R_0201_0603Metric | R30 |
| 2 | FC4L32R005FER 2.2k | R_0201_0603Metric | R31, R32 |
| 1 | ERJ-1GNF1200C 2.2k | R_0201_0603Metric | R33 |
| 2 | ERJ-1GNF1200C 470 | R_0201_0603Metric | R34, R35 |
| 2 | ERJ-1GNF1001C 10 | R_0201_0603Metric | R37, R45 |
| 2 | ERJ-1GNF1002C 120 | R_0201_0603Metric | R38, R46 |
| 3 | FC4L32R005FER 10k | R_0201_0603Metric | R39, R40, R47 |
| 1 | FC4L32R005FER 10 | R_0201_0603Metric | R41 |
| 3 | ERJ-1GNF1200C 10k | R_0201_0603Metric | R42, R43, R44 |
| 2 | ERJ-1GNF1003C 10 | R_0201_0603Metric | R49, R53 |
| 1 | ERJ-1GNF2491C 10k | R_0201_0603Metric | R50 |
| 1 | ERJ-1GNF1003C 10k | R_0201_0603Metric | R51 |
| 1 | ERJ-1GNF2212C 10k | R_0201_0603Metric | R52 |
| 1 | ERJ-1GNF1003C TBD | R_0201_0603Metric | R54 |
| 1 | ERJ-1GNF1200C TBD | R_0201_0603Metric | R55 |
| 1 | ERJ-1GNF1002C TBD | R_0201_0603Metric | R57 |
| 1 | ERJ-1GNF9090C TBD | R_0201_0603Metric | R58 |
Open MOtor DRiver Initiative (OMODRI) - Extension Board design files
The KiCad project lives in the open-dynamic-robot-initiative/open-motor-driver-initiative repository on GitHub; these links point at the commit this page was built from.
Open MOtor DRiver Initiative (OMODRI) - Extension Board: common questions
How big is the Open MOtor DRiver Initiative (OMODRI) - Extension Board?
The Open MOtor DRiver Initiative (OMODRI) - Extension Board measures 50 × 50 mm, has 6 copper layers and is 1.6 mm thick.
How many components are on the Open MOtor DRiver Initiative (OMODRI) - Extension Board?
167 components, from 98 distinct parts, with part numbers taken from the project's own BOM. The full bill of materials is listed on this page.
Where can I download the Open MOtor DRiver Initiative (OMODRI) - Extension Board design files?
From the open-dynamic-robot-initiative/open-motor-driver-initiative repository on GitHub, which has the KiCad layout and the BOM; the links under Design files point to each one.
Can I use the Open MOtor DRiver Initiative (OMODRI) - Extension Board design in my own project?
Yes, under the terms of its BSD-3-Clause license, which open-dynamic-robot-initiative chose for the repository.
More boards in open-motor-driver-initiative
Open MOtor DRiver Initiative (OMODRI)
50 × 50 mm253 parts8LBSD-3-Clause119
Open MOtor DRiver Initiative - Single Axis (OMODRI SA)
54.8 × 57.6 mm201 parts8LBSD-3-Clause119
Open MOtor DRiver Initiative - Single Axis (OMODRI SA)
54.8 × 57.6 mm194 parts8LBSD-3-Clause119
Similar boards
Cube batteryboard
willem-pennings
95 × 95 mm4 parts2LGPL-3.01.1k
Rp2040 encoder
Twisted-Fields
36.7 × 33.3 mm10 parts2LCustom license417
VESC Controller
paltatech
160 × 90 mm908 parts2LNo license354
${BOARD NAME} Assembly
EPFLXplore
45 × 43.5 mm21 parts4LApache-2.0345
OpenESC-20x20
OpenDrone-hw
31.2 × 33 mm180 parts6LCERN-OHL-S-2.0243
Legacy stepper motor analyzer
zapta
96.7 × 66.4 mm28 parts2LCC0-1.0163