
98 open source boards using the BMI088
Real designs built with the BMI088, from public GitHub projects: a quick way to see how others power, decouple and connect it. Each board comes with its KiCad files, full parts list and a render — and you can simulate its firmware on HardLabs.
 STM32
LittleBrain-STM32F4-Sensorboard
pms67
55 × 55 mm82 parts4LNo license337 STM32
NxtPX4V2
ArduPilot
33 × 27 mm122 parts4LNo license244
Open MOtor DRiver Initiative (OMODRI)
open-dynamic-robot-initiative
50 × 50 mm253 parts8LBSD-3-Clause122
Elec RPI Robot HAT
pollen-robotics
65 × 30.9 mm122 parts4LApache-2.0108 STM32
Oresat adcs card
oresat
99.8 × 94.6 mm579 parts4LGPL-2.021 STM32
Main Board
Terrapin-Rocket-Team
71 × 66 mm87 parts4LNo license17 STM32
Flight-Computer
ImperialSpaceSociety
28.1 × 76.1 mm57 parts4LNo license11 ESP32
Dronemagnav
ajisrawi
64 × 60 mm56 parts4LCustom license11
OpenJetECU
yuchao86
100.1 × 60.2 mm187 parts4LGPL-3.08 STM32
Alturia
rckTom
45 × 24 mm96 parts4LCC-BY-NC-4.07 Microchip SAM
Allfc
peregrine-developments
50.8 × 81.3 mm136 parts4LMIT6 STM32
Elec Anything2EtherCAT
60 × 70.3 mm200 parts4LApache-2.04 STM32
Stm32f4xx minimal dev
amrithHN
70.8 × 70.8 mm74 parts4LGPL-3.04 STM32
TeleSTERN
shorlee
90 × 45 mm293 parts6LGPL-3.03 STM32
350 Flight controller
ThaoMinhHoang
98.7 × 104 mm233 parts4LNo license3 ESP32
CopterCat cm4
matveylapin
40 × 55 mm156 parts4LApache-2.03 STM32
Elec Poulpe 3d
45 × 86.6 mm211 parts4LApache-2.02 NXP
ADCS-Camera-Payload-Board
NortheasternSatelliteLab
88 × 94.5 mm194 parts4LNo license2 ESP32
Riskybirdv3
ucb-bar
58.3 × 58.3 mm172 parts4LNo license2 Microchip SAM
Mini rocket flight controller
AmitBarman99
73.7 × 49.3 mm108 parts4LNo license2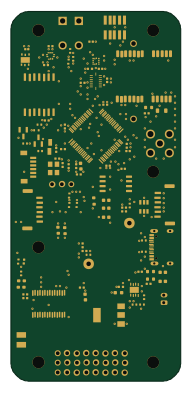 STM32
Ollyfc
rland93
45 × 98 mm101 parts4LMPL-2.02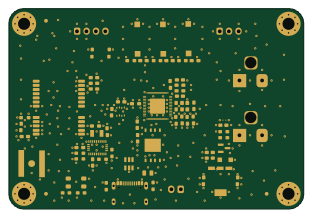 ESP32
Core System 2026
MarsRoverUdeGSpace
78 × 53 mm78 parts4LMIT2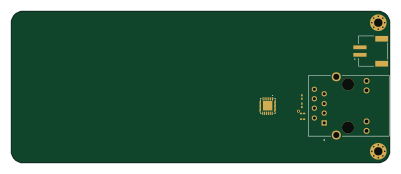 STM32
IMU Ethernet
embeddedalpha
100 × 40 mm62 parts2LNo license2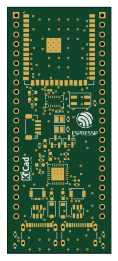 ESP32
Atlas-S3-DevBoard
OmkarKnkr
27.4 × 65.2 mm47 parts4LNo license2 STM32
Elec Poulpe 2d
59 × 73 mm194 parts4LApache-2.01 RP2040/RP2350
IGNRocketOrderFile
wasa-rockoon
170 × 73 mm182 parts2LMIT1 ESP32
CAN-HBC-S3
ViktorNfa
70 × 50 mm160 parts4LNo license1 ESP32
Tresvizo main
cadaritre
36 × 71.5 mm106 parts4LNo license1 STM32
Chromapi motherboard
Mowibox
88.1 × 59.4 mm105 parts4LApache-2.01 STM32
Jetson Xavier/Orin NX + PX4 Board
PranavNedunghat
139 × 57.4 mm478 parts8LApache-2.00 STM32
Pcb mantis
si-nalsal
125.2 × 90 mm277 parts6LCERN-OHL-S-2.00 ESP32
DroneMagNav2.0
128 × 84 mm218 parts4LCustom license0
Hades
david-who
100.1 × 60.2 mm187 parts4LBSD-3-Clause0 STM32
Fc h743
dvntekim
50 × 50 mm178 parts6LNo license0 STM32
OshTelemega
Kev1n8088
30 × 80 mm151 parts4LNo license0 STM32
Flightcontroller
ukinori
70 × 100 mm129 parts4LNo license0
How designs wire the BMI088
Read from the KiCad layouts of 74 open source designs, one per repository: what each pin of the BMI088 connects to, and the resistors, capacitors and other passives placed on it.
- The VDDIO pin has a decoupling capacitor on 67 of 72 designs, most often 100 nF (then 10 µF).
- The VDD pin has a decoupling capacitor on 65 of 74 designs, most often 100 nF (then 10 µF).
- The INT4 pin is left unconnected on 61 of 71 designs (a signal on 9).
- The INT2 pin is left unconnected on 58 of 74 designs (a signal on 15).
| Pin | Connected to | Parts on the pin |
|---|---|---|
| INT2pin 1 | Connected to: Not connected 78% · a signal 20% | — |
| NCpin 2 | Connected to: GND 60% · not connected 36% | — |
| VDDpin 3 | Connected to: 3.3V 78% · a signal 18% |
|
| GNDApin 4 | Connected to: GND 93% | — |
| GNDIOpin 6 | Connected to: GND 96% | — |
| PSpin 7 | Connected to: GND 63% · 3.3V 26% | — |
| VDDIOpin 11 | Connected to: 3.3V 79% · a signal 18% |
|
| INT4pin 13 | Connected to: Not connected 86% | — |
8 more pins vary from design to design. Connections count pins, parts count designs; values in brackets are how many parts had that value. Designs read include LittleBrain-STM32F4-Sensorboard by pms67, NxtPX4V2 by ArduPilot, Open MOtor DRiver Initiative (OMODRI) - Extension Board by open-dynamic-robot-initiative and Elec RPI Robot HAT by pollen-robotics.
The BMI088 in open source designs
The gallery holds 98 open source boards using the BMI088 from 75 GitHub repositories; a typical one measures about 55 × 57.2 mm and carries around 104 components.
80% use four copper layers or more, and 43% carry an open source license.
The most starred is LittleBrain-STM32F4-Sensorboard by pms67.
Parts used alongside the BMI088
Microcontrollers on boards using the BMI088
What boards using the BMI088 are built for
BMI088: common questions
Where can I find a BMI088 reference design?
Each of the 98 boards on this page is a real design using the BMI088. Open one to see how it is wired up, with the full BOM, a render of the layout and links to its KiCad files.
What decoupling capacitors do designs use on the BMI088 VDDIO pin?
The VDDIO pin has a decoupling capacitor on 67 of 72 designs, most often 100 nF (then 10 µF). Counted from the KiCad layouts of 74 open source designs using the BMI088.
What decoupling capacitors do designs use on the BMI088 VDD pin?
The VDD pin has a decoupling capacitor on 65 of 74 designs, most often 100 nF (then 10 µF). Counted from the KiCad layouts of 74 open source designs using the BMI088.
How is the BMI088 INT4 pin connected?
The INT4 pin is left unconnected on 61 of 71 designs (a signal on 9). Counted from the KiCad layouts of 74 open source designs using the BMI088.
What parts are used alongside the BMI088?
The USBLC6-2SC6, BMP388, AMS1117-3.3, BMP280 and W25Q128JVS appear in the most repositories here.
Which microcontrollers do boards using the BMI088 use?
Most are built on STM32 (47), ESP32 (17), Microchip SAM (5) and NXP (3).
How big is a typical board using the BMI088?
The median is 55 × 57.2 mm, and 20% are two-layer designs.
What is the most popular open source board using the BMI088?
By GitHub stars, LittleBrain-STM32F4-Sensorboard by pms67, with 337 stars.
Can I simulate one of these boards using the BMI088 before building it?
Yes. HardLabs turns a board's netlist and BOM into a working simulation, so you can boot and test firmware against it with no hardware on your desk.