
BLDC Driver 4.6

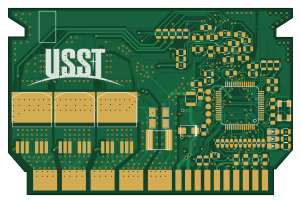
About the BLDC Driver 4.6 PCB
BLDC Driver 4.6 is an open source STM32 PCB design by UofSSpaceTeam, published on GitHub. It is a 2-layer board measuring 75.2 × 49.3 mm, with 112 components from 35 distinct parts.
Its main chip is the STM32F40X_LQFP64, from the STM32 family. Other key parts include the TC2117, DRV8302 and MCP2562FD. By type, the board carries 42 resistors, 41 capacitors, 6 transistors, 4 ICs, 4 diodes and 1 crystal.
It belongs with the robotics & motion designs in this gallery.
From the project
Hardware design files for the Rover project.
VESC -R ============= Forked from the VESC Open Source ESC Project (http://vedder.se/2015/01/vesc-open-source-esc/) This the Hardware for the USST's version of the VESC
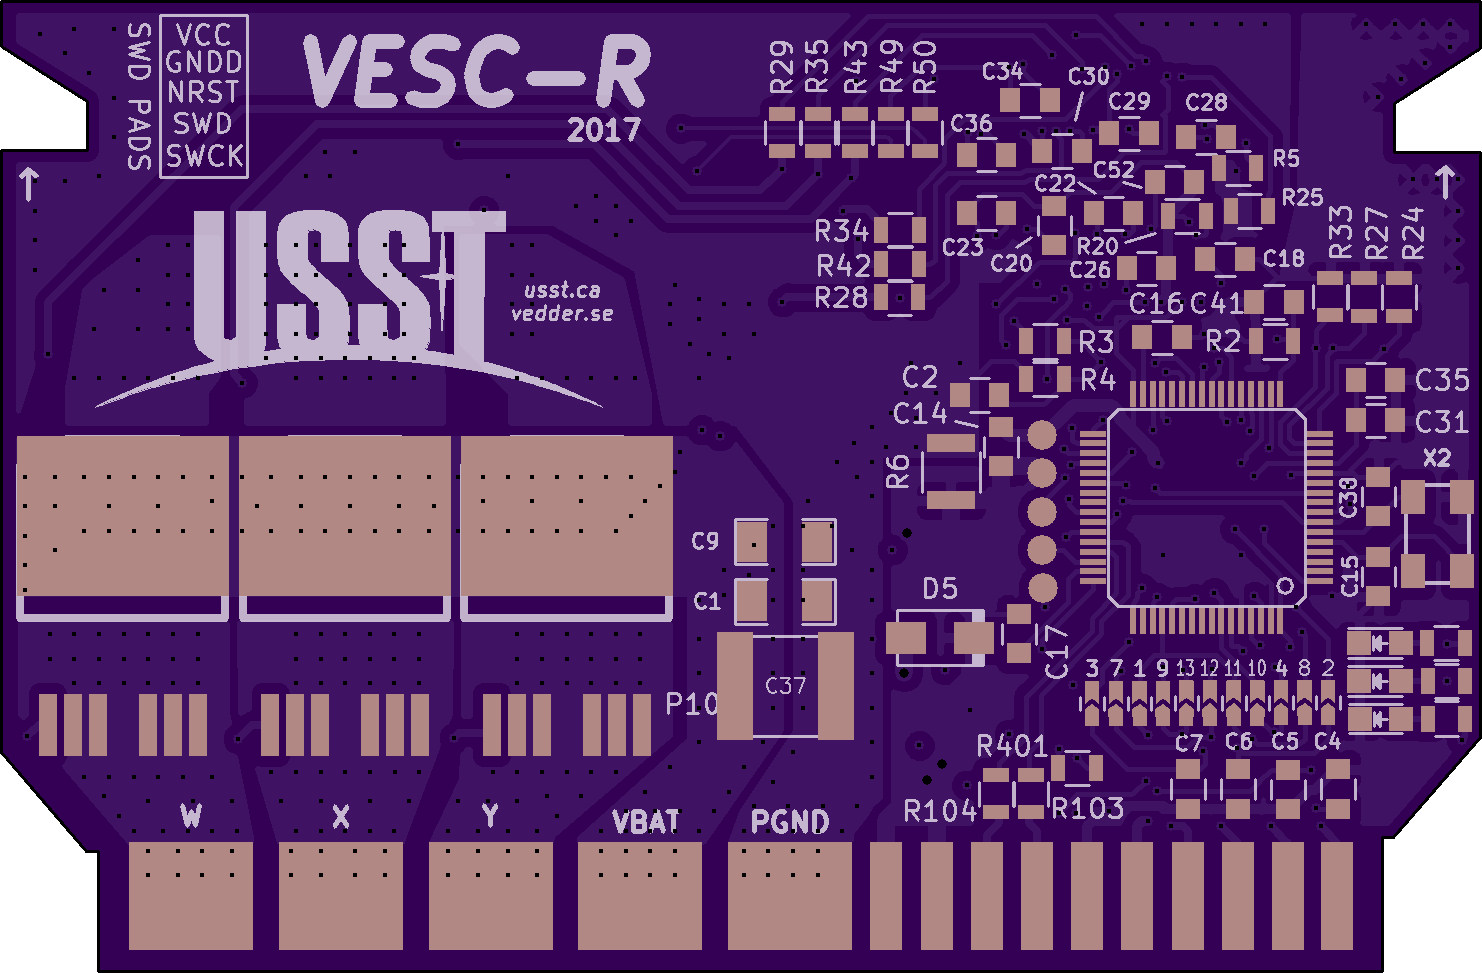
Main components on the BLDC Driver 4.6
BLDC Driver 4.6 bill of materials (BOM)
112 components, 35 distinct parts — part numbers from the project's BOM.
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 1 | STM32F40X_LQFP64 | lqfp64_pad_mod | U1 |
| 1 | TC2117 | SOT-223 | U2 |
| 1 | DRV8302 | TSSOP-56-PP | U3 |
| 1 | MCP2562FD | SOIC-8-W | U401 |
| 6 | IRFS7530 | D2PAK-7-GDS | Q1, Q2, Q3, Q4, Q5, Q6 |
| 1 | CRYSTAL_GROUND_PIN | Crystal_5x3mm | X2 |
| 1 | AMP17614426-2_EDGE | TE2007088-1_Edge_Long | P10 |
| 13 | Jumper_NC_Small | J_0603 | 1, 2, 3, 4, 5, 6, 7, 8 +5 |
| 1 | GREEN | LED_0805 | D1 |
| 1 | RED | LED_0805 | D2 |
| 1 | LED | LED_0805 | D3 |
| 1 | TVS 5V | do214ac | D5 |
| 7 | 10u,50V | SMD-1206 | C1, C8, C9, C40, C43, C44, C49 |
| 2 | 100n | C_0805 | C2, C32 |
| 4 | 4n7 | C_0805 | C4, C5, C6, C7 |
| 17 | 2.2u | C_0805 | C10, C11, C12, C13, C14, C16, C17, C18 +9 |
| 2 | 15p | C_0805 | C15, C38 |
| 1 | 22n | C_0805 | C22 |
| 1 | 100u | c_tant_B | C25 |
| 3 | 220n | C_0805 | C28, C29, C30 |
Show 15 more
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 2 | 2.2n | C_0805 | C34, C36 |
| 1 | 15u,100V | c_2220 | C37 |
| 1 | 15u, 100v | c_2220 | C51 |
| 1 | NTC 10k | R_0805 | R1 |
| 6 | 10k | R_0805 | R2, R7, R8, R9, R10, R20 |
| 7 | 39k | R_0805 | R3, R23, R26, R30, R32, R36, R46 |
| 8 | 2k2 | R_0805 | R4, R11, R12, R13, R22, R24, R27, R33 |
| 1 | 1k | R_0805 | R5 |
| 1 | 0 | R_1210 | R6 |
| 1 | 1M | R_0805 | R25 |
| 6 | 4R7 | R_0805 | R28, R29, R34, R35, R42, R43 |
| 6 | 100R | R_0805 | R37, R38, R48, R49, R50, R51 |
| 2 | SHUNT | WSLP2726 | R53, R54 |
| 2 | 22R | R_0805 | R103, R104 |
| 1 | NI | R_0805 | R401 |
BLDC Driver 4.6 design files
The KiCad project lives in the UofSSpaceTeam/rover-hardware repository on GitHub; these links point at the commit this page was built from.
BLDC Driver 4.6: common questions
What microcontroller does the BLDC Driver 4.6 use?
The BLDC Driver 4.6 is built around the STM32F40X_LQFP64, from the STM32 family.
How big is the BLDC Driver 4.6 PCB?
The BLDC Driver 4.6 measures 75.2 × 49.3 mm, has 2 copper layers and is 1.6 mm thick.
How many components are on the BLDC Driver 4.6?
112 components, from 35 distinct parts, with part numbers taken from the project's own BOM. The full bill of materials is listed on this page.
Where can I download the BLDC Driver 4.6 design files?
From the UofSSpaceTeam/rover-hardware repository on GitHub, which has the KiCad layout and the BOM; the links under Design files point to each one.
Can I use the BLDC Driver 4.6 design in my own project?
The repository has no license, so all rights stay with UofSSpaceTeam. Use it as a reference, and ask the author before reusing the design.
Can I test firmware for the BLDC Driver 4.6 without the hardware?
Yes. HardLabs builds a simulation of the board from its netlist and BOM, so you can run and debug STM32 firmware against it before you order a PCB.
More boards in rover-hardware
USSTCM
280.6 × 229.7 mm139 partsNo license5
TUSB2077A USB hub
87.6 × 70 mm86 parts2LNo license5 Microchip SAM
PowerBoardV4
183.1 × 108 mm74 parts2LNo license5 AVR/Arduino
DriveControllerLogic
85.6 × 51.9 mm66 parts2LNo license5
VESC Card Backplane
82 × 129.8 mm42 parts2LNo license5 AVR/Arduino
ArmPowerBoardV3
148.3 × 98.6 mm32 parts2LNo license5
PiMainboard
116 × 72.3 mm32 parts2LNo license5
VESC Hub
75 × 75 mm32 parts2LNo license5 STM32
Power Board V-5.0
180.9 × 110.2 mm29 parts2LNo license5 NXP
CustomTeensy
45.7 × 55.9 mm25 parts2LNo license5
VESC Card Breakout
67.1 × 33.5 mm9 parts2LNo license5
Similar boards
 STM32
LumenPnP Motherboard
opulo-inc
149 × 95 mm296 parts4LCC-BY-SA-4.03.7k STM32
AxxSolder
AxxAxx
39 × 82.5 mm122 parts2LGPL-3.01.7k STM32
LibreVNA
jankae
122 × 98 mm592 parts6LGPL-3.01.6k STM32
AIOC
skuep
21 × 31.5 mm47 parts2LMIT1.4k STM32
Ferris
pierrechevalier83
208.8 × 86.8 mm102 parts2LSHL-2.11.3k STM32
176 pin board
rusefi
61.8 × 73.2 mm76 parts2LGPL-3.01.2k