
Robot

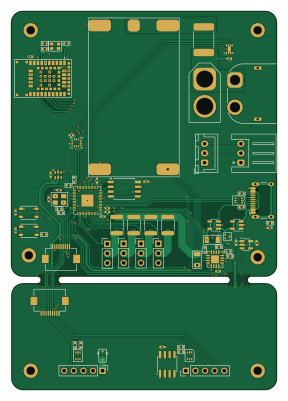
About the Robot PCB
Robot is an open source RP2040/RP2350 PCB design by dyu134, published on GitHub. It is a 2-layer board measuring 70.1 × 100 mm, with 78 components from 43 distinct parts.
Its main chip is the RP2040, from the RP2040/RP2350 family. Other key parts include the W25Q16JVSS, MAX40200AUK, UBEC-5V, MAX17049 and LSM6DSV16X. By type, the board carries 21 resistors, 18 capacitors, 11 ICs, 8 connectors, 5 fuses and 5 diodes.
It belongs with the robotics & motion and sensors designs in this gallery.
From the project
The Robot sub-module is a high-performance actuator and sensing expansion board for the ESP-HI-PLUS, designed to transform the device into a mobile or interactive robotic platform. Powered by an RP2040 MCU, it handles real-time motor control, battery management, and inertial sens
The Robot sub-module is a high-performance actuator and sensing expansion board for the ESP-HI-PLUS, designed to transform the device into a mobile or interactive robotic platform. Powered by an RP2040 MCU, it handles real-time motor control, battery management, and inertial sensing.
- RP2040 (U3) — Dual-core ARM Cortex-M0+ microcontroller for real-time servo PWM generation and sensor processing. - 16 Mbit Flash (U?) — Storage for RP2040 firmware.
Main components on the Robot
Robot bill of materials (BOM)
78 components, 43 distinct parts — part numbers from the project's BOM.
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 1 | W25Q16JVSS | SOIC-8_5.3x5.3mm_P1.27mm | U1 |
| 2 | MAX40200AUK | SOT-23-5 | U2, U5 |
| 1 | RP2040 | QFN-56-1EP_7x7mm_P0.4mm_EP3.2x3.2mm | U3 |
| 1 | UBEC-5V | UBEC-5V | U4 |
| 1 | MAX17049 | DFN-8_2x2mm_P0.5mm_EP1.2x0.8mm | U6 |
| 1 | LSM6DSV16X | LGA14_LSM6_STM | U7 |
| 1 | TLV75733PDBV | SOT-23-5 | U8 |
| 1 | INA3221 | Texas_RGV0016A_VQFN-16-1EP_4x4mm_P0.65mm_EP2.1x2.1mm | U9 |
| 1 | AT24CS02-SSHM | SOIC-8_3.9x4.9mm_P1.27mm | U10 |
| 1 | NINA-B416 | NINA_LGA71R_1500X1000X223_PCB | U11 |
| 4 | MG996R | PinHeader_1x03_P2.54mm_Vertical | M1, M2, M3, M4 |
| 1 | NTK3139P | SOT-723 | Q1 |
| 1 | ABM8-272-T3 | Crystal_SMD_3225-4Pin_3.2x2.5mm | Y1 |
| 1 | USB_C_RECEPTACLE_USB2.0_14P USB_C_Receptacle_USB2.0_14P | USB_C_Receptacle_HCTL_HC-TYPE-C-16P-01A | J1 |
| 1 | JST-XH | JST_XH_S3B-XH-A_1x03_P2.50mm_Horizontal | J2 |
| 1 | XT60 | AMASS_XT60PW-M_1x02_P7.20mm_Horizontal | J3 |
| 1 | JST-XH | JST_XH_B3B-XH-A_1x03_P2.50mm_Vertical | J4 |
| 2 | PR5L5015-5P-C-H | PinHeader_1x05_P2.54mm_Vertical | J5, J6 |
| 2 | CONN_01X10_MOUNTINGPIN Conn_01x10_MountingPin | Hirose_FH12-10S-0.5SH_1x10-1MP_P0.50mm_Horizontal | J7, J8 |
| 1 | 2S/10C ~1500mAh | AMASS_XT60-F_1x02_P7.20mm_Vertical | BT1 |
Show 23 more
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 1 | 2920L1000SL21GRG | Fuse_2920_7451Metric | F1 |
| 4 | BSMD1812-200-30V | Fuse_1812_4532Metric | F2, F3, F4, F5 |
| 2 | SKRPACE010 | SW_Push_1P1T_NO_Vertical_Wuerth_434133025816 | SW1, SW2 |
| 1 | Broadcom_ASMB-KTF0-0A306 | LED_ASMB-KTF0-0A306 | LED1 |
| 1 | SK9822-EC20 | APA102_2020-6Pin | D1 |
| 3 | USBLC6-2P6 | SOT-666 | D2, D4, D5 |
| 1 | PMEG4010CEJ | D_SOD-323F | D3 |
| 1 | 4N7 4n7 | C_0402_1005Metric | C1 |
| 4 | 1u | C_0402_1005Metric | C2, C4, C11, C16 |
| 8 | 0U1 0u1 | C_0402_1005Metric | C3, C5, C6, C7, C10, C12, C13, C17 |
| 2 | 15P 15p | C_0402_1005Metric | C8, C9 |
| 2 | 10U 10u | C_0402_1005Metric | C14, C15 |
| 1 | 0u1 | C_0402_1005Metric | C18 |
| 1 | 1M | R_0402_1005Metric | R1 |
| 2 | 1k | R_0402_1005Metric | R2, R5 |
| 2 | 5K1 5k1 | R_0402_1005Metric | R3, R4 |
| 2 | 4K7 4k7 | R_0402_1005Metric | R6, R7 |
| 1 | 5m | R_1206_3216Metric | R8 |
| 1 | 100M 100m | R_1206_3216Metric | R9 |
| 4 | 10K 10k | R_0402_1005Metric | R10, R16, R17, R18 |
| 1 | 953K 953k | R_0402_1005Metric | R11 |
| 4 | 100 | R_0402_1005Metric | R12, R13, R14, R15 |
| 3 | 150 | R_0402_1005Metric | R19, R20, R21 |
Robot design files
The KiCad project lives in the dyu134/ESP-HI-PLUS repository on GitHub; these links point at the commit this page was built from.
Robot: common questions
What microcontroller does the Robot use?
The Robot is built around the RP2040, from the RP2040/RP2350 family.
How big is the Robot PCB?
The Robot measures 70.1 × 100 mm, has 2 copper layers and is 1.6 mm thick.
How many components are on the Robot?
78 components, from 43 distinct parts, with part numbers taken from the project's own BOM. The full bill of materials is listed on this page.
Where can I download the Robot design files?
From the dyu134/ESP-HI-PLUS repository on GitHub, which has the KiCad layout, the schematic and the BOM; the links under Design files point to each one.
Can I use the Robot design in my own project?
The repository has no license, so all rights stay with dyu134. Use it as a reference, and ask the author before reusing the design.
Can I test firmware for the Robot without the hardware?
Yes. HardLabs builds a simulation of the board from its netlist and BOM, so you can run and debug RP2040/RP2350 firmware against it before you order a PCB.
More boards in ESP-HI-PLUS
Similar boards
 RP2040/RP2350
Open Book Abridged Edition
joeycastillo
85 × 115 mm29 parts2LCC-BY-SA-4.08.1k RP2040/RP2350
Corne
foostan
277.2 × 107.5 mm164 parts2LCC-BY-4.07.7k RP2040/RP2350
Corne
277.2 × 107.5 mm164 parts2LCC-BY-4.07.7k RP2040/RP2350
Open Source Smart Glasses
Mentra-Community
93 × 10.5 mm80 parts4LMIT1.2k RP2040/RP2350
MSA
30.5 × 138 mm61 parts2LMIT1.2k RP2040/RP2350
Msa
47.8 × 9.4 mm53 parts2LMIT1.2k