
Remote omnidirection droid v0.1

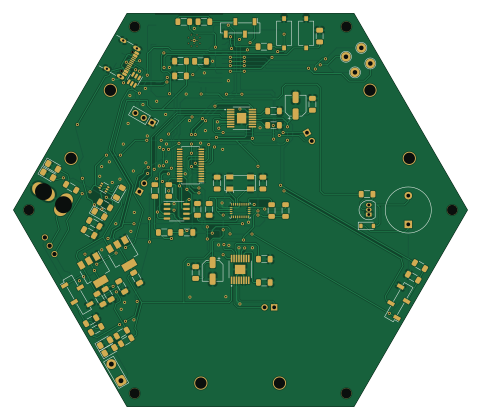
About the Remote omnidirection droid v0.1 PCB
Remote omnidirection droid v0.1 is an open source ESP32 PCB design by eloicote, published on GitHub under the GPL-3.0 license. It is a 2-layer board measuring 120 × 103.9 mm, with 79 components from 36 distinct parts.
Its main chip is the ESP32-S3-WROOM-2-N32R8V, from the ESP32 family. Other key parts include the AZ1117-3.3, AZ1117-5.0, USBLC6-2SC6, PCA9685PW and BNO055. By type, the board carries 24 resistors, 18 capacitors, 7 ICs, 7 diodes, 6 connectors and 3 modules.
It belongs with the robotics & motion designs in this gallery.
From the project
ESP32 based freemoving drone with a camera for FPV which utilizes three omniwheels in a delta formation to move freely in 3 dimensions
Main components on the Remote omnidirection droid v0.1
Remote omnidirection droid v0.1 bill of materials (BOM)
79 components, 36 distinct parts.
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 1 | AZ1117-3.3 | SOT-223-3_TabPin2 | U1 |
| 1 | AZ1117-5.0 | SOT-223-3_TabPin2 | U2 |
| 1 | USBLC6-2SC6 | SOT-23-6 | U3 |
| 1 | ESP32-S3-WROOM-2-N32R8V | XCVR_ESP32-S3-WROOM-2-N32R8V | U4 |
| 1 | PCA9685PW | TSSOP-28_4.4x9.7mm_P0.65mm | U5 |
| 1 | BNO055 | LGA-28_5.2x3.8mm_P0.5mm | U6 |
| 1 | PCA9306D | SO-8_3.9x4.9mm_P1.27mm | U7 |
| 3 | Motor_DC_ALT | Pimoroni_Motor_Breakout | M1, M2, M3 |
| 1 | BC846BS | SOT-363_SC-70-6 | Q1 |
| 1 | 2N2219 | TO-92L_Inline | Q2 |
| 1 | 32.768kHz | Crystal_SMD_Abracon_ABS25-4Pin_8.0x3.8mm | Y1 |
| 1 | USB_C_Receptacle_USB2.0 | USB_C_Receptacle_GCT_USB4105-xx-A_16P_TopMnt_Horizontal | J1 |
| 3 | Conn_01x04 | PinSocket_1x04_P2.54mm_Vertical_SMD_Pin1Left | J2, J4, J5 |
| 1 | BATT_CONNECT | Deans T-Plug Header | J3 |
| 1 | Conn_01x03 | PinHeader_1x03_P2.54mm_Vertical | J6 |
| 1 | Buzzer | Buzzer_12x9.5RM7.6 | BZ1 |
| 4 | TestPoint | TestPoint_THTPad_D2.5mm_Drill1.2mm | IO15, IO16, IO17, IO18 |
| 2 | DRV8411 | PWP0016C-IPC_A | MD1, MD2 |
| 2 | SW_SPST | SW_Tactile_SPST_NO_Straight_CK_PTS636Sx25SMTRLFS | SW1, SW2 |
| 1 | SW_SPDT | SWITCH_25336NA_APM | SW3 |
Show 16 more
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 1 | AMMETER_CONN | TestPoint_2Pads_Pitch5.08mm_Drill1.3mm | TP1 |
| 2 | MSK4005 | D_1206_3216Metric_Pad1.42x1.75mm_HandSolder | D1, D5 |
| 4 | LED | LED_1206_3216Metric_Pad1.42x1.75mm_HandSolder | D2, D3, D4, D6 |
| 1 | 1N4148W | D_SOD-123 | D7 |
| 7 | 22u | C_1206_3216Metric_Pad1.33x1.80mm_HandSolder | C1, C2, C6, C7, C9, C14, C15 |
| 5 | 0.1u | C_1206_3216Metric_Pad1.33x1.80mm_HandSolder | C3, C4, C8, C16, C17 |
| 2 | 10u | C_1206_3216Metric_Pad1.33x1.80mm_HandSolder | C5, C18 |
| 2 | 100n | C_1206_3216Metric_Pad1.33x1.80mm_HandSolder | C10, C12 |
| 2 | 10u | CP_Elec_5x5.3 | C11, C13 |
| 2 | 5.1k | R_1206_3216Metric_Pad1.30x1.75mm_HandSolder | R1, R2 |
| 1 | 100k | R_1206_3216Metric_Pad1.30x1.75mm_HandSolder | R3 |
| 4 | 220 | R_1206_3216Metric_Pad1.30x1.75mm_HandSolder | R4, R5, R6, R9 |
| 11 | 10k | R_1206_3216Metric_Pad1.30x1.75mm_HandSolder | R7, R8, R10, R11, R12, R13, R14, R15 +3 |
| 4 | 22k | R_1206_3216Metric_Pad1.30x1.75mm_HandSolder | R17, R18, R19, R20 |
| 1 | 200k | R_1206_3216Metric_Pad1.30x1.75mm_HandSolder | R23 |
| 1 | 180 | R_1206_3216Metric_Pad1.30x1.75mm_HandSolder | R24 |
Remote omnidirection droid v0.1 design files
The KiCad project lives in the eloicote/remote_omnidirectional_droid repository on GitHub; these links point at the commit this page was built from.
Remote omnidirection droid v0.1: common questions
What microcontroller does the Remote omnidirection droid v0.1 use?
The Remote omnidirection droid v0.1 is built around the ESP32-S3-WROOM-2-N32R8V, from the ESP32 family.
How big is the Remote omnidirection droid v0.1 PCB?
The Remote omnidirection droid v0.1 measures 120 × 103.9 mm, has 2 copper layers and is 1.6 mm thick.
How many components are on the Remote omnidirection droid v0.1?
79 components, from 36 distinct parts. The full bill of materials is listed on this page.
Where can I download the Remote omnidirection droid v0.1 design files?
From the eloicote/remote_omnidirectional_droid repository on GitHub, which has the KiCad layout and the schematic; the links under Design files point to each one.
Can I use the Remote omnidirection droid v0.1 design in my own project?
Yes, under the terms of its GPL-3.0 license, which eloicote chose for the repository.
Can I test firmware for the Remote omnidirection droid v0.1 without the hardware?
Yes. HardLabs builds a simulation of the board from its netlist and BOM, so you can run and debug ESP32 firmware against it before you order a PCB.
More boards in remote_omnidirectional_droid

Similar boards
 ESP32
Open Book Abridged Edition
joeycastillo
85 × 115 mm65 parts2LCC-BY-SA-4.08.1k ESP32
Badge
atopile
56.3 × 39 mm239 parts4LMIT4.0k ESP32
Esp32 minimal
36.2 × 26.8 mm20 parts2LMIT4.0k ESP32
Racer
StuckAtPrototype
36 × 50.2 mm70 parts4LApache-2.03.8k ESP32
Controller
29 × 74 mm58 parts4LApache-2.03.8k ESP32
Bitaxe
skot
56.5 × 99.8 mm86 parts4LCERN-OHL-S-2.01.4k