
2026 12 2Wheel Balance Robot v1

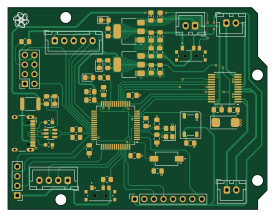
About the 2026 12 2Wheel Balance Robot v1 PCB
2026 12 2Wheel Balance Robot v1 is an open source RP2040/RP2350 PCB design by gfm16617, published on GitHub. It is a 2-layer board measuring 68.6 × 53.4 mm, with 56 components from 41 distinct parts.
Its main chip is the RP2040, from the RP2040/RP2350 family. Other key parts include the NCP1117IST33T3G, W25Q128JVSIM, USBLC6-2SC6 and LD1117S33TR_SOT223. By type, the board carries 22 capacitors, 10 resistors, 9 connectors, 5 ICs, 5 diodes and 3 switches.
It belongs with the robotics & motion designs in this gallery.
Main components on the 2026 12 2Wheel Balance Robot v1
2026 12 2Wheel Balance Robot v1 bill of materials (BOM)
56 components, 41 distinct parts — part numbers from the project's BOM.
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 1 | NCP1117IST33T3G STM32F401RBTx | LQFP-64_10x10mm_P0.5mm | U1 |
| 1 | RP2040 TB6612FNG | SSOP-24_5.3x8.2mm_P0.65mm | U2 |
| 1 | W25Q128JVSIM LD1117S50TR_SOT223 | SOT-223-3_TabPin2 | U3 |
| 1 | USBLC6-2SC6 | SOT-23-6 | U5 |
| 1 | LD1117S33TR_SOT223 | SOT-223-3_TabPin2 | U6 |
| 1 | 16MHz ABRACON | Crystal_SMD_Abracon_ABM8G-4Pin_3.2x2.5mm | Y3 |
| 1 | CONN_01X02 Conn_01x04 | PinHeader_1x04_P2.54mm_Vertical | J1 |
| 1 | 10118194-0001LF CONN_MPU6050 | PinSocket_1x08_P2.54mm_Vertical | J2 |
| 1 | CONN_01X15 USB_C_Receptacle_USB2.0_14P Same Sky | USB_C_Receptacle_HCTL_HC-TYPE-C-16P-01A | J3 |
| 1 | CONN_01X15 ESP_Conn | PinSocket_2x04_P2.54mm_Vertical | J4 |
| 1 | BATT_CONN | JST_XH_B2B-XH-A_1x02_P2.50mm_Vertical | J5 |
| 1 | M1_CONN | JST_XH_B2B-XH-A_1x02_P2.50mm_Vertical | J6 |
| 1 | M2_CONN | JST_XH_B2B-XH-A_1x02_P2.50mm_Vertical | J7 |
| 1 | ENCODER_CONN | JST_XH_B4B-XH-A_1x04_P2.50mm_Vertical | J8 |
| 1 | MT6701_CONN | JST_XH_B5B-XH-A_1x05_P2.50mm_Vertical | J9 |
| 1 | PTCSMD | Fuse_1812_4532Metric | F1 |
| 1 | REGULATOR_SWITCH | SW_SLW-66527511-SMT-TR | S3 |
| 1 | RST_SWITCH | SW_SLW-66527511-SMT-TR | S4 |
| 1 | SW_uP_Reset Wurth Elektronik | SW_uP_Reset | SW2 |
| 1 | IN-S42BTR WS2812B | LED_WS2812B_PLCC4_5.0x5.0mm_P3.2mm | D1 |
Show 21 more
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 1 | USB_LED | LED_0805_2012Metric_Pad1.15x1.40mm_HandSolder | D2 |
| 1 | 3V3_LED | LED_0805_2012Metric_Pad1.15x1.40mm_HandSolder | D3 |
| 1 | USER_LED | LED_0805_2012Metric_Pad1.15x1.40mm_HandSolder | D4 |
| 1 | 5V_LED | LED_0805_2012Metric_Pad1.15x1.40mm_HandSolder | D5 |
| 2 | 04024D106MAT2A 0.1uF | C_0805_2012Metric_Pad1.18x1.45mm_HandSolder | C1, C2 |
| 5 | 0402YC104KAT2A 0.1uF | C_0805_2012Metric_Pad1.18x1.45mm_HandSolder | C3, C4, C6, C8, C14 |
| 1 | 0402YC104KAT2A 2.2uF | C_0805_2012Metric_Pad1.18x1.45mm_HandSolder | C7 |
| 1 | 0402YC104KAT2A 10uF | CP_EIA-6032-28_Kemet-C_HandSolder | C9 |
| 1 | C0402C105K9PAC 0.1uF | C_0805_2012Metric_Pad1.18x1.45mm_HandSolder | C13 |
| 1 | 0402YC104KAT2A 10uF | C_0805_2012Metric_Pad1.18x1.45mm_HandSolder | C15 |
| 1 | C0402C100J3GACAUTO 10uF | C_0805_2012Metric_Pad1.18x1.45mm_HandSolder | C16 |
| 1 | C0402C100J3GACAUTO 0.1uF | C_0805_2012Metric_Pad1.18x1.45mm_HandSolder | C17 |
| 3 | 10uF KEMET | C_0805_2012Metric_Pad1.18x1.45mm_HandSolder | C18, C23, C25 |
| 2 | 22p KYOCERA AVX | C_0805_2012Metric_Pad1.18x1.45mm_HandSolder | C19, C20 |
| 1 | 0.01uF KYOCERA AVX | C_0805_2012Metric_Pad1.18x1.45mm_HandSolder | C21 |
| 3 | 0.1uF | C_0805_2012Metric_Pad1.18x1.45mm_HandSolder | C22, C24, C26 |
| 2 | CRT0402-BY-1001GLF 1k | R_0805_2012Metric_Pad1.20x1.40mm_HandSolder | R1, R6 |
| 2 | 10k | R_0805_2012Metric_Pad1.20x1.40mm_HandSolder | R2, R17 |
| 2 | RCS040227R0FKED 22R | R_0805_2012Metric_Pad1.20x1.40mm_HandSolder | R3, R4 |
| 2 | 5.1k Vishay / Dale | R_0603_1608Metric_Pad0.98x0.95mm_HandSolder | R7, R8 |
| 2 | 1k | R_0805_2012Metric_Pad1.20x1.40mm_HandSolder | R9, R10 |
2026 12 2Wheel Balance Robot v1 design files
The KiCad project lives in the gfm16617/EngrEDU_Website repository on GitHub; these links point at the commit this page was built from.
- LayoutClass_Projects/Embedded_Systems/2026_12_2Wheel_Balance_Robot_v1/2026_12_2Wheel_Balance_Robot_v1.kicad_pcb
- SchematicClass_Projects/Embedded_Systems/2026_12_2Wheel_Balance_Robot_v1/2026_12_2Wheel_Balance_Robot_v1.kicad_sch
- BOMClass_Projects/Embedded_Systems/2024_June_RP2040/BOM/T-H98W334638A-5sets-2024_June_RP2040_BOM(2024-07-01).xls
2026 12 2Wheel Balance Robot v1: common questions
What microcontroller does the 2026 12 2Wheel Balance Robot v1 use?
The 2026 12 2Wheel Balance Robot v1 is built around the RP2040, from the RP2040/RP2350 family.
How big is the 2026 12 2Wheel Balance Robot v1 PCB?
The 2026 12 2Wheel Balance Robot v1 measures 68.6 × 53.4 mm, has 2 copper layers and is 1.6 mm thick.
How many components are on the 2026 12 2Wheel Balance Robot v1?
56 components, from 41 distinct parts, with part numbers taken from the project's own BOM. The full bill of materials is listed on this page.
Where can I download the 2026 12 2Wheel Balance Robot v1 design files?
From the gfm16617/EngrEDU_Website repository on GitHub, which has the KiCad layout, the schematic and the BOM; the links under Design files point to each one.
Can I use the 2026 12 2Wheel Balance Robot v1 design in my own project?
The repository has no license, so all rights stay with gfm16617. Use it as a reference, and ask the author before reusing the design.
Can I test firmware for the 2026 12 2Wheel Balance Robot v1 without the hardware?
Yes. HardLabs builds a simulation of the board from its netlist and BOM, so you can run and debug RP2040/RP2350 firmware against it before you order a PCB.
More boards in EngrEDU_Website
 STM32
2026 STM32H7 FPAA v1
68.6 × 53.3 mm91 parts4LNo license3 RP2040/RP2350
2026 ESP32 FPAA v3
68.6 × 53.3 mm82 parts4LNo license3 RP2040/RP2350
VCO PCB B REV2
81.3 × 100 mm52 parts2LNo license3 RP2040/RP2350
Levitation Analog v1
90 × 55 mm44 parts2LNo license3
Daisy Seed POD v1
90 × 60 mm44 parts2LNo license3
Uno Shield DSP Class v1
83.8 × 53.3 mm44 parts2LNo license3 RP2040/RP2350
2024 11 STM32F303 DaisyShape v1 3
61 × 22.5 mm31 parts4LNo license3 RP2040/RP2350
AudioMixer Duo LBB
100 × 85.3 mm27 parts2LNo license3
FPAA Starter Board
49.3 × 33 mm24 parts4LNo license3
2024 ECG FinalProject
72.3 × 39.6 mm21 parts2LNo license3 RP2040/RP2350
AudioMixer LBB
95 × 60 mm21 parts2LNo license3
Similar boards
 RP2040/RP2350
Open Book Abridged Edition
joeycastillo
85 × 115 mm29 parts2LCC-BY-SA-4.08.1k RP2040/RP2350
Corne
foostan
277.2 × 107.5 mm164 parts2LCC-BY-4.07.7k RP2040/RP2350
Corne
277.2 × 107.5 mm164 parts2LCC-BY-4.07.7k RP2040/RP2350
LogicAnalyzer
gusmanb
57 × 55.2 mm6 parts2LGPL-3.05.0k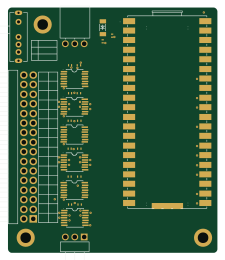 RP2040/RP2350
Jitx design
55.5 × 65 mm26 parts4LGPL-3.05.0k RP2040/RP2350
Pro V2
kata0510
290.1 × 130 mm270 parts2LMIT2.3k