
Rallybot

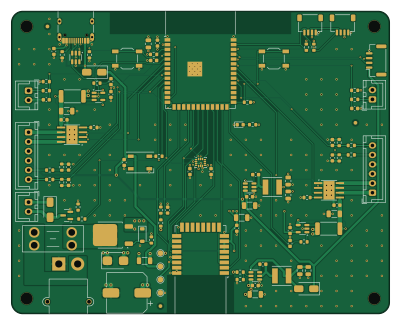
About the Rallybot PCB
Rallybot is an open source ESP32 PCB design by lois-goon, published on GitHub under the MIT license. It is a 4-layer board measuring 100 × 80 mm, with 103 components from 48 distinct parts.
Its main chip is the ESP32-S3-WROOM-1-N16R8, from the ESP32 family. Other key parts include the AP63205WU-7, AP63203WU-7, USBLC6-2SC6, LSM6DSLTR and DWM3000. By type, the board carries 36 capacitors, 33 resistors, 10 ICs, 10 connectors, 7 diodes and 2 transistors.
It belongs with the iot & wireless, power & battery and sensors designs in this gallery.
From the project
The main board of RallyBot, an autonomous robot that collects tennis balls. It drives two DC wheel motors with encoders and the intake roller, runs the localization and the mission on an ESP32-S3, ranges to the court anchors with a UWB module and reads an IMU, two time-of-flight
The main board of RallyBot, an autonomous robot that collects tennis balls. It drives two DC wheel motors with encoders and the intake roller, runs the localization and the mission on an ESP32-S3, ranges to the court anchors with a UWB module and reads an IMU, two time-of-flight sensors, two bumpers and a camera board.
The board is the hardware the RallyBot control stack simulates: encoder increments, a biased gyro, UWB ranges to four anchors and 12 V motors behind current-limited H-bridges.
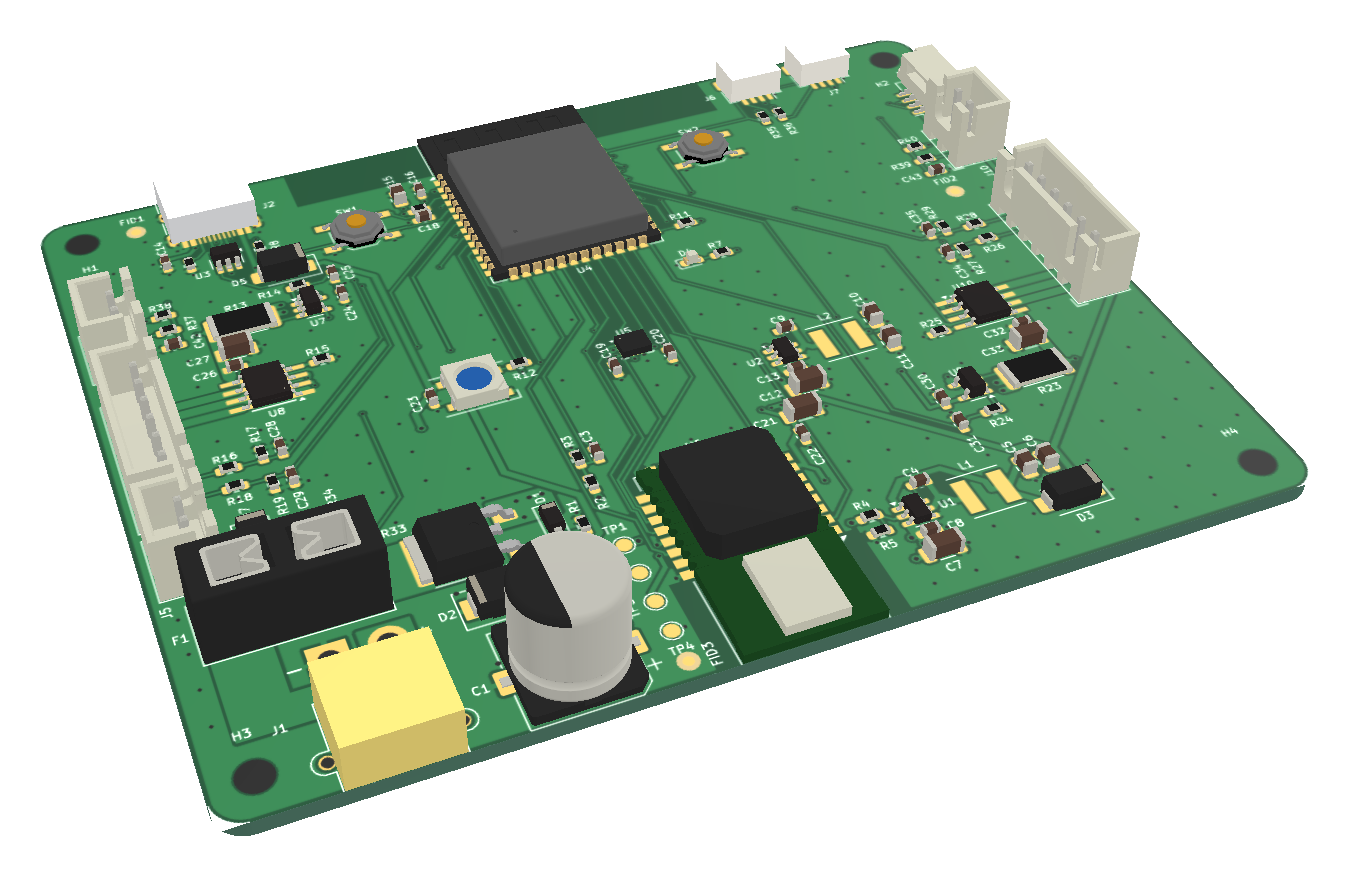
Main components on the Rallybot
Rallybot bill of materials (BOM)
103 components, 48 distinct parts — part numbers from the project's BOM.
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 1 | AP63205WU-7 AP63205WU Diodes Inc | TSOT-23-6 | U1 |
| 1 | AP63203WU-7 AP63203WU Diodes Inc | TSOT-23-6 | U2 |
| 1 | USBLC6-2SC6 ST | SOT-23-6 | U3 |
| 1 | ESP32-S3-WROOM-1-N16R8 Espressif | ESP32-S3-WROOM-1 | U4 |
| 1 | LSM6DSLTR LSM6DSL ST | LGA-14_3x2.5mm_P0.5mm_LayoutBorder3x4y | U5 |
| 1 | DWM3000 Qorvo | DWM1000 | U6 |
| 2 | INA180A2IDBVR INA180A2 TI | SOT-23-5 | U7, U9 |
| 2 | DRV8871DDAR DRV8871DDA TI | Texas_HTSOP-8-1EP_3.9x4.9mm_P1.27mm_EP2.95x4.9mm_Mask2.4x3.1mm_ThermalVias | U8, U10 |
| 1 | AOD4185 Alpha & Omega | TO-252-2 | Q1 |
| 1 | AO3400A Alpha & Omega | SOT-23 | Q2 |
| 1 | XT30PW-M AMASS | AMASS_XT30PW-M_1x02_P2.50mm_Horizontal | J1 |
| 1 | TYPE-C-31-M-12 USB-C Korean Hroparts | USB_C_Receptacle_HRO_TYPE-C-31-M-12 | J2 |
| 2 | B6B-XH-A Motor+Encoder JST | JST_XH_B6B-XH-A_1x06_P2.50mm_Vertical | J3, J4 |
| 1 | B2B-XH-A Intake motor JST | JST_XH_B2B-XH-A_1x02_P2.50mm_Vertical | J5 |
| 2 | SM04B-SRSS-TB Qwiic JST | JST_SH_SM04B-SRSS-TB_1x04-1MP_P1.00mm_Horizontal | J6, J7 |
| 1 | SM04B-GHS-TB Vision UART JST | JST_GH_SM04B-GHS-TB_1x04-1MP_P1.25mm_Horizontal | J8 |
| 1 | B2B-XH-A Bumper L JST | JST_XH_B2B-XH-A_1x02_P2.50mm_Vertical | J9 |
| 1 | B2B-XH-A Bumper R JST | JST_XH_B2B-XH-A_1x02_P2.50mm_Vertical | J10 |
| 1 | 3568 + 0297007.WXNV 7.5A Keystone / Littelfuse | Fuseholder_Blade_Mini_Keystone_3568 | F1 |
| 1 | TL3342F160QG RESET C&K | SW_SPST_TL3342 | SW1 |
Show 28 more
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 1 | TL3342F160QG BOOT C&K | SW_SPST_TL3342 | SW2 |
| 1 | BZT52C12-7-F BZT52C12 Diodes Inc | D_SOD-123 | D1 |
| 1 | SMBJ15CA Littelfuse | D_SMB | D2 |
| 2 | SS34 MDD | D_SMA | D3, D7 |
| 1 | KT-0603G Green KENTO | LED_0603_1608Metric | D4 |
| 1 | SS14 MDD | D_SMA | D5 |
| 1 | WS2812B-B WS2812B Worldsemi | LED_WS2812B_PLCC4_5.0x5.0mm_P3.2mm | D6 |
| 1 | NRS5040T6R8MMGJ 6.8uH Taiyo Yuden | L_Taiyo-Yuden_NR-50xx | L1 |
| 1 | NRS5040T4R7MMGJ 4.7uH Taiyo Yuden | L_Taiyo-Yuden_NR-50xx | L2 |
| 1 | EEE-FK1E471P 470uF Panasonic | CP_Elec_10x10.5 | C1 |
| 6 | 10UF 10uF | C_1206_3216Metric | C2, C7, C12, C21, C27, C33 |
| 16 | 100NF 100nF | C_0603_1608Metric | C3, C4, C8, C9, C13, C16, C19, C20 +8 |
| 5 | 22UF 22uF | C_0805_2012Metric | C5, C6, C10, C11, C15 |
| 2 | 1UF 1uF | C_0603_1608Metric | C14, C18 |
| 2 | 10NF 10nF | C_0603_1608Metric | C25, C31 |
| 4 | 1NF 1nF | C_0603_1608Metric | C28, C29, C34, C35 |
| 1 | 47K 47k | R_0603_1608Metric | R1 |
| 3 | 100K 100k | R_0603_1608Metric | R2, R4, R34 |
| 1 | 22K 22k | R_0603_1608Metric | R3 |
| 1 | 15K 15k | R_0603_1608Metric | R5 |
| 5 | 1k | R_0603_1608Metric | R7, R14, R24, R37, R39 |
| 2 | 5.1K 5.1k | R_0603_1608Metric | R8, R9 |
| 8 | 10K 10k | R_0603_1608Metric | R10, R11, R16, R18, R26, R28, R38, R40 |
| 1 | 330 | R_0603_1608Metric | R12 |
| 2 | WSL2512R0100FEA 10m Vishay | R_2512_6332Metric | R13, R23 |
| 6 | 20K 20k | R_0603_1608Metric | R15, R17, R19, R25, R27, R29 |
| 1 | 100 | R_0603_1608Metric | R33 |
| 2 | 4.7K 4.7k | R_0603_1608Metric | R35, R36 |
Rallybot design files
The KiCad project lives in the lois-goon/Rallybot_pcb repository on GitHub; these links point at the commit this page was built from.
Rallybot: common questions
What microcontroller does the Rallybot use?
The Rallybot is built around the ESP32-S3-WROOM-1-N16R8, from the ESP32 family.
How big is the Rallybot PCB?
The Rallybot measures 100 × 80 mm, has 4 copper layers and is 1.6 mm thick.
How many components are on the Rallybot?
103 components, from 48 distinct parts, with part numbers taken from the project's own BOM. The full bill of materials is listed on this page.
Where can I download the Rallybot design files?
From the lois-goon/Rallybot_pcb repository on GitHub, which has the KiCad layout, the schematic and the BOM; the links under Design files point to each one.
Can I use the Rallybot design in my own project?
Yes, under the terms of its MIT license, which lois-goon chose for the repository.
Can I test firmware for the Rallybot without the hardware?
Yes. HardLabs builds a simulation of the board from its netlist and BOM, so you can run and debug ESP32 firmware against it before you order a PCB.
Similar boards
 ESP32
OSO-BOOK-B1
joeycastillo
85 × 115 mm65 parts2LCC-BY-SA-4.08.1k ESP32
Powertrain
byrantech
64 × 45.4 mm171 parts4LMIT4.3k ESP32
Badge
atopile
56.3 × 39 mm239 parts4LMIT4.0k ESP32
Esp32 minimal
36.2 × 26.8 mm20 parts2LMIT4.0k ESP32
Controller
StuckAtPrototype
29 × 74 mm58 parts4LApache-2.03.8k ESP32
Racer
36 × 50.2 mm70 parts4LApache-2.03.8k