
Robot Main Controller V3

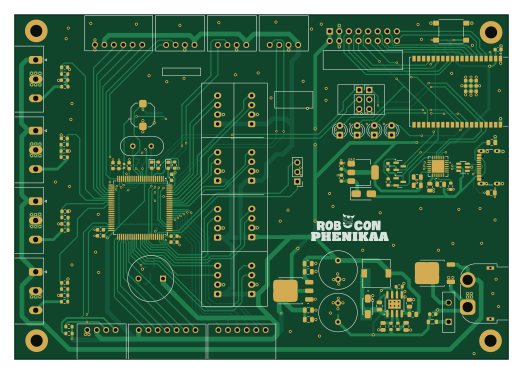
About the Robot Main Controller V3 PCB
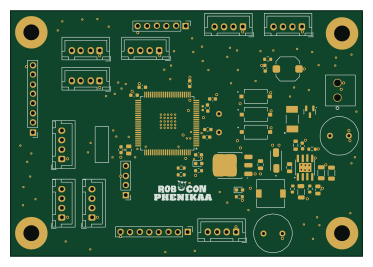
Robot Main Controller V3 is an open source ESP32 PCB design by manhtienvu-vn, published on GitHub. It is a 2-layer board measuring 130.5 × 91.1 mm, with 123 components from 58 distinct parts.
Its main chip is the ESP32-WROVER-E, from the ESP32 family. Other key parts include the MP1584EN, AMS1117CD-3.3, STM32F407VETx, USBLC6-2SC6 and CP2102-GM. By type, the board carries 39 resistors, 32 capacitors, 24 connectors, 8 diodes, 7 ICs and 4 transistors.
It belongs with the robotics & motion designs in this gallery.
From the project
Full neccessary document my team PKA-03 (Phenikaa University) used to build a defensive robot in the Vietnam Robocon competition 2025, including firmware, hardware and mechanical design.
Main components on the Robot Main Controller V3
Robot Main Controller V3 bill of materials (BOM)
123 components, 58 distinct parts.
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 1 | MP1584EN | MP1584EN | U1 |
| 1 | AMS1117CD-3.3 | TO-252-3_TabPin2 | U2 |
| 1 | STM32F407VETx | LQFP-100_14x14mm_P0.5mm | U3 |
| 1 | ~ | ESP32-WROVER-E | U4 |
| 1 | USBLC6-2SC6 | SOT-23-6 | U5 |
| 1 | CP2102-GM | CP2112-GM | U6 |
| 1 | AMS1117 | SOT-223-3_TabPin2 | U7 |
| 1 | MDD3752 P-Mos | TO-252-2 | Q1 |
| 2 | MMBT3904 | SOT-23 | Q2, Q3 |
| 1 | Q_PNP_CBE | SOT-23 | Q4 |
| 1 | 8MHz | Crystal_HC49-4H_Vertical | Y1 |
| 1 | ~ | AMASS_XT60PW-F_1x02_P7.20mm_Horizontal | J1 |
| 1 | USB_C_Receptacle_USB2.0_16P | USB_C_Receptacle_GCT_USB4105-xx-A_16P_TopMnt_Horizontal | J2 |
| 8 | Screw_Terminal_01x04 | JST_XH_B4B-XH-A_1x04_P2.50mm_Vertical | J3, J4, J5, J6, J7, J8, J9, J10 |
| 3 | Screw_Terminal_01x04 | XH_4P_2.54_Horizontal | J11, J12, J13 |
| 3 | Conn_01x03 | PinHeader_1x03_P2.54mm_Vertical | J14, J23, J25 |
| 1 | Screw_Terminal_01x07 | XH_2.54_7P_Horizontal | J15 |
| 2 | Screw_Terminal_01x06 | XH_2.54_6P_Horizontal | J16, J17 |
| 4 | Conn_01x03 | PhoenixContact_MSTBA_2,5_3-G-5,08_1x03_P5.08mm_Horizontal | J18, J19, J20, J21 |
| 1 | Conn_02x08_Counter_Clockwise | PinHeader_2x08_P2.54mm_Vertical | J22 |
Show 38 more
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 1 | Buzzer_5V | MagneticBuzzer_ProSignal_ABT-410-RC | BZ1 |
| 1 | 500mA | FUS_RGEF500_TYCO_TYC | F1 |
| 1 | Conn_01x04 | XH_4P_2.54_Horizontal | I2C1 |
| 1 | SW_Push | SW_Push_1TS009xxxx-xxxx-xxxx_6x6x5mm | SW1 |
| 1 | SW_Push | SW_Push_1P1T_NO_6x6mm_H9.5mm | SW2 |
| 1 | SS34 | SS34_SMA | D1 |
| 1 | RED | LED_0603_1608Metric | D2 |
| 1 | BLUE | LED_0603_1608Metric | D3 |
| 1 | SS14 | D_SMA | D4 |
| 4 | LED_3mm | LED_D3.0mm | D5, D6, D7, D8 |
| 1 | 600ohm 600MHz | L_0805_2012Metric | FB1 |
| 1 | 15uH | L_7.3x7.3_H4.5 | L1 |
| 1 | 39n | L_0402_1005Metric | L2 |
| 2 | 470uF | C_Radial_D10.0mm_H16.0mm_P5.00mm | C1, C4 |
| 1 | 100nF | C_0805_2012Metric | C2 |
| 1 | 150pF | C_0805_2012Metric | C3 |
| 5 | 10uF | C_0603_1608Metric | C5, C12, C19, C22, C23 |
| 2 | 0.1uF | C_0805_2012Metric | C6, C9 |
| 5 | 10uF | C_0805_2012Metric | C7, C8, C24, C25, C30 |
| 2 | 2.2uF | C_0603_1608Metric | C10, C11 |
| 7 | 1uF | C_0603_1608Metric | C13, C14, C17, C18, C20, C31, C32 |
| 2 | 20pF | C_0603_1608Metric | C15, C16 |
| 1 | 10nF | C_0603_1608Metric | C21 |
| 4 | 100nF | C_0603_1608Metric | C26, C27, C28, C29 |
| 3 | 100k | R_0603_1608Metric | R1, R3, R4 |
| 1 | 24.9k | R_0805_2012Metric | R2 |
| 1 | 8.2k | R_0805_2012Metric | R5 |
| 1 | 43k | R_0805_2012Metric | R6 |
| 1 | 10k | R_0805_2012Metric | R7 |
| 14 | 1k | R_0603_1608Metric | R8, R9, R11, R12, R13, R23, R24, R27 +6 |
| 1 | 1M | R_0603_1608Metric | R10 |
| 2 | 5k1 | R_0805_2012Metric | R14, R15 |
| 1 | 22.1k | R_0805_2012Metric | R16 |
| 1 | 47.5k | R_0805_2012Metric | R17 |
| 3 | 10k | R_0603_1608Metric | R18, R19, R20 |
| 2 | 4k7 | R_0603_1608Metric | R21, R22 |
| 4 | 3.3k | R_0603_1608Metric | R25, R28, R31, R34 |
| 4 | 6.8k | R_0603_1608Metric | R26, R29, R32, R35 |
Robot Main Controller V3 design files
The KiCad project lives in the manhtienvu-vn/Defensive_Robot repository on GitHub; these links point at the commit this page was built from.
Robot Main Controller V3: common questions
What microcontroller does the Robot Main Controller V3 use?
The Robot Main Controller V3 is built around the ESP32-WROVER-E, from the ESP32 family.
How big is the Robot Main Controller V3 PCB?
The Robot Main Controller V3 measures 130.5 × 91.1 mm, has 2 copper layers and is 1.6 mm thick.
How many components are on the Robot Main Controller V3?
123 components, from 58 distinct parts. The full bill of materials is listed on this page.
Where can I download the Robot Main Controller V3 design files?
From the manhtienvu-vn/Defensive_Robot repository on GitHub, which has the KiCad layout and the schematic; the links under Design files point to each one.
Can I use the Robot Main Controller V3 design in my own project?
The repository has no license, so all rights stay with manhtienvu-vn. Use it as a reference, and ask the author before reusing the design.
Can I test firmware for the Robot Main Controller V3 without the hardware?
Yes. HardLabs builds a simulation of the board from its netlist and BOM, so you can run and debug ESP32 firmware against it before you order a PCB.
More boards in Defensive_Robot
Similar boards
 ESP32
Open Book Abridged Edition
joeycastillo
85 × 115 mm65 parts2LCC-BY-SA-4.08.1k ESP32
Badge
atopile
56.3 × 39 mm239 parts4LMIT4.0k ESP32
Esp32 minimal
36.2 × 26.8 mm20 parts2LMIT4.0k ESP32
Racer
StuckAtPrototype
36 × 50.2 mm70 parts4LApache-2.03.8k ESP32
Controller
29 × 74 mm58 parts4LApache-2.03.8k ESP32
Bitaxe
skot
56.5 × 99.8 mm86 parts4LCERN-OHL-S-2.01.4k