
Robot link

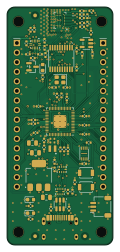
About the Robot link PCB
Robot link is an open source RP2040/RP2350 PCB design by sequoia-hope, published on GitHub. It is a 6-layer board measuring 28 × 63 mm, with 93 components from 41 distinct parts.
Its main chip is the RP2350A, from the RP2040/RP2350 family. Other key parts include the AMS1117-3.3, W25Q16JVUXIQ, ST60A3H1, PTN3222GM and TXS0108E. By type, the board carries 39 capacitors, 29 resistors, 12 ICs, 5 connectors, 3 diodes and 2 switches.
It belongs with the robotics & motion and dev boards & breakouts designs in this gallery.
From the project
RP2350A + ST60A3H1 60 GHz contactless link dev board (KiCad, generated)
A dev board for ST's 60 GHz contactless link: an RP2350A beside an ST60A3H1 (antenna in the package), 28 × 63 mm, six layers. Two boards face each other a few centimetres apart and tunnel UART, GPIO, I²C or USB 2.0 between them. The same board is either end. On the back there is a connector for an OV2640 camera module.
Status: rev B captured, placed and routed. 100 parts, 83 nets; KiCad's DRC and ERC report nothing, KiCad's own netlist of the drawn schematic matches tools/circuit.py net for net, every placed part has an LCSC number and the assembly check passes. Not fabricated, and no…
Main components on the Robot link
Robot link bill of materials (BOM)
93 components, 41 distinct parts.
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 1 | RP2350A | RP2350-QFN-60-1EP_7x7_P0.4mm_EP3.4x3.4mm_ThermalVias | U1 |
| 1 | AMS1117-3.3 | SOT-223-3_TabPin2 | U2 |
| 1 | W25Q16JVUXIQ | Winbond_USON-8-1EP_3x2mm_P0.5mm_EP0.2x1.6mm | U3 |
| 1 | ST60A3H1 | ST_VFBGA-23_AiP_2.95x4.07mm_P0.4mm | U4 |
| 1 | PTN3222GM | NXP_XQFN-12_1.75x2.2mm_P0.4mm | U5 |
| 1 | TXS0108E | TSSOP-20_4.4x6.5mm_P0.65mm | U6 |
| 1 | TLV75518P | SOT-23-5 | U7 |
| 1 | USBLC6-2SC6 | SOT-23-6 | U8 |
| 2 | TS3USB221A | Texas_UQFN-10_1.5x2mm_P0.5mm | U9, U10 |
| 1 | XC6206P282MR | SOT-23 | U11 |
| 1 | ME6216A13M3G | SOT-23 | U12 |
| 1 | MMBT3904 | SOT-23 | Q1 |
| 1 | 12MHz | Crystal_SMD_2520-4Pin_2.5x2.0mm | Y1 |
| 1 | USB-C | USB_C_Receptacle_HRO_TYPE-C-31-M-12 | J1 |
| 1 | LEFT | PinHeader_1x16_P2.54mm_Vertical | J2 |
| 1 | RIGHT | PinHeader_1x16_P2.54mm_Vertical | J3 |
| 1 | SWD | JST_SH_SM03B-SRSS-TB_1x03-1MP_P1.00mm_Horizontal | J4 |
| 1 | OV2640 | Hirose_FH12-24S-0.5SH_1x24-1MP_P0.50mm_Horizontal | J5 |
| 1 | BOOTSEL | SW_SPST_B3U-1000P | SW1 |
| 1 | RUN | SW_SPST_B3U-1000P | SW2 |
Show 21 more
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 2 | green | LED_0603_1608Metric | D1, D2 |
| 1 | blue | LED_0603_1608Metric | D3 |
| 1 | 3u3 | L_pol_2016 | L1 |
| 3 | 10u | C_0805_2012Metric | C1, C5, C19 |
| 19 | 100n | C_0402_1005Metric | C2, C8, C11, C12, C13, C14, C15, C16 +11 |
| 2 | 27p | C_0402_1005Metric | C3, C4 |
| 2 | 4u7 | C_0402_1005Metric_small_pads | C6, C7 |
| 2 | 4u7 | C_0402_1005Metric | C9, C10 |
| 1 | 470n | C_0402_1005Metric | C26 |
| 2 | 100p | C_0402_1005Metric | C27, C29 |
| 8 | 1u | C_0402_1005Metric | C28, C32, C33, C40, C41, C42, C43, C44 |
| 4 | 1k | R_0402_1005Metric | R2, R4, R6, R23 |
| 1 | 33R | R_0402_1005Metric | R5 |
| 2 | 27R | R_0402_1005Metric | R7, R8 |
| 3 | 220R | R_0402_1005Metric | R9, R14, R30 |
| 2 | 5k1 | R_0402_1005Metric | R10, R11 |
| 11 | 4k7 | R_0402_1005Metric | R12, R13, R15, R24, R25, R26, R27, R28 +3 |
| 1 | 0R | R_0402_1005Metric | R20 |
| 1 | 1k5 | R_0402_1005Metric | R21 |
| 1 | 1k8 | R_0402_1005Metric | R22 |
| 3 | 10k | R_0402_1005Metric | R29, R42, R43 |
Robot link design files
The KiCad project lives in the sequoia-hope/robot-link repository on GitHub; these links point at the commit this page was built from.
- Layouthardware/comms/comms.kicad_pcb
- Schematichardware/comms/comms.kicad_sch
Robot link: common questions
What microcontroller does the Robot link use?
The Robot link is built around the RP2350A, from the RP2040/RP2350 family.
How big is the Robot link PCB?
The Robot link measures 28 × 63 mm, has 6 copper layers and is 1.6 mm thick.
How many components are on the Robot link?
93 components, from 41 distinct parts. The full bill of materials is listed on this page.
Where can I download the Robot link design files?
From the sequoia-hope/robot-link repository on GitHub, which has the KiCad layout and the schematic; the links under Design files point to each one.
Can I use the Robot link design in my own project?
The repository has no license, so all rights stay with sequoia-hope. Use it as a reference, and ask the author before reusing the design.
Can I test firmware for the Robot link without the hardware?
Yes. HardLabs builds a simulation of the board from its netlist and BOM, so you can run and debug RP2040/RP2350 firmware against it before you order a PCB.
Similar boards
 RP2040/RP2350
Open Book Abridged Edition
joeycastillo
85 × 115 mm29 parts2LCC-BY-SA-4.08.1k RP2040/RP2350
Corne
foostan
277.2 × 107.5 mm164 parts2LCC-BY-4.07.7k RP2040/RP2350
Corne
277.2 × 107.5 mm164 parts2LCC-BY-4.07.7k RP2040/RP2350
LogicAnalyzer
gusmanb
57 × 55.2 mm6 parts2LGPL-3.05.0k RP2040/RP2350
Jitx design
55.5 × 65 mm26 parts4LGPL-3.05.0k RP2040/RP2350
Main
google
98 × 71 mm102 parts2LApache-2.02.9k