
Haptic-Glove

About the Haptic-Glove PCB
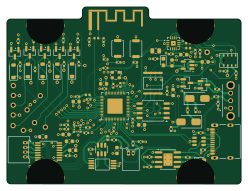
Haptic-Glove is an open source ESP32 PCB design by ZharbolatDinmukhamed, published on GitHub. It is a 4-layer board measuring 62 × 46.9 mm, with 108 components from 49 distinct parts.
Its main chip is the ESP32-S3, from the ESP32 family. Other key parts include the ESP-PSRAM64H, MAX98357A, DRV8833PW, W25Q128JVS and TP4056-42-ESOP8. By type, the board carries 37 capacitors, 29 resistors, 11 diodes, 9 ICs, 8 transistors and 4 inductors.
It belongs with the robotics & motion designs in this gallery.
From the project
A wrist-mounted PCB for a haptic feedback glove, developed as part of my Research Assistantship at the Tactile Laboratory, Nazarbayev University.
Main components on the Haptic-Glove
Haptic-Glove bill of materials (BOM)
108 components, 49 distinct parts.
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 1 | ESP-PSRAM64H | SOIC127P600X175-8N | IC1 |
| 1 | MAX98357A | TQFN-16-1EP_3x3mm_P0.5mm_EP1.23x1.23mm | U1 |
| 1 | DRV8833PW | TSSOP-16_4.4x5mm_P0.65mm | U2 |
| 1 | ESP32-S3 | QFN56_7X7_EXP | U3 |
| 1 | W25Q128JVS | SOIC-8_5.3x5.3mm_P1.27mm | U4 |
| 1 | TP4056-42-ESOP8 | SOIC-8-1EP_3.9x4.9mm_P1.27mm_EP2.41x3.3mm_ThermalVias | U5 |
| 1 | XC6220B331MR | SOT-23-5 | U6 |
| 1 | LIS2HH12 | LGA-12_2x2mm_P0.5mm | U7 |
| 1 | DW01A | SOT-23-6 | U8 |
| 5 | SS8050 | SOT-23 | Q1, Q2, Q3, Q4, Q5 |
| 1 | AO3401A | SOT-23 | Q6 |
| 1 | MMBT3904 | SOT-23 | Q7 |
| 1 | FS8205A | SOP65P640X120-8N | Q8 |
| 1 | ECS-2520MV-xxx-xx | Oscillator_SMD_ECS_2520MV-xxx-xx-4Pin_2.5x2.0mm | Y1 |
| 1 | TYPE-C-31-M-12 | HRO_TYPE-C-31-M-12 | J2 |
| 1 | Conn_01x04 | Molex_PicoBlade_53048-0410_1x04_P1.25mm_Horizontal | J3 |
| 1 | Conn_01x02 | Molex_PicoBlade_53048-0210_1x02_P1.25mm_Horizontal | J4 |
| 1 | PCB Antenna 2.4GHz 50Ohm | ANT_IFA_USB_2_4GHZ_50R | ANT1 |
| 1 | Speaker | Untitled_1 | LS1 |
| 1 | INMP441ACEZ-R7 | MIC_INMP441ACEZ-R7 | MK1 |
Show 29 more
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 2 | SW_Push | SW_Push_SPST_NO_Alps_SKRK | SW1, SW2 |
| 1 | SW_DPDT_x2 | OS102011MA1QN1 | SW3 |
| 5 | 1N4148W | D_SOD-123 | D1, D2, D3, D4, D5 |
| 1 | USBLC6-2SC6 STMicroelectronics | SOT-23-6 | D6 |
| 1 | LED_GRN | LED_0603_1608Metric_Pad1.05x0.95mm_HandSolder | D7 |
| 1 | LED_RED | LED_0603_1608Metric_Pad1.05x0.95mm_HandSolder | D8 |
| 2 | SS14 | D_SMA | D9, D10 |
| 1 | LED | LED_0603_1608Metric_Pad1.05x0.95mm_HandSolder | D11 |
| 2 | * FB0402 * | FB_0402 | FB1, FB2 |
| 2 | 2n2 | L_0402_1005Metric | L1, L2 |
| 21 | 100n | C_0402_1005Metric | C1, C2, C3, C4, C5, C7, C9, C10 +13 |
| 10 | 10u | C_0603_1608Metric | C6, C14, C17, C25, C27, C30, C31, C32 +2 |
| 2 | 220p | C_0402_1005Metric | C8, C11 |
| 1 | 10p | C_0402_1005Metric | C16 |
| 1 | 2u2 | C_0603_1608Metric | C20 |
| 2 | 3p3 | C_0402_1005Metric | C22, C24 |
| 3 | 100k | R_0402_1005Metric | R1, R18, R21 |
| 1 | 634K | R_0805_2012Metric | R2 |
| 7 | 1k | R_0402_1005Metric | R3, R4, R5, R8, R9, R28, R29 |
| 6 | 5k1 | R_0402_1005Metric | R6, R7, R10, R12, R14, R15 |
| 2 | 200m | R_0603_1608Metric | R11, R13 |
| 1 | 22R | R_0402_1005Metric | R16 |
| 1 | 220k | R_0402_1005Metric | R17 |
| 2 | 10k | R_0402_1005Metric | R19, R26 |
| 2 | 1k3 | R_0402_1005Metric | R20, R22 |
| 1 | 220 | R_0402_1005Metric | R23 |
| 1 | 1k4 | R_0402_1005Metric | R24 |
| 1 | 27k | R_0402_1005Metric | R25 |
| 1 | 100 | R_0402_1005Metric | R27 |
Haptic-Glove design files
The KiCad project lives in the ZharbolatDinmukhamed/Haptic-Glove-PCB repository on GitHub; these links point at the commit this page was built from.
- Layout4LayerLabProject.kicad_pcb
- Schematic4LayerLabProject.kicad_sch
Haptic-Glove: common questions
What microcontroller does the Haptic-Glove use?
The Haptic-Glove is built around the ESP32-S3, from the ESP32 family.
How big is the Haptic-Glove PCB?
The Haptic-Glove measures 62 × 46.9 mm, has 4 copper layers and is 1.58 mm thick.
How many components are on the Haptic-Glove?
108 components, from 49 distinct parts. The full bill of materials is listed on this page.
Where can I download the Haptic-Glove design files?
From the ZharbolatDinmukhamed/Haptic-Glove-PCB repository on GitHub, which has the KiCad layout and the schematic; the links under Design files point to each one.
Can I use the Haptic-Glove design in my own project?
The repository has no license, so all rights stay with ZharbolatDinmukhamed. Use it as a reference, and ask the author before reusing the design.
Can I test firmware for the Haptic-Glove without the hardware?
Yes. HardLabs builds a simulation of the board from its netlist and BOM, so you can run and debug ESP32 firmware against it before you order a PCB.
Similar boards
 ESP32
OSO-BOOK-B1
joeycastillo
85 × 115 mm65 parts2LCC-BY-SA-4.08.1k ESP32
Powertrain
byrantech
64 × 45.4 mm171 parts4LMIT4.3k ESP32
Esp32 minimal
atopile
36.2 × 26.8 mm20 parts2LMIT4.0k ESP32
Badge
56.3 × 39 mm239 parts4LMIT4.0k ESP32
Racer
StuckAtPrototype
36 × 50.2 mm70 parts4LApache-2.03.8k ESP32
Controller
29 × 74 mm58 parts4LApache-2.03.8k