
PCC

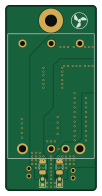
About the PCC PCB
PCC is an open source PCB design by berkeleyauv, published on GitHub under the GPL-3.0 license. It is a 2-layer board measuring 24 × 49 mm, with 22 components from 13 distinct parts.
Other key parts include the I6A4W020A033V-001-R. By type, the board carries 10 capacitors, 7 resistors, 2 diodes, 1 IC, 1 connector and 1 switch.
It belongs with the robotics & motion designs in this gallery.
From the project
PCB designs for Underwater Robotics at Berkeley (UR@B)
Power converter carrier that converts up to 53V down to 15V, 12V, 5V, or 3.3V output at 20A peak.
- Flat horizontal mount instead of vertical.
Main components on the PCC
PCC bill of materials (BOM)
22 components, 13 distinct parts.
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 1 | I6A4W020A033V-001-R | I6A4W020A033V-001-R | U1 |
| 1 | PWR | Samtec_mPOWER_UMPT_3pin | J1 |
| 1 | SW_DIP_x04 | SW_DIP_SPSTx04_Slide_Omron_A6H-4101_W6.15mm_P1.27mm | SW1 |
| 2 | LED | LED_0603_1608Metric | D1, D2 |
| 5 | 10u | C_1210_3225Metric | C1, C2, C3, C4, C5 |
| 5 | 47u | C_1206_3216Metric | C6, C7, C8, C9, C10 |
| 1 | 0 | R_0603_1608Metric | R1 |
| 1 | 30.3k | R_0603_1608Metric | R2 |
| 1 | 8.57k | R_0603_1608Metric | R3 |
| 1 | 1.82k | R_0603_1608Metric | R4 |
| 1 | 1.25k | R_0603_1608Metric | R5 |
| 1 | 10k | R_1206_3216Metric | R6 |
| 1 | 1k | R_1206_3216Metric | R7 |
PCC design files
The KiCad project lives in the berkeleyauv/RoboSub_HW repository on GitHub; these links point at the commit this page was built from.
- LayoutGeneral/PCC/PCC.kicad_pcb
- SchematicGeneral/PCC/PCC.kicad_sch
PCC: common questions
How big is the PCC PCB?
The PCC measures 24 × 49 mm, has 2 copper layers and is 1.6 mm thick.
How many components are on the PCC?
22 components, from 13 distinct parts. The full bill of materials is listed on this page.
Where can I download the PCC design files?
From the berkeleyauv/RoboSub_HW repository on GitHub, which has the KiCad layout and the schematic; the links under Design files point to each one.
Can I use the PCC design in my own project?
Yes, under the terms of its GPL-3.0 license, which berkeleyauv chose for the repository.
More boards in RoboSub_HW
 STM32
NOGGIN
31.3 × 34 mm57 parts4LGPL-3.03
Power distribution board
115.6 × 104.1 mm41 parts2LGPL-3.03 STM32
NOGUSB
30.5 × 25 mm34 parts2LGPL-3.03 STM32
NOGPROG
33 × 13 mm33 parts2LGPL-3.03 STM32
ESCC
36 × 40 mm28 parts2LGPL-3.03 STM32
Noggin f072cb
59 × 25.9 mm26 parts2LGPL-3.03
NOGLINK
19.5 × 30.8 mm22 parts2LGPL-3.03 STM32
Noggin g0b1ke
64.3 × 24 mm21 parts2LGPL-3.03
BackplaneTest
83.5 × 22 mm8 parts2LGPL-3.03
ESCB
36 × 18 mm8 parts2LGPL-3.03
Similar boards
Stack chan
stack-chan
50 × 50 mm33 parts2LApache-2.01.7k
Cube batteryboard
willem-pennings
95 × 95 mm4 parts2LGPL-3.01.1k
Mesabob
rene-dev
87.5 × 50 mm44 parts2LGPL-3.0979
Bob
100 × 100 mm140 parts2LGPL-3.0979
Triple adapter
57 × 75 mm26 parts2LGPL-3.0979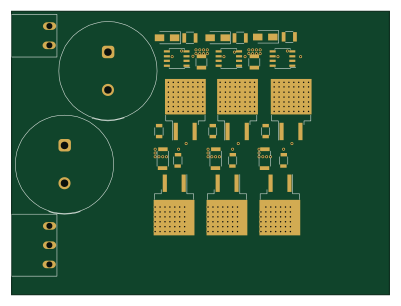
Trollerv2
100 × 75 mm33 parts4LGPL-3.0979