
Swarm Robot Hardware

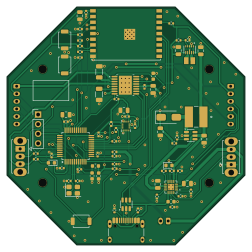
About the Swarm Robot Hardware PCB
Swarm Robot Hardware is an open source ESP32 PCB design by Khoi281248, published on GitHub under the MIT license. It is a 2-layer board measuring 62.8 × 62.8 mm, with 83 components from 42 distinct parts.
Its main chip is the ESP32-C3-WROOM-02, from the ESP32 family. Other key parts include the TPS63802DLAR, MT3608, BQ24075RGT, DRV8833PWP and STM32F103C8T6. By type, the board carries 29 capacitors, 29 resistors, 7 ICs, 5 connectors, 5 switches and 3 diodes.
It belongs with the robotics & motion, power & battery and iot & wireless designs in this gallery.
From the project
Mach swarm robot (KiCad 10): STM32F103 + ESP32-C3, DRV8833, ICM-42670-P
Mạch điều khiển cho robot bầy đàn (swarm robot), thiết kế bằng KiCad 10.
Một mạch duy nhất gồm hai vi điều khiển: - STM32F103C8T6: điều khiển thời gian thực. Lo 2 động cơ có encoder, IMU 6 trục và đo điện áp pin. - ESP32-C3-WROOM-02: truyền thông không dây giữa các robot. Chip này cũng nạp firmware cho STM32 qua UART.
Ảnh render 3D từ KiCad 10. Linh kiện xuyên lỗ J1–J4, SW3, SW5 là DNP (tự hàn) nên không hiện model 3D.
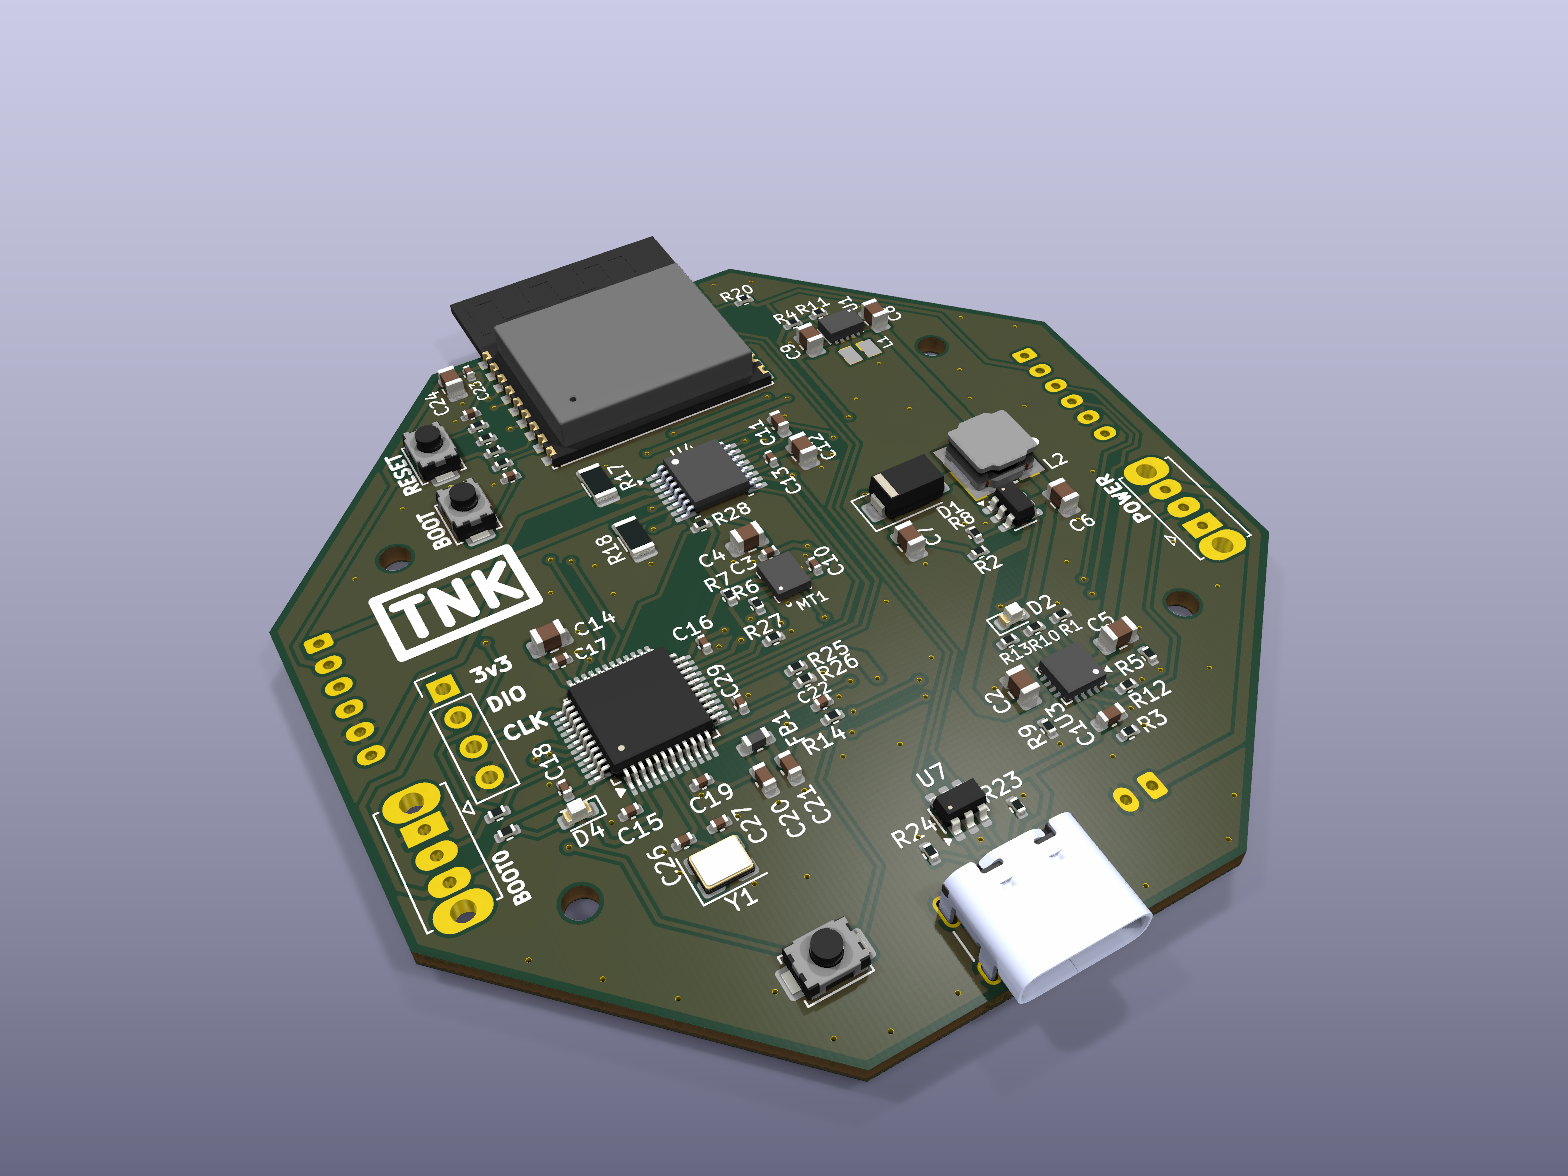
Main components on the Swarm Robot Hardware
Swarm Robot Hardware bill of materials (BOM)
83 components, 42 distinct parts — part numbers from the project's BOM.
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 1 | TPS63802DLAR | VREG_TPS63802DLAR | U1 |
| 1 | MT3608 | SOT-23-6 | U2 |
| 1 | BQ24075RGT | VQFN-16-1EP_3x3mm_P0.5mm_EP1.6x1.6mm_ThermalVias | U3 |
| 1 | DRV8833PWP | HTSSOP-16-1EP_4.4x5mm_P0.65mm_EP3.4x5mm_Mask2.46x2.31mm_ThermalVias | U4 |
| 1 | STM32F103C8T6 | LQFP-48_7x7mm_P0.5mm | U5 |
| 1 | ESP32-C3-WROOM-02 | ESP32-C3-WROOM-02 | U6 |
| 1 | USBLC6-2SC6 | SOT-23-6 | U7 |
| 1 | 16MHZ 16MHz | Crystal_SMD_3225-4Pin_3.2x2.5mm | Y1 |
| 1 | Motor_A | JST_PH_B6B-PH-K_1x06_P2.00mm_Vertical | J1 |
| 1 | Motor_B | JST_PH_B6B-PH-K_1x06_P2.00mm_Vertical | J2 |
| 1 | SW | PinHeader_1x04_P2.54mm_Vertical | J3 |
| 1 | Lipo_2000mAh | JST_PH_B2B-PH-K_1x02_P2.00mm_Vertical | J4 |
| 1 | USB_C_RECEPTACLE_USB2.0_16P USB_C_Receptacle_USB2.0_16P | USB_C_Receptacle_HRO_TYPE-C-31-M-12 | J5 |
| 1 | ICM-42670-P | XDCR_ICM-42670-P | MT1 |
| 3 | SW_Push | SW_SPST_TS-1088-xR025 | SW1, SW2, SW4 |
| 1 | SW_SPDT | SW_Slide_SPDT_Straight_CK_OS102011MS2Q | SW3 |
| 1 | SW_POWER | SW_Slide_SPDT_Straight_CK_OS102011MS2Q | SW5 |
| 1 | SS34 | D_SMA | D1 |
| 2 | C2286 LED_RED | LED_0603_1608Metric | D2, D4 |
| 1 | 120R | L_0603_1608Metric | FB1 |
Show 22 more
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 1 | 0.47UH 0.47uH | INDC2016X120N | L1 |
| 1 | 4.7UH 4.7uH | WE-PD2_5848 | L2 |
| 3 | 1UF 1uF | C_0603_1608Metric | C1, C20, C21 |
| 4 | 22UF 22uF | C_0805_2012Metric | C2, C6, C7, C9 |
| 9 | 100NF 100nF | C_0402_1005Metric | C3, C15, C16, C17, C18, C22, C23, C28 +1 |
| 6 | 10UF 10uF | C_0805_2012Metric | C4, C5, C8, C12, C14, C24 |
| 3 | 10NF 10nF | C_0402_1005Metric | C10, C13, C19 |
| 1 | 2.2UF 2.2uF | C_0603_1608Metric | C11 |
| 1 | 1UF 1uF | C_0402_1005Metric | C25 |
| 2 | 10PF 10pF | C_0402_1005Metric | C26, C27 |
| 3 | 100K 100k | R_0402_1005Metric | R1, R25, R26 |
| 1 | 200K 200k | R_0402_1005Metric | R2 |
| 1 | 47K 47k | R_0402_1005Metric | R3 |
| 1 | 56K 56k | R_0402_1005Metric | R4 |
| 11 | 10K 10k | R_0402_1005Metric | R5, R10, R11, R14, R15, R19, R20, R21 +3 |
| 2 | 4.7K | R_0402_1005Metric | R6, R7 |
| 1 | 22K 22k | R_0402_1005Metric | R8 |
| 2 | 1.2K 1.2k | R_0402_1005Metric | R9, R12 |
| 2 | 1k | R_0402_1005Metric | R13, R29 |
| 1 | 100 | R_0402_1005Metric | R16 |
| 2 | 0.2 | R_1206_3216Metric | R17, R18 |
| 2 | 5K1 5k1 | R_0402_1005Metric | R23, R24 |
Swarm Robot Hardware design files
The KiCad project lives in the Khoi281248/Swarm_Robot_Hardware repository on GitHub; these links point at the commit this page was built from.
Swarm Robot Hardware: common questions
What microcontroller does the Swarm Robot Hardware use?
The Swarm Robot Hardware is built around the ESP32-C3-WROOM-02, from the ESP32 family.
How big is the Swarm Robot Hardware PCB?
The Swarm Robot Hardware measures 62.8 × 62.8 mm, has 2 copper layers and is 1.6 mm thick.
How many components are on the Swarm Robot Hardware?
83 components, from 42 distinct parts, with part numbers taken from the project's own BOM. The full bill of materials is listed on this page.
Where can I download the Swarm Robot Hardware design files?
From the Khoi281248/Swarm_Robot_Hardware repository on GitHub, which has the KiCad layout, the schematic and the BOM; the links under Design files point to each one.
Can I use the Swarm Robot Hardware design in my own project?
Yes, under the terms of its MIT license, which Khoi281248 chose for the repository.
Can I test firmware for the Swarm Robot Hardware without the hardware?
Yes. HardLabs builds a simulation of the board from its netlist and BOM, so you can run and debug ESP32 firmware against it before you order a PCB.
Similar boards
 ESP32
OSO-BOOK-B1
joeycastillo
85 × 115 mm65 parts2LCC-BY-SA-4.08.1k ESP32
Powertrain
byrantech
64 × 45.4 mm171 parts4LMIT4.3k ESP32
Badge
atopile
56.3 × 39 mm239 parts4LMIT4.0k ESP32
Esp32 minimal
36.2 × 26.8 mm20 parts2LMIT4.0k ESP32
Controller
StuckAtPrototype
29 × 74 mm58 parts4LApache-2.03.8k ESP32
Racer
36 × 50.2 mm70 parts4LApache-2.03.8k