
Glove v3-floorplan

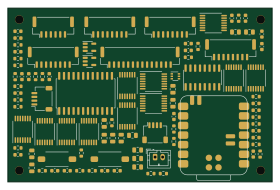
About the Glove v3-floorplan PCB
Glove v3-floorplan is an open source Nordic nRF PCB design by latintzar, published on GitHub under the MIT license. It is a 4-layer board measuring 70 × 46 mm, with 333 components from 42 distinct parts.
Its main chip is the 102010469, from the Nordic nRF family. Other key parts include the ISM330DHCXTR, MCP1501T-25E/SN, MCP6002T-I/SN, MCP33131D-10-I/MS and OPA320AIDBVR. By type, the board carries 150 resistors, 138 capacitors, 29 ICs, 10 connectors and 2 switches.
It belongs with the iot & wireless, wearables and robotics & motion designs in this gallery.
From the project
A sensing-glove design for recording hand contact, vibration and video.
Current completed electrical baseline:20 separately read pressure locations and20 PVDF vibration locations, one button and a diffused RGB indicator. The next complete-product requirement adds continuous finger-facing video for at least six hours, with twelve hours as the stretch target. Its camera, controller and larger-battery power design remain under integration review.
Main components on the Glove v3-floorplan
Glove v3-floorplan bill of materials (BOM)
333 components, 42 distinct parts — part numbers from the project's BOM.
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 1 | ISM330DHCXTR TLV75518PDBVR | SOT-23-5 | U1 |
| 1 | MCP1501T-25E/SN | SOIC-8_3.9x4.9mm_P1.27mm | U2 |
| 1 | MCP6002T-I/SN | SOIC-8_3.9x4.9mm_P1.27mm | U3 |
| 1 | MCP33131D-10-I/MS | MSOP-10_3x3mm_P0.5mm | U4 |
| 2 | OPA320AIDBVR | SOT-23-5 | U5, U29 |
| 4 | CD74HC4067M | SOIC-24W_7.5x15.4mm_P1.27mm | U6, U7, U8, U9 |
| 1 | CD74HC4052M | SOIC-16_3.9x9.9mm_P1.27mm | U10 |
| 15 | MCP6004T-I/ST | TSSOP-14_4.4x5mm_P0.65mm | U11, U12, U13, U14, U15, U16, U17, U18 +7 |
| 1 | OPA4320AIPWR | TSSOP-14_4.4x5mm_P0.65mm | U26 |
| 1 | TCA9534DWR | SOIC-16W_7.5x10.3mm_P1.27mm | U27 |
| 1 | TPS22919DCKT | SOT-363_SC-70-6 | U28 |
| 1 | 102010469 | XIAO-nRF52840-SMD-kicad7 | J1 |
| 1 | B2B-PH-K-S(LF)(SN) | JST_PH_B2B-PH-K_1x02_P2.00mm_Vertical | J2 |
| 2 | SM04B-SRSS-TB(LF)(SN) | JST_SH_SM04B-SRSS-TB_1x04-1MP_P1.00mm_Horizontal | J3, J4 |
| 1 | BM06B-GHS-TBT(LF)(SN) | JST_GH_BM06B-GHS-TBT_1x06-1MP_P1.25mm_Vertical | J5 |
| 4 | BM08B-GHS-TBT(LF)(SN) | JST_GH_BM08B-GHS-TBT_1x08-1MP_P1.25mm_Vertical | J6, J7, J8, J9 |
| 1 | BM14B-GHS-TBT(LF)(SN) | JST_GH_BM14B-GHS-TBT_1x14-1MP_P1.25mm_Vertical | J10 |
| 4 | — | H1, H2, H3, H4 | |
| 2 | PTS636SK43SMTR-LFS | SW_PTS636_SK43_G | SW1, SW2 |
| 1 | GRM188R71C104KA01D GRM1885C1H101JA01D | C_0603_1608Metric | C1 |
Show 22 more
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 1 | GRM188R71C104KA01D C0603C123J3GACAUTO | C_0603_1608Metric | C2 |
| 1 | GRM188R61A475KE15D GRM1885C1H103JA01D | C_0603_1608Metric | C3 |
| 20 | C0603C153J3GACAUTO | C_0603_1608Metric | C4, C9, C14, C19, C24, C29, C34, C39 +12 |
| 20 | GRM1885C1H222JA01D | C_0603_1608Metric | C5, C10, C15, C20, C25, C30, C35, C40 +12 |
| 19 | GRM1885C1H101JA01D | C_0603_1608Metric | C6, C11, C16, C21, C26, C31, C36, C41 +11 |
| 19 | C0603C123J3GACAUTO | C_0603_1608Metric | C7, C12, C17, C22, C27, C32, C37, C42 +11 |
| 19 | GRM1885C1H103JA01D | C_0603_1608Metric | C8, C13, C18, C23, C28, C33, C38, C43 +11 |
| 6 | GRM188R61A105KA61D | C_0603_1608Metric | C101, C102, C104, C133, C135, C136 |
| 1 | GRM188R61A106MA73D | C_0603_1608Metric | C103 |
| 28 | GRM188R71H104KA93D | C_0603_1608Metric | C105, C107, C108, C109, C110, C111, C112, C113 +20 |
| 1 | GRM21BR61A106KE19L | C_0805_2012Metric | C106 |
| 2 | GRM1885C1H102JA01D | C_0603_1608Metric | C134, C138 |
| 1 | RC0603FR-0722RL RH73H2A100MKTN | R_0805_2012Metric | R1 |
| 1 | RC0603FR-0722RL RC0603FR-071KL | R_0603_1608Metric | R2 |
| 40 | RC0603FR-0714K7L | R_0603_1608Metric | R3, R4, R10, R11, R17, R18, R24, R25 +32 |
| 40 | RC0603FR-0727K4L | R_0603_1608Metric | R5, R6, R12, R13, R19, R20, R26, R27 +32 |
| 25 | RC0603FR-0710KL | R_0603_1608Metric | R7, R14, R21, R28, R35, R42, R49, R56 +17 |
| 19 | RH73H2A100MKTN | R_0805_2012Metric | R8, R15, R22, R29, R36, R43, R50, R57 +11 |
| 19 | RC0603FR-071KL | R_0603_1608Metric | R9, R16, R23, R30, R37, R44, R51, R58 +11 |
| 2 | RC0603FR-0722RL | R_0603_1608Metric | R143, R148 |
| 2 | RC0603FR-074K7L | R_0603_1608Metric | R144, R145 |
| 1 | RC0603FR-07100KL | R_0603_1608Metric | R146 |
Glove v3-floorplan design files
The KiCad project lives in the latintzar/tactile-glove repository on GitHub; these links point at the commit this page was built from.
Glove v3-floorplan: common questions
What microcontroller does the Glove v3-floorplan use?
The Glove v3-floorplan is built around the 102010469, from the Nordic nRF family.
How big is the Glove v3-floorplan PCB?
The Glove v3-floorplan measures 70 × 46 mm, has 4 copper layers and is 1.6 mm thick.
How many components are on the Glove v3-floorplan?
333 components, from 42 distinct parts, with part numbers taken from the project's own BOM. The full bill of materials is listed on this page.
Where can I download the Glove v3-floorplan design files?
From the latintzar/tactile-glove repository on GitHub, which has the KiCad layout and the BOM; the links under Design files point to each one.
Can I use the Glove v3-floorplan design in my own project?
Yes, under the terms of its MIT license, which latintzar chose for the repository.
Can I test firmware for the Glove v3-floorplan without the hardware?
Yes. HardLabs builds a simulation of the board from its netlist and BOM, so you can run and debug Nordic nRF firmware against it before you order a PCB.
More boards in tactile-glove
 ESP32
Glove v4-routing candidate
100 × 80 mm561 parts8LMIT0 ESP32
Glove v4-placement
100 × 80 mm560 parts6LMIT0 Nordic nRF
Glove v3-routed
90 × 60 mm356 parts4LMIT0 Nordic nRF
Glove v3-grouped
90 × 60 mm330 parts4LMIT0
Hand tile routed
16 × 16 mm7 parts2LMIT0
Hand tile unrouted
16 × 16 mm7 parts2LMIT0
Similar boards
 Nordic nRF
Keyboard
byrantech
262.5 × 109.6 mm206 parts2LMIT4.3k Nordic nRF
TOTEM
GEIGEIGEIST
258.8 × 94.4 mm85 parts2LCERN-OHL-P-2.02.0k Nordic nRF
Pixl.js
solosky
40 × 23 mm45 parts4LGPL-2.01.4k Nordic nRF
Management
dennisss
101 × 31.5 mm50 parts2LApache-2.0381 Nordic nRF
Board
363 × 128 mm420 parts4LApache-2.0381 Nordic nRF
Board hl15-latest
61 × 37 mm14 parts2LApache-2.0381