
Unoq hat

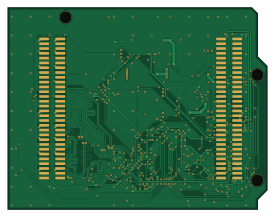
About the Unoq hat
Unoq hat is an open source PCB design by Leif-Rydenfalk, published on GitHub under the Apache-2.0 license. It is a 4-layer board measuring 68.6 × 53.3 mm, with 77 components from 45 distinct parts.
Other key parts include the TCA9406DCUR, TCA9555PWR, TPS62933DRLR, PAM8302AASCR and SN74LVC1G126DBVR. By type, the board carries 27 resistors, 24 capacitors, 12 connectors, 9 ICs, 2 transistors and 1 fuse.
It belongs with the robotics & motion, dev boards & breakouts and audio designs in this gallery.
From the project
Open electronics, firmware and control software for a small two-legged walking robot on the Arduino UNO Q
Two boards. The hat is the one that matters; the IMU breakout is a small extra.
A four-layer hat for the Arduino UNO Q, 68.68 by 53.44 mm, 1.6 mm, ENIG. It sits under the UNO Q on the two 2x30 board-to-board connectors and carries everything the robot needs that the UNO Q does not have.
Everything except the board-to-board headers and the camera connector sits on the bottom side, so nothing fouls the UNO Q above it.
Main components on the Unoq hat
Unoq hat bill of materials (BOM)
77 components, 45 distinct parts — part numbers from the project's BOM.
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 1 | TCA9406DCUR | VSSOP-8_2.3x2mm_P0.5mm | U1 |
| 1 | TCA9555PWR | TSSOP-24_4.4x7.8mm_P0.65mm | U2 |
| 1 | TPS62933DRLR | SOT-583-8 | U3 |
| 1 | PAM8302AASCR | MSOP-8_3x3mm_P0.65mm | U4 |
| 1 | SN74LVC1G126DBVR | SOT-23-5 | U5 |
| 1 | SN74LVC1G125DBVR | SOT-23-5 | U6 |
| 1 | LSM6DSV16X | LGA-14_3x2.5mm_P0.5mm_LayoutBorder3x4y | U7 |
| 1 | INA226AIDGSR | TSSOP-10_3x3mm_P0.5mm | U8 |
| 1 | TTP233H-BA6 | SOT-23-6 | U9 |
| 1 | MMBT3906 | SOT-23 | Q1 |
| 1 | C13899 AON6407 reverse-polarity P-FET | PowerPAK_SO-8_Single | Q2 |
| 1 | C191721 JMEDIA 2x30 1.27 SMD male (GPEC212-3002A011C1AF equiv.) | UNOQ_JMEDIA_2x30_P1.27_Male | J1 |
| 1 | C191721 JMISC 2x30 1.27 SMD male (GPEC212-3002A011C1AF equiv.) | UNOQ_JMEDIA_2x30_P1.27_Male | J2 |
| 1 | C3169786 TF31-22S-0.5SH 22p 0.5 FFC (IMX219) | FFC_22P_P0.5_TF31-22S | J3 |
| 1 | C160392 BM06B-SRSS-TB ToF | JST_SH_BM06B-SRSS-TB_1x06-1MP_P1.00mm_Vertical | J4 |
| 1 | C265101 S3B-PH-SM4-TB servo bus | JST_PH_S3B-PH-SM4-TB_1x03-1MP_P2.00mm_Horizontal | J5 |
| 1 | C265102 S4B-PH-SM4-TB 2S pack in | JST_PH_S4B-PH-SM4-TB_1x04-1MP_P2.00mm_Horizontal | J6 |
| 1 | C295747 S2B-PH-SM4-TB speaker | JST_PH_S2B-PH-SM4-TB_1x02-1MP_P2.00mm_Horizontal | J7 |
| 1 | C160402 SM02B-SRSS-TB electret mic | JST_SH_SM02B-SRSS-TB_1x02-1MP_P1.00mm_Horizontal | J8 |
| 1 | C160402 SM02B-SRSS-TB touch pad | JST_SH_SM02B-SRSS-TB_1x02-1MP_P1.00mm_Horizontal | J9 |
Show 25 more
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 1 | C160402 SM02B-SRSS-TB left foot contact | JST_SH_SM02B-SRSS-TB_1x02-1MP_P1.00mm_Horizontal | J10 |
| 1 | C160402 SM02B-SRSS-TB right foot contact | JST_SH_SM02B-SRSS-TB_1x02-1MP_P1.00mm_Horizontal | J11 |
| 1 | C160390 BM04B-SRSS-TB trunk IMU I2C | JST_SH_BM04B-SRSS-TB_1x04-1MP_P1.00mm_Vertical | J12 |
| 1 | C702820 SMD1812P300TF/16 3A PTC | Fuse_1812_4532Metric | F1 |
| 1 | BZT52C5V1S | D_SOD-323 | D1 |
| 1 | C168072 FNR6045S6R8MT 6.8uH 3.3A | FNR6045_6.0x6.0mm | L1 |
| 1 | 4.7UF 4.7uF | C_0402_1005Metric | C1 |
| 13 | 100NF 100nF | C_0402_1005Metric | C2, C3, C5, C13, C14, C15, C19, C20 +5 |
| 2 | C1713 10uF 16V | C_0805_2012Metric | C4, C16 |
| 2 | C77090 10uF 25V | C_1206_3216Metric | C6, C7 |
| 2 | C105883 100nF 25V | C_0402_1005Metric | C8, C9 |
| 1 | 10NF 10nF | C_0402_1005Metric | C10 |
| 2 | C52306 22uF 25V | C_1210_3225Metric | C11, C12 |
| 1 | 10pF C0G (DNP) | C_0402_1005Metric | C24 |
| 11 | 10K 10k | R_0402_1005Metric | R1, R2, R7, R8, R15, R16, R17, R18 +3 |
| 2 | C17168 0R | R_0402_1005Metric | R3, R4 |
| 2 | 0R | R_0402_1005Metric | R5, R6 |
| 3 | 100K 100k | R_0402_1005Metric | R9, R11, R13 |
| 1 | 523K 523k | R_0402_1005Metric | R12 |
| 1 | 2.2K 2.2k | R_0402_1005Metric | R14 |
| 1 | 20K 20k | R_0402_1005Metric | R19 |
| 1 | 33R | R_0402_1005Metric | R20 |
| 2 | 1k | R_0402_1005Metric | R21, R24 |
| 1 | C185817 5mR 2W shunt | R_2512_6332Metric | R22 |
| 2 | 4.7K 4.7k | R_0402_1005Metric | R27, R28 |
Unoq hat design files
The KiCad project lives in the Leif-Rydenfalk/walking-robot-kit repository on GitHub; these links point at the commit this page was built from.
Unoq hat: common questions
How big is the Unoq hat?
The Unoq hat measures 68.6 × 53.3 mm, has 4 copper layers and is 1.6 mm thick.
How many components are on the Unoq hat?
77 components, from 45 distinct parts, with part numbers taken from the project's own BOM. The full bill of materials is listed on this page.
Where can I download the Unoq hat design files?
From the Leif-Rydenfalk/walking-robot-kit repository on GitHub, which has the KiCad layout, the schematic and the BOM; the links under Design files point to each one.
Can I use the Unoq hat design in my own project?
Yes, under the terms of its Apache-2.0 license, which Leif-Rydenfalk chose for the repository.
More boards in walking-robot-kit

Similar boards
Stack chan
stack-chan
50 × 50 mm33 parts2LApache-2.01.7k
KLOR
GEIGEIGEIST
160.2 × 118.3 mm79 parts2LGPL-3.01.2k
134pin 7-967288-1
rusefi
139.7 × 73.7 mm38 parts2LGPL-3.01.2k
Breakout 60pin EEC-IV
139.7 × 62.2 mm15 parts2LGPL-3.01.2k
Eecv breakout
140.8 × 53.7 mm9 parts4LGPL-3.01.2k
Breakout 112pin Connector
174 × 58 mm39 parts2LGPL-3.01.2k