
Indieduck

About the Indieduck PCB
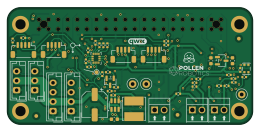
Indieduck is an open source PCB design by armature-ai-labs, published on GitHub under the Apache-2.0 license. It is a 4-layer board measuring 65 × 30.9 mm, with 125 components from 49 distinct parts.
Other key parts include the PAM8406D, TLV320AIC3104IRHBR, XC6206P182MR, DNP-CAT24C32HU4 and 74LVC1G08. By type, the board carries 45 capacitors, 42 resistors, 12 connectors, 11 ICs, 4 inductors and 3 test points.
It belongs with the robotics & motion and dev boards & breakouts designs in this gallery.
From the project
Open robot prototype: editable FreeCAD CAD, printable parts and fit-test documentation. Adapted from Open Duck Mini.
- IMU over I2C + data fusion - Dynamixel motor communication: both TTL and 485 to drive Dynamixel/Feetech motor (requires cable adaptation) - in/out audio device with an integrated mems microphone. Wago connectors allows connection of loudspeaker and extra microphone. - expension Qwiic connectors, 1 mm/3V3. Please refer to the schematic for knowing which can be use on you raspberry pi.
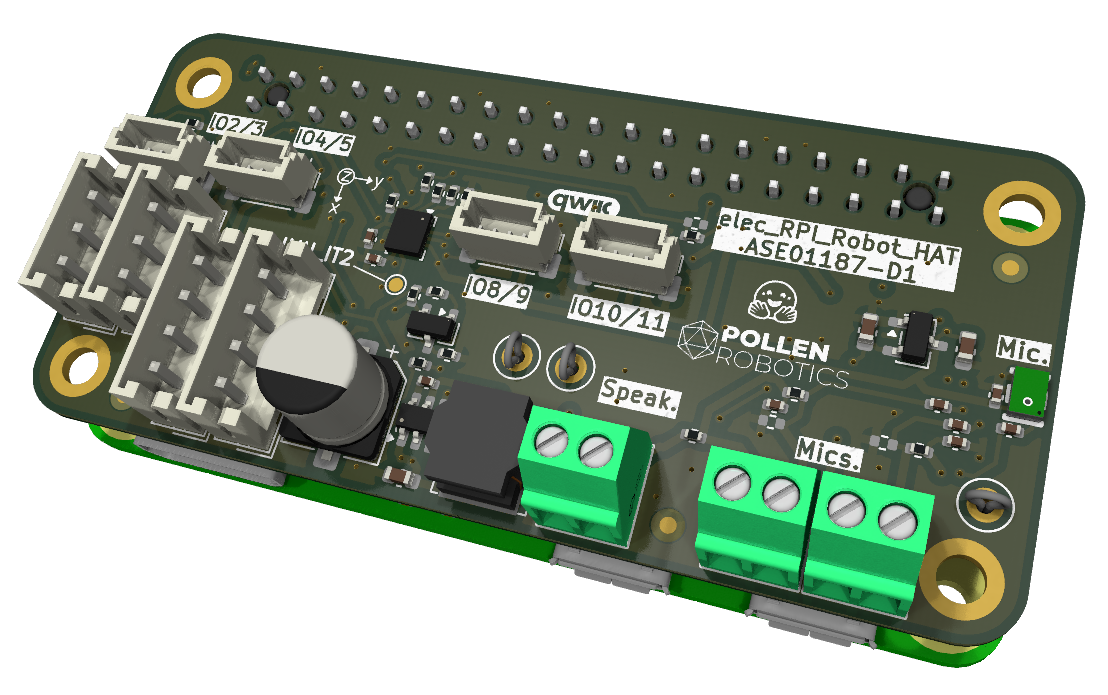
Main components on the Indieduck
Indieduck bill of materials (BOM)
125 components, 49 distinct parts — part numbers from the project's BOM.
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 1 | PAM8406D | SOIC-16_3.9x9.9mm_P1.27mm | U1 |
| 1 | TLV320AIC3104IRHBR | VQFN-32-1EP_5x5mm_P0.5mm_EP3.5x3.5mm | U2 |
| 1 | XC6206P182MR | SOT-23-3 | U3 |
| 1 | DNP-CAT24C32HU4 | TDFN-8_L3.0-W2.0-P0.50-BL-EP | U4 |
| 1 | 74LVC1G08 | SOT-23-5 | U5 |
| 1 | SN74LVC1G125DBV | SOT-23-5 | U6 |
| 1 | SN74LVC1G126DBVR | SOT-23-5 | U7 |
| 1 | GM3088ENA | DFN-8-1EP_3x3mm_P0.65mm_EP1.2x2.15mm | U8 |
| 1 | AP63205 | TSOT-23-6 | U9 |
| 1 | LM5050-1 | TSOT-23-6 | U10 |
| 1 | LSM6DSV16XTR | LGA-14_3x2.5mm_P0.5mm_LayoutBorder3x4y | U12 |
| 1 | MMBT3906 | SOT-23 | Q1 |
| 1 | C22469448 N-Channel 5A | TSOT-23 | Q2 |
| 1 | C7425459 12 MHz | Oscillator_SMD_Abracon_ASDMB-4Pin_2.5x2.0mm | Y1 |
| 3 | C918120 Screw term. | CONN-TH_DB125-2.54-2P-GN | J1, J2, J9 |
| 2 | DYNAMIXEL-4 Dynamixel-4 | JST_EH_B4B-EH-A_1x04_P2.50mm_Vertical | J3, J11 |
| 1 | C2685112 Female Header 2x20 SMD | PinHeader_2x20_P2.54mm_Vertical_with_rasp_HAT_zero_SMD_connector | J4 |
| 4 | C160390 JST SH | JST_SH_BM04B-SRSS-TB_1x04-1MP_P1.00mm_Vertical | J5, J6, J7, J8 |
| 2 | DYNAMIXEL-3 Dynamixel-3 | JST_EH_B3B-EH-A_1x03_P2.50mm_Vertical | J13, J14 |
| 1 | C7587901 Microphone_MEMS | MIC-SMD_4P-L2.8-W1.9-P1.84-TL | MK1 |
Show 29 more
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 1 | C913703 100R thermistor | R_0603_1608Metric | TH1 |
| 3 | TestPoint | TestPoint_Loop_D2.50mm_Drill1.0mm_LowProfile | TP2, TP3, TP4 |
| 1 | BAT54W | SOT-323_SC-70 | D1 |
| 1 | C19077392 3V3 Zener Diode | D_SOD-123 | D2 |
| 1 | 5V1 | D_SOD-323 | D4 |
| 1 | C76884 1.3A 600R@100MHz | L_0402_1005Metric | FB1 |
| 2 | C88970 2A - 120R@100MHz | L_0402_1005Metric | FB2, FB3 |
| 1 | C57254 6,8u 2A | L_Bourns_SRN6045TA | L4 |
| 15 | 1u | C_0402_1005Metric | C1, C2, C3, C4, C6, C10, C27, C29 +7 |
| 5 | 10U 10u | C_0603_1608Metric | C5, C7, C12, C13, C37 |
| 2 | 220N 220n | C_0402_1005Metric | C8, C9 |
| 12 | 100N 100n | C_0402_1005Metric | C11, C14, C15, C16, C17, C18, C26, C28 +4 |
| 1 | C72488 10u 63V | CP_Elec_6.3x7.7 | C19 |
| 1 | C307331 100n 50V | C_0402_1005Metric | C20 |
| 2 | C84419 22u 6V3 | C_0603_1608Metric | C21, C22 |
| 3 | C1525 100n 6V3 | C_0402_1005Metric | C23, C24, C39 |
| 1 | DNP-100N DNP-100n | C_0402_1005Metric | C25 |
| 2 | 10N 10n | C_0402_1005Metric | C34, C44 |
| 1 | C33546007 10u 35V | C_0805_2012Metric | C45 |
| 17 | 10K 10k | R_0402_1005Metric | R1, R2, R6, R12, R13, R20, R21, R24 +9 |
| 12 | C17168 0R | R_0402_1005Metric | R3, R4, R5, R7, R9, R14, R15, R18 +4 |
| 1 | 100R | R_0402_1005Metric | R8 |
| 2 | DNP-10K DNP-10k | R_0402_1005Metric | R10, R11 |
| 3 | DNP-0R | R_0402_1005Metric | R16, R17, R41 |
| 2 | 4K7 4k7 | R_0402_1005Metric | R22, R23 |
| 1 | 20K 20k | R_0402_1005Metric | R28 |
| 1 | 150R | R_0402_1005Metric | R33 |
| 2 | DNP-1M | R_0402_1005Metric | R36, R37 |
| 1 | 1k | R_0402_1005Metric | R42 |
Indieduck design files
The KiCad project lives in the armature-ai-labs/indieduck repository on GitHub; these links point at the commit this page was built from.
Indieduck: common questions
How big is the Indieduck PCB?
The Indieduck measures 65 × 30.9 mm, has 4 copper layers and is 1 mm thick.
How many components are on the Indieduck?
125 components, from 49 distinct parts, with part numbers taken from the project's own BOM. The full bill of materials is listed on this page.
Where can I download the Indieduck design files?
From the armature-ai-labs/indieduck repository on GitHub, which has the KiCad layout, the schematic and the BOM; the links under Design files point to each one.
Can I use the Indieduck design in my own project?
Yes, under the terms of its Apache-2.0 license, which armature-ai-labs chose for the repository.
Similar boards

Stack chan
stack-chan
50 × 50 mm33 parts2LApache-2.01.7k
134pin 7-967288-1
rusefi
139.7 × 73.7 mm38 parts2LGPL-3.01.2k
Eecv breakout
140.8 × 53.7 mm9 parts4LGPL-3.01.2k
88 Pin Vag Breakout
142 × 58 mm91 parts2LGPL-3.01.2k
Breakout 60pin EEC-IV
139.7 × 62.2 mm15 parts2LGPL-3.01.2k
Breakout 112pin Connector
174 × 58 mm39 parts2LGPL-3.01.2k