
Elec RPI Robot HAT

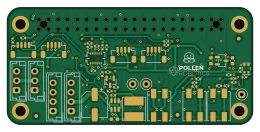
About the Elec RPI Robot HAT
Elec RPI Robot HAT is an open source PCB design by pollen-robotics, published on GitHub under the Apache-2.0 license. It is a 4-layer board measuring 65 × 30.9 mm, with 122 components from 46 distinct parts.
Other key parts include the PAM8406D, TLV320AIC3104IRHBR, XC6206P182MR, DNP-CAT24C32HU4 and 74LVC1G08. By type, the board carries 44 capacitors, 40 resistors, 12 connectors, 11 ICs, 4 inductors and 3 test points.
It belongs with the robotics & motion, sensors and dev boards & breakouts designs in this gallery.
From the project
RPI HAT for small/medium robots (IMU, Dynamixel)
- IMU over I2C - Dynamixel motor communication: both TTL and 485 to drive Dynamixel/Feetech motor (requires cable adaptation) - in/out audio device with an integrated mems microphone. Wago connectors allows connection of loudspeaker and extra microphone. - expension Qwiic connectors, 1 mm/3V3. Please refer to the schematic for knowing which can be use on you raspberry pi.
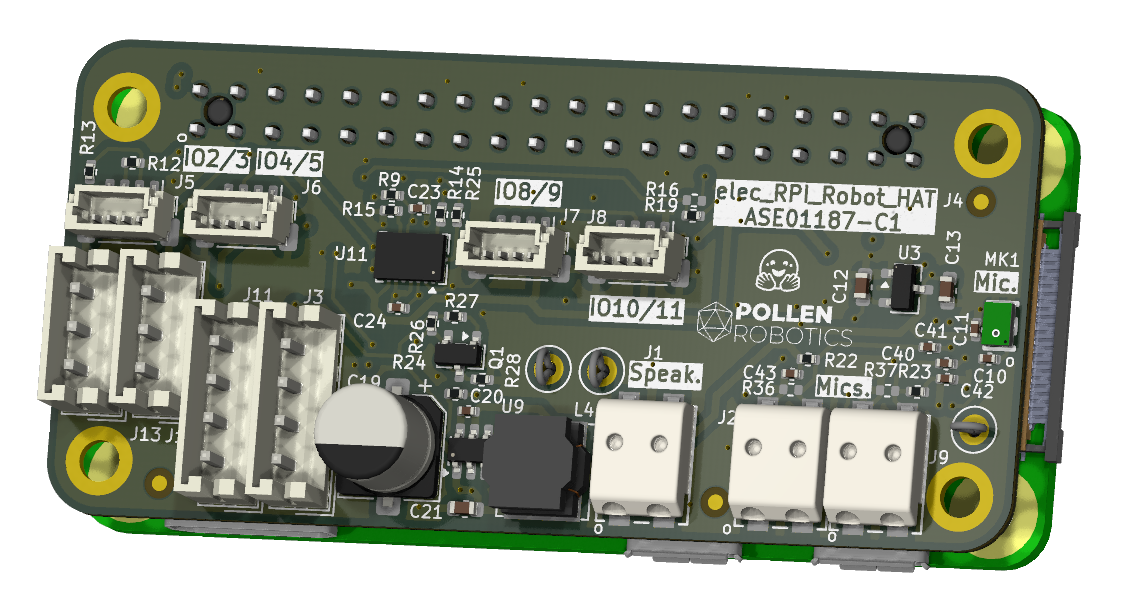
Main components on the Elec RPI Robot HAT
Elec RPI Robot HAT bill of materials (BOM)
122 components, 46 distinct parts — part numbers from the project's BOM.
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 1 | PAM8406D | SOIC-16_3.9x9.9mm_P1.27mm | U1 |
| 1 | TLV320AIC3104IRHBR | VQFN-32-1EP_5x5mm_P0.5mm_EP3.5x3.5mm | U2 |
| 1 | XC6206P182MR | SOT-23-3 | U3 |
| 1 | DNP-CAT24C32HU4 | TDFN-8_L3.0-W2.0-P0.50-BL-EP | U4 |
| 1 | 74LVC1G08 | SOT-23-5 | U5 |
| 1 | SN74LVC1G125DBV | SOT-23-5 | U6 |
| 1 | SN74LVC1G126DBVR | SOT-23-5 | U7 |
| 1 | SIT3088E | MSOP-8-1EP_3x3mm_P0.65mm_EP1.5x1.8mm | U8 |
| 1 | AP63205 | TSOT-23-6 | U9 |
| 1 | LM5050-1 | TSOT-23-6 | U10 |
| 1 | BMI088 | Bosch_LGA-16_4.5x3mm_P0.5mm_LayoutBorder7x1y_ClockwisePinNumbering | U11 |
| 1 | MMBT3906 | SOT-23 | Q1 |
| 1 | SI2312CDS-T1-GE3 | TSOT-23 | Q2 |
| 1 | C7425459 12 MHz | Oscillator_SMD_Abracon_ASDMB-4Pin_2.5x2.0mm | Y1 |
| 3 | WAGO-2 Wago-2 | Wago_2059-302_998-403 | J1, J2, J9 |
| 2 | DYNAMIXEL-4 Dynamixel-4 | JST_EH_B4B-EH-A_1x04_P2.50mm_Vertical | J3, J11 |
| 1 | C2685112 Female Header 2x20 SMD | PinHeader_2x20_P2.54mm_Vertical_with_rasp_HAT_zero_SMD_connector | J4 |
| 4 | C160390 JST SH | JST_SH_BM04B-SRSS-TB_1x04-1MP_P1.00mm_Vertical | J5, J6, J7, J8 |
| 2 | DYNAMIXEL-3 Dynamixel-3 | JST_EH_B3B-EH-A_1x03_P2.50mm_Vertical | J13, J14 |
| 1 | C7587901 Microphone_MEMS | MIC-SMD_4P-L2.8-W1.9-P1.84-TL | MK1 |
Show 26 more
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 1 | C913703 100R thermistor | R_0603_1608Metric | TH1 |
| 3 | TestPoint | TestPoint_Loop_D2.50mm_Drill1.0mm_LowProfile | TP2, TP3, TP4 |
| 1 | BAT54W | SOT-323_SC-70 | D1 |
| 1 | C19077392 3V3 Zener Diode | D_SOD-123 | D2 |
| 1 | 5V1 | D_SOD-323 | D4 |
| 1 | C76884 1.3A 600R@100MHz | L_0402_1005Metric | FB1 |
| 2 | C88970 2A - 120R@100MHz | L_0402_1005Metric | FB2, FB3 |
| 1 | C57254 6,8u 2A | L_Bourns_SRN6045TA | L4 |
| 15 | 1u | C_0402_1005Metric | C1, C2, C3, C4, C6, C10, C27, C29 +7 |
| 5 | 10U 10u | C_0603_1608Metric | C5, C7, C12, C13, C37 |
| 2 | 220N 220n | C_0402_1005Metric | C8, C9 |
| 12 | 100N 100n | C_0402_1005Metric | C11, C14, C15, C16, C17, C18, C26, C28 +4 |
| 1 | C72488 10u 63V | CP_Elec_6.3x7.7 | C19 |
| 1 | C307331 100n 50V | C_0402_1005Metric | C20 |
| 2 | C84419 22u 6V3 | C_0603_1608Metric | C21, C22 |
| 3 | C1525 100n 6V3 | C_0402_1005Metric | C23, C24, C39 |
| 1 | DNP-100N DNP-100n | C_0402_1005Metric | C25 |
| 2 | 10N 10n | C_0402_1005Metric | C34, C44 |
| 19 | 10K 10k | R_0402_1005Metric | R1, R2, R6, R12, R13, R20, R21, R22 +11 |
| 11 | C17168 0R | R_0402_1005Metric | R3, R4, R5, R7, R9, R14, R15, R18 +3 |
| 1 | 100R | R_0402_1005Metric | R8 |
| 2 | DNP-10K DNP-10k | R_0402_1005Metric | R10, R11 |
| 3 | DNP-0R | R_0402_1005Metric | R16, R17, R41 |
| 1 | 20K 20k | R_0402_1005Metric | R28 |
| 1 | 150R | R_0402_1005Metric | R33 |
| 2 | DNP-1M | R_0402_1005Metric | R36, R37 |
Elec RPI Robot HAT design files
The KiCad project lives in the pollen-robotics/elec_RPI_Robot_HAT repository on GitHub; these links point at the commit this page was built from.
Elec RPI Robot HAT: common questions
How big is the Elec RPI Robot HAT?
The Elec RPI Robot HAT measures 65 × 30.9 mm, has 4 copper layers and is 1 mm thick.
How many components are on the Elec RPI Robot HAT?
122 components, from 46 distinct parts, with part numbers taken from the project's own BOM. The full bill of materials is listed on this page.
Where can I download the Elec RPI Robot HAT design files?
From the pollen-robotics/elec_RPI_Robot_HAT repository on GitHub, which has the KiCad layout, the schematic and the BOM; the links under Design files point to each one.
Can I use the Elec RPI Robot HAT design in my own project?
Yes, under the terms of its Apache-2.0 license, which pollen-robotics chose for the repository.
Similar boards

Sensors
StuckAtPrototype
15.2 × 9 mm14 parts4LApache-2.03.8k
Microphone
Mentra-Community
5.5 × 6.1 mm6 parts2LMIT1.2k
TemperaturePCB PANEL
stuartpittaway
116 × 75.5 mm178 parts2LCC-BY-NC-4.01.1k
Cube batteryboard
willem-pennings
95 × 95 mm4 parts2LGPL-3.01.1k
Sram dev board
Wren6991
50 × 50 mm12 parts2LNo license508
ESP32
Chrismettal
66.4 × 48.1 mm20 parts2LCC-BY-SA-4.0446