
2 open source boards using the SIT3088E
Real designs built with the SIT3088E, from public GitHub projects: a quick way to see how others power, decouple and connect it. Each board comes with its KiCad files, full parts list and a render — and you can simulate its firmware on HardLabs.
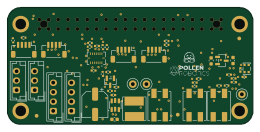
Elec RPI Robot HAT
pollen-robotics
65 × 30.9 mm122 parts4LApache-2.080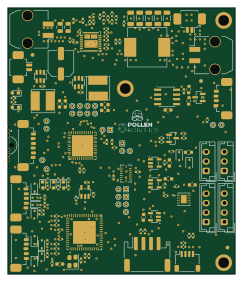 STM32
Elec Anything2EtherCAT
60 × 70.3 mm200 parts4LApache-2.04
The SIT3088E in open source designs
The gallery holds 2 open source boards using the SIT3088E from 2 GitHub repositories; a typical one measures about 62.5 × 50.6 mm and carries around 161 components.
100% use four copper layers or more, and 100% carry an open source license.
The most starred is Elec RPI Robot HAT by pollen-robotics.
Parts used alongside the SIT3088E
Microcontrollers on boards using the SIT3088E
What boards using the SIT3088E are built for
SIT3088E: common questions
Where can I find a SIT3088E reference design?
Each of the 2 boards on this page is a real design using the SIT3088E. Open one to see how it is wired up, with the full BOM, a render of the layout and links to its KiCad files.
What parts are used alongside the SIT3088E?
The 74LVC1G08, AP63205, BMI088, SN74LVC1G125DBV and SN74LVC1G126DBVR appear in the most repositories here.
Which microcontrollers do boards using the SIT3088E use?
Most are built on STM32 (1).
How big is a typical board using the SIT3088E?
The median is 62.5 × 50.6 mm, and 0% are two-layer designs.
What is the most popular open source board using the SIT3088E?
By GitHub stars, Elec RPI Robot HAT by pollen-robotics, with 80 stars.
Can I simulate one of these boards using the SIT3088E before building it?
Yes. HardLabs turns a board's netlist and BOM into a working simulation, so you can boot and test firmware against it with no hardware on your desk.