
2 open source boards using the LXDC55F
Real designs built with the LXDC55F, from public GitHub projects: a quick way to see how others power, decouple and connect it. Each board comes with its KiCad files, full parts list and a render — and you can simulate its firmware on HardLabs.
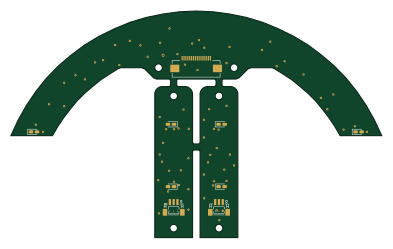 STM32
Robotrace sensorV4
shimotoriharuki
98.2 × 60 mm89 parts2LBSD-3-Clause4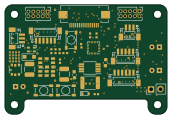 STM32
RobotraceV5
43 × 29 mm86 parts4LBSD-3-Clause4
The LXDC55F in open source designs
The gallery holds 2 open source boards using the LXDC55F from 1 GitHub repository; a typical one measures about 70.6 × 44.5 mm and carries around 88 components.
50% are two-layer designs, the rest use four layers or more, and 100% carry an open source license.
The most starred is Robotrace sensorV4 by shimotoriharuki.
Microcontrollers on boards using the LXDC55F
What boards using the LXDC55F are built for
LXDC55F: common questions
Where can I find a LXDC55F reference design?
Each of the 2 boards on this page is a real design using the LXDC55F. Open one to see how it is wired up, with the full BOM, a render of the layout and links to its KiCad files.
Which microcontrollers do boards using the LXDC55F use?
Most are built on STM32 (2).
How big is a typical board using the LXDC55F?
The median is 70.6 × 44.5 mm, and 50% are two-layer designs.
What is the most popular open source board using the LXDC55F?
By GitHub stars, Robotrace sensorV4 by shimotoriharuki, with 4 stars.
Can I simulate one of these boards using the LXDC55F before building it?
Yes. HardLabs turns a board's netlist and BOM into a working simulation, so you can boot and test firmware against it with no hardware on your desk.