
3 open source boards using the TPSM84205EAB
Real designs built with the TPSM84205EAB, from public GitHub projects: a quick way to see how others power, decouple and connect it. Each board comes with its KiCad files, full parts list and a render — and you can simulate its firmware on HardLabs.
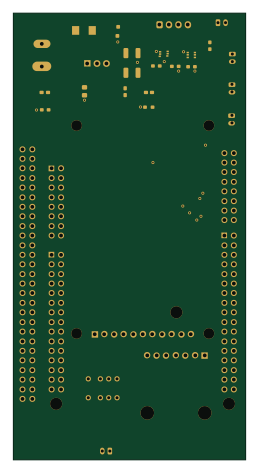
CAN to Ethernet
RoboJackets
61.4 × 118.1 mm26 parts2LNo license1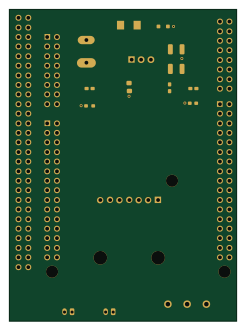
Drive/Steering Board
60.3 × 82.6 mm15 parts2LNo license1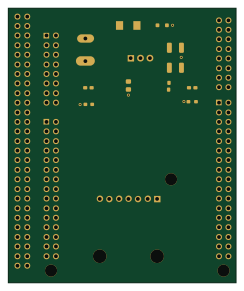
CAN to Ethernet
60.3 × 72.8 mm12 parts2LNo license1
The TPSM84205EAB in open source designs
The gallery holds 3 open source boards using the TPSM84205EAB from 1 GitHub repository; a typical one measures about 60.3 × 82.6 mm and carries around 15 components.
100% are two-layer designs, the rest use four layers or more, and 0% carry an open source license.
The most starred is CAN to Ethernet by RoboJackets.
What boards using the TPSM84205EAB are built for
TPSM84205EAB: common questions
Where can I find a TPSM84205EAB reference design?
Each of the 3 boards on this page is a real design using the TPSM84205EAB. Open one to see how it is wired up, with the full BOM, a render of the layout and links to its KiCad files.
How big is a typical board using the TPSM84205EAB?
The median is 60.3 × 82.6 mm, and 100% are two-layer designs.
What is the most popular open source board using the TPSM84205EAB?
By GitHub stars, CAN to Ethernet by RoboJackets, with 1 stars.
Can I simulate one of these boards using the TPSM84205EAB before building it?
Yes. HardLabs turns a board's netlist and BOM into a working simulation, so you can boot and test firmware against it with no hardware on your desk.