
3 open source boards using the Pololu_DRV8711_Motor_Driver
Real designs built with the Pololu_DRV8711_Motor_Driver, from public GitHub projects: a quick way to see how others power, decouple and connect it. Each board comes with its KiCad files, full parts list and a render — and you can simulate its firmware on HardLabs.
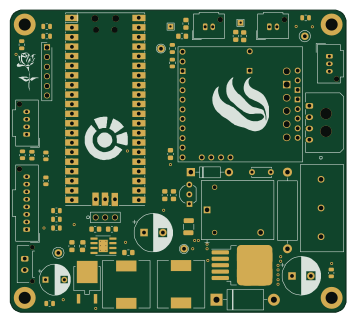 RP2040/RP2350
WaveWise PMIC
GenerateNU
88.9 × 80 mm60 parts4LNo license0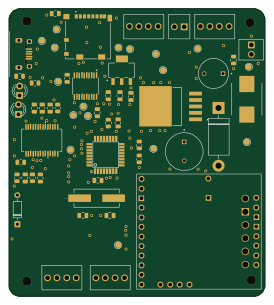 AVR/Arduino
WaveWise Buoy
67.8 × 76.2 mm47 parts4LNo license0 AVR/Arduino
WaveWise Buoy
67.8 × 76.2 mm47 parts4LNo license0
The Pololu_DRV8711_Motor_Driver in open source designs
The gallery holds 3 open source boards using the Pololu_DRV8711_Motor_Driver from 2 GitHub repositories; a typical one measures about 67.8 × 76.2 mm and carries around 47 components.
100% use four copper layers or more, and 0% carry an open source license.
The most starred is WaveWise PMIC by GenerateNU.
Parts used alongside the Pololu_DRV8711_Motor_Driver
Microcontrollers on boards using the Pololu_DRV8711_Motor_Driver
Pololu_DRV8711_Motor_Driver: common questions
Where can I find a Pololu_DRV8711_Motor_Driver reference design?
Each of the 3 boards on this page is a real design using the Pololu_DRV8711_Motor_Driver. Open one to see how it is wired up, with the full BOM, a render of the layout and links to its KiCad files.
What parts are used alongside the Pololu_DRV8711_Motor_Driver?
The ATMEGA328PB-ANR, AZ1117CH-3.3TRG1, FT232RL-REEL, LM2576HVS-5.0_NOPB and TXB0108PWR appear in the most repositories here.
Which microcontrollers do boards using the Pololu_DRV8711_Motor_Driver use?
Most are built on AVR/Arduino (2) and RP2040/RP2350 (1).
How big is a typical board using the Pololu_DRV8711_Motor_Driver?
The median is 67.8 × 76.2 mm, and 0% are two-layer designs.
What is the most popular open source board using the Pololu_DRV8711_Motor_Driver?
By GitHub stars, WaveWise PMIC by GenerateNU, with 0 stars.
Can I simulate one of these boards using the Pololu_DRV8711_Motor_Driver before building it?
Yes. HardLabs turns a board's netlist and BOM into a working simulation, so you can boot and test firmware against it with no hardware on your desk.