
50 open source boards using the LD1117S50TR_SOT223
Real designs built with the LD1117S50TR_SOT223, from public GitHub projects: a quick way to see how others power, decouple and connect it. Each board comes with its KiCad files, full parts list and a render — and you can simulate its firmware on HardLabs.
 AVR/Arduino
MegaMIDI
AidanHockey5
100 × 100 mm102 parts2LAGPL-3.0116 AVR/Arduino
Genny
superjoebob
100 × 100 mm102 parts2LNo license92 Microchip SAM
MegaBlaster2
99 × 99 mm102 parts4LAGPL-3.059 Microchip SAM
YM2151 Arcade Classic 2
99 × 99 mm111 parts4LAGPL-3.022 RP2040/RP2350
Mainboard
matgla
100 × 100 mm124 parts4LMIT10 ESP32
Batch (4 Layer SMT)
Cyberspecies
100 × 100 mm68 parts4LNo license10
DataAcquisitionUnit
RobertGawron
85 × 50 mm56 parts2LMIT6
Seed3-DevKit-Desktop
daisyaudio
197 × 111 mm230 parts2LNo license2
QMix
WardBenjamin
66 × 39.1 mm67 parts2LNo license2
Bottom board
mod-audio
172 × 140.5 mm252 parts2LNo license1 STM32
LED-Strip-Controller-Hardware
ScottGibb
134.6 × 76.2 mm167 parts2LGPL-3.01 ESP32
Soil metrics
Aryan-git-byte
88.3 × 112.3 mm74 parts4LMIT1 RP2040/RP2350
Flight controller atlas
williamjroche
51 × 45 mm66 parts4LMIT1 STM32
PCB ApiaryWaterDispensingSystem
Mateuszworo97
217.3 × 127.3 mm182 parts2LNo license0 STM32
Test Projekt
Siegmundshof93
86.2 × 91.9 mm147 parts2LNo license0 ESP8266
PCV MATOME MAIN V5-KICAD 5.0
leevawns
170 × 95 mm86 parts2LNo license0 AVR/Arduino
BlinCAN
metalhead777
127.1 × 67.1 mm84 parts2LCC-BY-SA-4.00 STM32
Theyseemerolling elec
PhenixRobotik
75 × 50 mm82 parts2LNo license0 STM32
2026 12 2Wheel Balance Robot v1
nruth633
68.6 × 53.4 mm56 parts2LNo license0 STM32
20260428 2Wheel Balance Robot
uzm99
100 × 100 mm56 parts2LNo license0 RP2040/RP2350
Hyperactive radio
activexray
88 × 60 mm52 parts4LNo license0 PIC
DecimoPrimeiro ProjetoFinal
EngTarcisioSm
66.6 × 51.8 mm30 parts2LNo license0
Dual-Output-Power-Supply-PCB-12V-5V-3.3V-
jayxgithub
69.7 × 47.3 mm28 parts4LNo license0- schematic only · 138 partsSTM32
Yuho vre1
shin-waseda
138 partsNo license0 
Substructure Power Distribution
55 × 20 mm64 parts4LNo license10 ESP32
ProcessingAndStorage
85 × 50 mm50 parts2LMIT6
Pixfrog satellite
Lefix2
39.9 × 31.5 mm20 parts2LMIT1
Dual power supply
45.7 × 23.9 mm15 parts2LMIT1 PIC
Sub circ completo (2)
laurapellizari
100 × 67 mm77 parts2LNo license0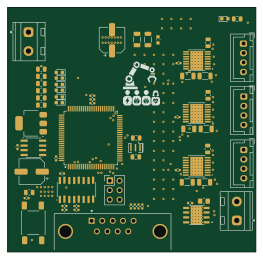 AVR/Arduino
Logic
try-except
65.6 × 64.6 mm66 parts2LNo license0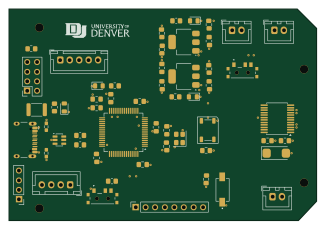 STM32
20260430 2Wheel Balance Robot
81.3 × 55.9 mm56 parts2LNo license0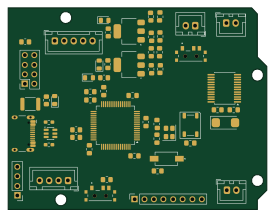 STM32
V2 bot embedded
68.6 × 53.4 mm56 parts2LNo license0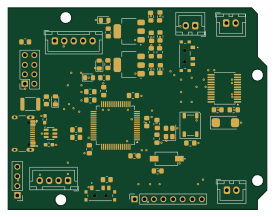 STM32
2026 12 2Wheel Balance Robot v1
cshieldsce
68.6 × 53.4 mm55 parts2LNo license0
Main board plugged
tuankiet65
100.3 × 100.3 mm38 parts2LNo license0
4 layer Batch
60 × 89.5 mm58 parts4LNo license10 STM32
20260501 2Wheel Balance Robot
81.3 × 55.9 mm56 parts2LNo license0
How designs wire the LD1117S50TR_SOT223
Read from the KiCad layouts of 28 open source designs, one per repository: what each pin of the LD1117S50TR_SOT223 connects to, and the resistors, capacitors and other passives placed on it.
- The VI pin has a capacitor to GND on 23 of 28 designs, most often 10 µF (then 100 nF).
- The VO pin has a decoupling capacitor on 16 of 28 designs, most often 10 µF (then 100 nF).
| Pin | Connected to | Parts on the pin |
|---|---|---|
| GNDpin 1 | Connected to: GND 96% | — |
| VOpin 2 | Connected to: 5V 71% · a signal 29% |
|
| VIpin 3 | Connected to: A connector 21% · 12V 32% |
|
Connections count pins, parts count designs; values in brackets are how many parts had that value. Designs read include MegaMIDI by AidanHockey5, Genny by superjoebob, MegaBlaster2 by AidanHockey5 and YM2151 Arcade Classic 2 by AidanHockey5.
The LD1117S50TR_SOT223 in open source designs
The gallery holds 50 open source boards using the LD1117S50TR_SOT223 from 29 GitHub repositories; a typical one measures about 85.6 × 65.8 mm and carries around 56 components.
71% are two-layer designs, the rest use four layers or more, and 26% carry an open source license.
The most starred is MegaMIDI by AidanHockey5.
Parts used alongside the LD1117S50TR_SOT223
Microcontrollers on boards using the LD1117S50TR_SOT223
What boards using the LD1117S50TR_SOT223 are built for
LD1117S50TR_SOT223: common questions
Where can I find a LD1117S50TR_SOT223 reference design?
Each of the 50 boards on this page is a real design using the LD1117S50TR_SOT223. Open one to see how it is wired up, with the full BOM, a render of the layout and links to its KiCad files.
How is the LD1117S50TR_SOT223 VI pin connected?
The VI pin has a capacitor to GND on 23 of 28 designs, most often 10 µF (then 100 nF). Counted from the KiCad layouts of 28 open source designs using the LD1117S50TR_SOT223.
What decoupling capacitors do designs use on the LD1117S50TR_SOT223 VO pin?
The VO pin has a decoupling capacitor on 16 of 28 designs, most often 10 µF (then 100 nF). Counted from the KiCad layouts of 28 open source designs using the LD1117S50TR_SOT223.
What parts are used alongside the LD1117S50TR_SOT223?
The LD1117S33TR_SOT223, USBLC6-2SC6, LM2733XMF, TB6612FNG and H11L1 appear in the most repositories here.
Which microcontrollers do boards using the LD1117S50TR_SOT223 use?
Most are built on STM32 (13), ESP32 (6), AVR/Arduino (4) and PIC (3).
How big is a typical board using the LD1117S50TR_SOT223?
The median is 85.6 × 65.8 mm, and 71% are two-layer designs.
What is the most popular open source board using the LD1117S50TR_SOT223?
By GitHub stars, MegaMIDI by AidanHockey5, with 116 stars.
Can I simulate one of these boards using the LD1117S50TR_SOT223 before building it?
Yes. HardLabs turns a board's netlist and BOM into a working simulation, so you can boot and test firmware against it with no hardware on your desk.